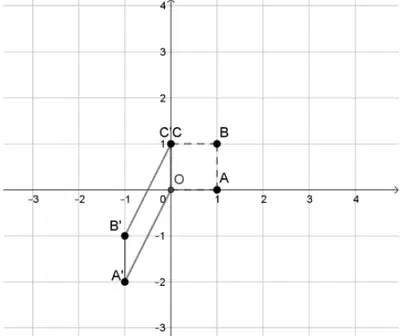
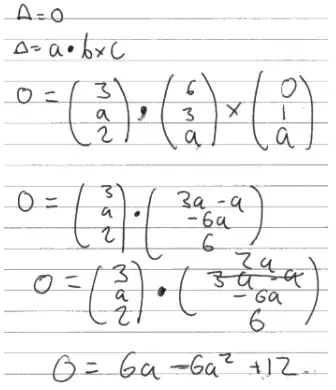Uses the planes to eliminate one variable to form two equations e.g \(\left.\begin{aligned}2x + 2y - 2z &= 6\\ 2x + 3y + 5z &= 4\end{aligned}\right\} \Rightarrow -y - 7z = 2\) and \(\left.\begin{aligned}x + y - z &= 3\\ x + 3y + 13z &= c\end{aligned}\right\} \Rightarrow -2y - 14z = 3 - c\)
dM1
3.1a
Uses their equations to form and solve an equation for \(c\) e.g. \(3 - c = 4 \Rightarrow c = \ldots\)
ddM1
1.1b
\(c = -1\) cso
A1
1.1b
(6)
(8 marks)
Notes
M1: Finds the determinant of a 3 by 3 matrix and sets = 0, this may be implied
A1: Correct determinant
A1: Correct value for \(b\)
dM1: Uses the equations of the three planes to find two equations by eliminating the same variable. Condone a slip on one coefficient or constant term
ddM1: Correctly uses their equations to form and solve an equation for \(c\)
A1: Correct value for \(c\)
Alternative 1
Scheme
Marks
AO
Uses the planes to eliminate one variable to form two equations e.g \(\left.\begin{aligned}2x + 2y - 2z &= 6\\ 2x + 3y + 5z &= 4\end{aligned}\right\} \Rightarrow -y - 7z = 2\) and \(\left.\begin{aligned}x + y - z &= 3\\ x + by + 13z &= c\end{aligned}\right\} \Rightarrow (1 - b)y - 14z = 3 - c\)
M1 A1 A1
3.1a 1.1b 1.1b
\(1 - b = -2 \Rightarrow b = \ldots\) or \(3 - c = 4 \Rightarrow c = \ldots\)
dM1
3.1a
\(1 - b = -2 \Rightarrow b = \ldots\) and \(3 - c = 4 \Rightarrow c = \ldots\)
ddM1
1.1b
\(b = 3\) and \(c = -1\) cso
A1
1.1b
(6)
M1: Uses the planes to eliminate one variable to form two equations
A1: One correct equation
A1: two correct equations
dM1: Sets up an equation for \(b\) or \(c\) by comparing coefficients and solves to find a value. Condone a slip on one coefficient or constant term
ddM1: Solves equations to find values for \(b\) and \(c\)
A1: Correct value for \(b\) and \(c\) cso
Note for 10 (b) using Alternative 1
Eliminating \(x\) gives
Eliminating \(y\) gives
Eliminating \(z\) gives
\(y + 7z = -2\)
\(x - 8z = 5\)
\(7x + 8y = 19\)
\((b - 1)y + 14z = c - 3\)
\((b - 1)x + (-b - 13)z = 3b - c\)
\(14x + (13 + b)y = 39 + c\)
\((2b - 3)y + 21z = 2c - 4\)
\((2b - 3)x + (5b - 39)z = 4b - 3c\)
\(21x + (39 - 5b)y = 52 - 5c\)
Alternative 2
Scheme
Marks
AO
eliminates one variable to form two equations e.g. \(\left.\begin{aligned}2x + 2y - 2z &= 6\\ 2x + 3y + 5z &= 4\end{aligned}\right\} \Rightarrow -y - 7z = 2 \Rightarrow y = -2 - 7z\) \(x + y - z = 3 \Rightarrow x + (-2 - 7z) - z = 3 \Rightarrow x = 5 + 8z\) Or Selects values for the coordinates to find two points that lie on the line of intersection e.g. \(z = 0 \Rightarrow x + y = 3\) and \(2x + 3y = 4 \Rightarrow (5, -2, 0)\) \(z = 1 \Rightarrow x + y - 1 = 3\) and \(2x + 3y - 5 = 4 \Rightarrow (13, -9, 1)\)
M1 A1 A1
3.1a 1.1b 1.1b
\(\begin{pmatrix}x\\ y\\ z\end{pmatrix} = \begin{pmatrix}5\\ -2\\ 0\end{pmatrix} + \lambda\begin{pmatrix}8\\ -7\\ 1\end{pmatrix}\) \(\begin{pmatrix}8\\ -7\\ 1\end{pmatrix}\) is perpendicular to \(\begin{pmatrix}1\\ b\\ 13\end{pmatrix}\) leading to \(8 - 7b + 13 = 0 \Rightarrow b = \ldots\) Or \(\begin{pmatrix}13\\ -9\\ 1\end{pmatrix} - \begin{pmatrix}5\\ -2\\ 0\end{pmatrix} = \begin{pmatrix}8\\ -7\\ 1\end{pmatrix}\) then \(\begin{pmatrix}8\\ -7\\ 1\end{pmatrix}\) is perpendicular to \(\begin{pmatrix}1\\ b\\ 13\end{pmatrix}\) leading to \(8 - 7b + 13 = 0 \Rightarrow b = \ldots\)
dM1
3.1a
\((5, -2, 0)\) lies on \(\Pi_3\) leading to \(5 - 2b = c\) Uses their \(b\) to find a value for \(c\)
ddM1
1.1b
\(b = 3\ \ c = -1\) cso
A1
1.1b
(6)
M1: Uses the planes to eliminate one variable to form two equations or substitutes in two values for one coordinate and solves to find two coordinates that lie on the line of intersection
A1: One correct equation or coordinate
A1: Two correct equations or coordinates
dM1: \(\begin{pmatrix}8\\ -7\\ 1\end{pmatrix}\) is perpendicular to \(\begin{pmatrix}1\\ b\\ 13\end{pmatrix}\) leading to \(8 - 7b + 13 = 0 \Rightarrow b = \ldots\) or uses their coordinates to find the direction vector and uses that it is perpendicular to \(\begin{pmatrix}1\\ b\\ 13\end{pmatrix}\) to find a value for \(b\)
ddM1: \((5, -2, 0)\) lies on \(\Pi_3\) leading to \(5 - 2b = c\)
M1: Finds the determinant of the matrix, sets \(= 0\) and solves to find a value of \(p\). Allow for any recognisable attempt at finding the determinant (may be slips in coefficients or signs). Accept if det \(= 14 - 7p\) appears with no working shown.
A1: \(p = 2\) from correct work.
Alt I Using normal
M1: Attempts the cross product between sets of pairs of planes and scales (if appropriate) and equates directions to solve for \(p\).
\(\left.\begin{aligned}2x - y + z &= 3\\ x + 2y - 3z &= q\end{aligned}\right\} \Rightarrow 3x + y - 2z = 3 + q\) compares with \(3x + y - 2z = 4\) leading to \(3 + q = 4 \Rightarrow q = \ldots\)
Alternatively \(\left.\begin{aligned}2x - y + z &= 3\\ 3x + y - 2z &= 4\end{aligned}\right\} \Rightarrow 5x - z = 7\) \(\left.\begin{aligned}4x - 2y + 2z &= 6\\ x + 2y - 3z &= q\end{aligned}\right\} \Rightarrow 5x - z = 6 + q \Rightarrow 6 + q = 7 \Rightarrow q = \ldots\)
M1
3.1a
\(q = 1\)
A1
1.1b
(2)
(4 marks)
Notes
M1: A complete method to find the value of \(q\). May be implied by correct value if no incorrect working is shown. E.g. Adds together equations 1 and 2 and compares with equation 3 to find a value for \(q\). Alternatively: Uses equations \(2x - y + z = 3\) and \(3x + y - 2z = 4\) to eliminate one variable. Uses equation \(x + 2y - 3z = q\) and one of the other equations to eliminate the same variable and compare to find a value for \(q\). Another possible method is to identify a point on both planes 1 and 3 (e.g. let \(x = 1\) and solve for \(y\) and \(z\) to get \((1,\ -3,\ -2)\) then substitute into middle equation to find \(q\))
A1: \(q = 1\)
Alternatively II the question may be done as a whole. Eg. \(\left.\begin{aligned}2x - y + z &= 3\\ 3x + y - 2z &= 4\end{aligned}\right\} \Rightarrow x + 2y - 3z = 1 \Rightarrow p = 2,\ q = 1\) is the most direct method. Variations are possible, e.g. \(\left.\begin{aligned}2x - y + z &= 3\\ x + py - 3z &= q\\ 3x + y - 2z &= 4\end{aligned}\right\} \Rightarrow \begin{aligned}&3(1) + (2): 7x + (p - 3)y = 9 + q\\ &2(1) + (3): \quad\ 7x - y = 10\end{aligned} \Rightarrow \begin{aligned}&p - 3 = -1 \Rightarrow p = \ldots\\ &9 + q = 10 \Rightarrow q = \ldots\end{aligned}\)
Score as follows:
M1: Attempts to solve at least two of the equations simultaneously to eliminate one variable or match coefficients of the third equation and uses the equation to identify one of the unknowns. Condone slips as long as the method is clear.
A1: Correct \(p\) or correct \(q\).
M1: Full method to use the linear dependence of the equations to find both variables.
A1: Correct \(p\) and \(q\).
Alt III: Using points on the common line.
M1: Finds two separate points on each of the first and third plane.
A1: Two correct points.
M1: Forms and solves two equations in \(p\) and \(q\) using their points.
A1: Correct \(p\) and \(q\).
E.g. \(x = 0 \Rightarrow \begin{cases}-y + z = 3\\ y - 2z = 4\end{cases} \Rightarrow y = -10,\ z = -7\) \(x = 1 \Rightarrow \begin{cases}-y + z = 1\\ y - 2z = 1\end{cases} \Rightarrow y = -3,\ z = -2\) \(\Rightarrow \begin{aligned}-10p + 21 &= q\\ 1 - 3p + 6 &= q\end{aligned} \Rightarrow p = \ldots,\ q = \ldots\)
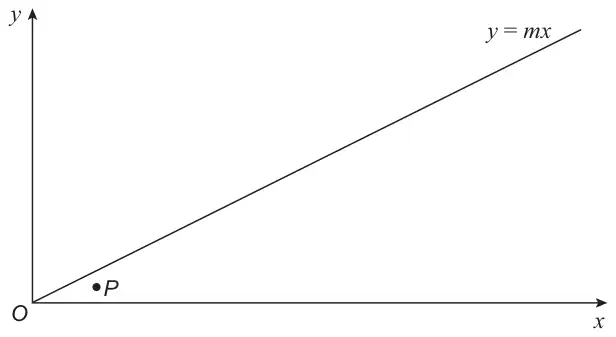
The matrix \(\mathbf{Q}\) represents the transformation \(Q\).
Triangle \(T\) is transformed to triangle \(T^{\prime}\) by the transformation \(Q\).
Given that
the coordinates of the vertices of \(T\) are (2, 3), (3, 6) and (8, 3)
the area of \(T^{\prime}\) is 4.5
determine the possible values of \(\theta\)
(Solutions relying entirely on calculator technology are not acceptable.)(7)
Mark scheme (i)(a)
Scheme
Marks
AO
Stretch
B1
1.1a
Scale factor 2 parallel to \(x\)-axis
B1
2.5
(2)
Notes
B1: See scheme, enlargement is B0
B1: See scheme, if they mention of \(y\)-axis must be correct e.g. scale factor 1, stays the same. Condone defining the stretch as from/about the origin and in the \(x\)- axis, along the \(x\)-axis
Mark scheme (i)(b)
Scheme
Marks
AO
Any line parallel to the \(x\)-axis or \(y = k\) or the \(y\)-axis or \(x = 0\)
B1
1.1b
(1)
Notes
B1: See scheme, any incorrect answer stated B0
Mark scheme (ii)
Scheme
Marks
AO
Area triangle \(= \dfrac{1}{2} \times (8 - 2)(6 - 3) = 9\) Area triangle for example \(\dfrac{1}{2}\begin{vmatrix}2 & 3 & 8 & 2\\ 3 & 6 & 3 & 3\end{vmatrix} = \dfrac{1}{2}\left[2 \times 6 + 3 \times 3 + 8 \times 3 - (3 \times 3 + 8 \times 6 + 2 \times 3)\right]\) Area triangle \(= \dfrac{1}{2}(6)\left(\sqrt{10}\right)\sin 71.57\) from a valid attempt to find the angle and sides
M1: Correct method to find the inverse matrix using their determinant
A1: Fully correct inverse matrix, isw
Mark scheme (b)
Scheme
Marks
AO
\(\begin{pmatrix}a & b\\ -1 & -1\end{pmatrix} + \dfrac{1}{b - a}\begin{pmatrix}-1 & -b\\ 1 & a\end{pmatrix} = \begin{pmatrix}1 & 0\\ 0 & 1\end{pmatrix}\) Which may include \(a - \dfrac{1}{b - a} = 1\) or \(-1 + \dfrac{1}{b - a} = 0\) or \(ab - a^2 - 1 = b - a\) or \(-b + a + 1 = 0\) \(b - \dfrac{b}{b - a} = 0\) or \(-1 + \dfrac{a}{b - a} = 1\) or \(b^2 - ab - b = 0\) or \(-b + a + a = b - a\)
M1
3.1a
Solves any two simultaneous equations to achieves a value for \(a\) and a value for \(b\) e.g., \(a - 1 = 1 \Rightarrow a = \ldots \Rightarrow b = \ldots\)
dM1
2.1
\(a = 2,\ b = 3\) only
A1
1.1b
(3)
(6 marks)
Notes
M1: A complete method to form two simultaneous equations in \(a\) and \(b\), using \(\mathbf{M} + \mathbf{M}^{-1} = \mathbf{I}\) and their inverse matrix
dM1: Solves their two different equations to achieve a value for \(a\) and a value for \(b\). Must come from a valid attempt at \(\mathbf{M} + \mathbf{M}^{-1} = \mathbf{I}\).
A1: Correct values for \(a\) and \(b\)
Alternative
Scheme
Marks
AO
\(\mathbf{M}^2 + \mathbf{I} = \mathbf{M}\quad \begin{pmatrix}a^2 - b & ab - b\\ -a + 1 & -b + 1\end{pmatrix} + \begin{pmatrix}1 & 0\\ 0 & 1\end{pmatrix} = \begin{pmatrix}a & b\\ -1 & -1\end{pmatrix}\) Leading to any two equations which may include \(-a + 1 = -1\) or \(-b + 1 + 1 = -1\)
M1
3.1a
Solves to achieves a value for \(a\) and a value for \(b\) e.g., \(a - 1 = 1 \Rightarrow a = \ldots \Rightarrow b = \ldots\)
dM1
2.1
\(a = 2,\ b = 3\)
A1
1.1b
(3)
(Corrected from the printed mark scheme: the bottom-right entry of \(\mathbf{M}^2\) is printed as \(-b + a\); it is \(-b + 1\), as used in the next line.)
M1: Forms the equation \(\mathbf{M}^2 + \mathbf{I} = \mathbf{M}\) and form two equations
dM1: Solves their equations to achieve a value for \(a\) and a value for \(b\)
(b) describe fully the single geometrical transformation \(P\) represented by the matrix \(\mathbf{B}\) (2)
The transformation \(Q\) is represented by the matrix \(\mathbf{A}^n\)
The transformation \(P\) followed by the transformation \(Q\) is the transformation \(R\), which is represented by the matrix \(\mathbf{C}\)
(c) Determine \(\mathbf{C}\) in terms of \(n\) (1)
Given that, for a particular value of \(n\), the transformation \(R\) maps the point with coordinates \((27,\ 1)\) to the point with coordinates \((a,\ a)\), where \(a\) is a constant,
(d) determine the matrix that represents the transformation \(Q\) (3)
Mark scheme (a)
Scheme
Marks
AO
\(n = 1,\ \text{LHS} = \begin{pmatrix}1 & 5\\ 0 & 2\end{pmatrix}^1 = \begin{pmatrix}1 & 5\\ 0 & 2\end{pmatrix},\ \text{RHS} = \begin{pmatrix}1 & 5\left(2^1 - 1\right)\\ 0 & 2^1\end{pmatrix} = \begin{pmatrix}1 & 5\\ 0 & 2\end{pmatrix}\) So the result is true for \(n = 1\)
“If true for \(n = k\) then true for \(n = k + 1\)” and as it is “true for \(n = 1\)” the statement is “true for all (positive integers) n”
A1
2.4
(6)
Notes
B1: Shows that the result holds for \(n = 1\). Must see substitution in the RHS minimum required is \(\begin{pmatrix}1 & 5(2 - 1)\\ 0 & 2\end{pmatrix}\) and reaches \(\begin{pmatrix}1 & 5\\ 0 & 2\end{pmatrix}\) No need to state “true for \(n = 1\)” for this mark.
M1: Assumes the result is true for some value of \(n = k\), and sets up a matrix multiplication of the assumed result multiplied by the original matrix, either way round (no need to carry out for this mark, it is for essentially explaining the procedure). “Assume (true for) \(n = k\)” (oe) is sufficient for the assumption and may even be part of the conclusion and accept any alternative wording that indicates the assumption has been made. Allow for setting up the multiplication in reverse (ie working from \(n = k + 1\) towards \(n = k\), \(\mathbf{A}^k = \mathbf{A}^{k+1}\mathbf{A}^{-1}\) oe)
M1: Carries out the multiplication. (Allow the reverse case.)
A1: Achieves a correct un-simplified matrix. Accept in working in reverse.
A1: Reaches a correct simplified matrix with no errors, the correct un-simplified matrix seen previously and at least one intermediate line which must be correct. If working from both sides all steps in showing the two sides are equal must be seen. If working in reverse they must return to \(\mathbf{A}^{k+1} = \ldots\) for this mark.
A1: Correct formal conclusion. This mark is dependent on the M and previous A marks having been scored and an attempt at the check for \(n = 1\) (if e.g. they didn’t show sufficient detail). It is gained by conveying the ideas of all three bold points at the end of their solution.
Note: Some cases may use \(n = 0\) as the base case. These can score full marks if dealt with correctly, but the conclusion must be consistent with their initial check to score the final A. For the B mark minimum \(\begin{pmatrix}1 & 5\\ 0 & 2\end{pmatrix}^0 = \begin{pmatrix}1 & 0\\ 0 & 1\end{pmatrix}\) ( or \(\mathbf{I}\)) and \(\begin{pmatrix}1 & 5(1 - 1)\\ 0 & 1\end{pmatrix} = \begin{pmatrix}1 & 0\\ 0 & 1\end{pmatrix}\) should be seen. (No need to state true for \(n = 0\) for this mark – but must have consistent conclusion for the final A as noted above). If unsure send to review.
Mark scheme (b)
Scheme
Marks
AO
Reflection
B1
1.1b
Reflection in the \(y\)-axis or line \(x = 0\)
B1
1.1b
(2)
Notes
B1: Identifies the transformation as a reflection. Accept stretch with scale factor \(-1\).
B1: Identifies reflection and the correct line of reflection. Condone phrasing such as “across the \(y\)-axis”. Must be a single transformation – B0 if they state something else also happens. NB Allow B1B0 for answers such as “flip in the y-axis” that convey the correct transformation in imprecise language.
M1: A complete method to find a value for \(2^n\) (or \(n\)). Multiplies the coordinates \((27,\ 1)\) by their matrix \(\mathbf{C}\) and sets the \(x\) and \(y\) coordinates equal to reach a value for \(2^n\) or \(n\) (condone negative values for \(2^n\)). Note you may allow this for reach a value of \(a\) if \(a = 2^n\) is stated or clearly implied by their working.
M1: Uses their value of \(2^n\) or \(n\), to find the matrix \(\mathbf{A}^n\). Note substituting into \(\mathbf{C}\) is M0 without further work to find \(\mathbf{A}^n\).
\[\mathbf{M} = \begin{pmatrix}3 & 6 & 0\\ a & 3 & 1\\ 2 & a & a\end{pmatrix} \qquad \text{where } a \text{ is a constant}\]
(a) Determine the values of \(a\) for which the matrix \(\mathbf{M}\) is singular. (3)
Given that matrix \(\mathbf{M}\) is non-singular and that
\(\det(\mathbf{M}) = -108\)
\(a \lt 0\)
(b) determine the matrix \(\mathbf{M}^{-1}\) (3)
Mark scheme (a)
Scheme
Marks
AO
\(\det(\mathbf{M}) = 3(3a - a) - 6(a^2 - 2) = 0\)
M1
1.2
\(6a^2 - 6a - 12 = 0 \Rightarrow a = \ldots\)
dM1
1.1b
\(a = -1,\ 2\)
A1
1.1b
(3)
Notes
M1: Finds the determinant of the matrix \(\mathbf{M}\) and sets \(= 0\) Allow for sight of \(\pm 3(3a - a) \pm 6(a^2 - 2) \pm 0(a^2 - 6) = 0\) and do not allow sign slips in their minors. Need not be simplified
dM1: Solves their 3TQ. Usual rules apply for solving a quadratic by any means including using a calculator.
A1: Both correct values for \(a\).
Note: Correct answers without a method can be awarded M1dM1A1
Alternatively, the determinant can be found using the vector product, for example:
If you are uncertain, please send to review
Mark scheme (b)
Scheme
Marks
AO
Sets determinant \(= -108\), solves a 3TQ to find a negative value of \(a\) \(-6a^2 + 6a + 12 = -108 \Rightarrow a = \ldots\) or \(6a^2 - 6a - 12 = 108 \Rightarrow a = \ldots\)
M1: A complete method to find a value for \(a\). Sets their determinant equal to \(-108\), solves a 3TQ and proceeds to find at least one negative value of \(a\). They must use their determinant equal to \(-108\) and not for example a changed quadratic from (a) equal to \(-108\). Usual rules apply for solving a quadratic by any means including using a calculator.
A1: Deduces \(a = -4\) only, which could be implied by a correct matrix.
A1: Correct matrix. Accept exact equivalents but not answers rounded to decimal places. Isw once a correct matrix is seen.
(a) Find, in terms of \(k\), \(\mathbf{A}^{-1}\) (4)
(b) Determine, in simplest form in terms of \(k\), the coordinates of the point where the following planes intersect.\[\begin{aligned}3x + y - z &= 3\\ x + y + z &= 1\\ kx + 3y + 6z &= 6\end{aligned}\] (3)
Cofactors \(\begin{pmatrix}3 & k - 6 & 3 - k\\ -9 & 18 + k & k - 9\\ 2 & -4 & 2\end{pmatrix}\) or Transpose of matrix of minors \(\begin{pmatrix}3 & 9 & 2\\ 6 - k & 18 + k & 4\\ 3 - k & 9 - k & 2\end{pmatrix}\)
M1
2.1
\(\mathbf{A}^{-1} = \dfrac{1}{2k}\begin{pmatrix}3 & -9 & 2\\ k - 6 & 18 + k & -4\\ 3 - k & k - 9 & 2\end{pmatrix}\)
dM1 A1
1.1b 1.1b
(4)
Notes
If no attempt at part (a) has been made you may award marks for work seen in part (b) for finding the inverse.
B1(M1 on epen): Correct determinant of \(2k\)
M1: Starts the process of finding the inverse and obtains at least 6 correct elements of cofactors Alternatively transposes their matrix of minors and obtains at least 6 correct elements.
dM1: A complete recognisable method to find the inverse including dividing by the determinant Allow minor slips if the process is clearly correct.
A1: Correct inverse.
Mark scheme (b)
Scheme
Marks
AO
\(\begin{pmatrix}x\\ y\\ z\end{pmatrix} = \dfrac{1}{2k}\begin{pmatrix}3 & -9 & 2\\ k - 6 & 18 + k & -4\\ 3 - k & k - 9 & 2\end{pmatrix}\begin{pmatrix}3\\ 1\\ 6\end{pmatrix} = \ldots\)
M1
1.1a
Any 2 of \(\ x = \dfrac{6}{k},\ \ y = \dfrac{2k - 12}{k},\ \ z = \dfrac{6 - k}{k}\)
A1
2.1
\(\left(\dfrac{6}{k}, \dfrac{2k - 12}{k}, \dfrac{6 - k}{k}\right)\) or \(x = \dfrac{6}{k},\ y = \dfrac{2k - 12}{k},\ z = \dfrac{6 - k}{k}\) or \(x = \dfrac{6}{k},\ y = 2 - \dfrac{12}{k},\ z = \dfrac{6}{k} - 1\)
A1
2.5
(3)
(7 marks)
Notes
M1: Attempts \(\mathbf{A}^{-1}\begin{pmatrix}3\\ 1\\ 6\end{pmatrix}\) with their \(\mathbf{A}^{-1}\) which must be in terms of \(k\), to obtain at least one of \(x =\), \(y =\) or \(z =\) which may be seen embedded in a column vector, simplified or unsimplified, the determinant may be outside their column vector. Condone a slip in copying \(\begin{pmatrix}3\\ 1\\ 6\end{pmatrix}\) e.g. \(\begin{pmatrix}1\\ 3\\ 6\end{pmatrix}\) or \(\begin{pmatrix}3\\ 1\\ 2\end{pmatrix}\)
A1(M1 on epen): Two correct expressions for \(x\), \(y\) or \(z\) simplified or unsimplified, which may appear in a column vector, determinant cannot be outside the vector.
A1: Correct coordinates in simplest form. Allow e.g. \(y = 2 - \dfrac{12}{k}\) Their final answer must be written as coordinates and not as a column vector but can be written as \(x =\), \(y =\) and \(z =\)
Alternative (using algebraic method for simultaneous equations):
M1: Solves simultaneously to obtain at least one of \(x =\), \(y =\) or \(z =\) must be in terms of \(k\).
A1(M1 on epen): Two correct expressions for \(x\), \(y\) or \(z\) simplified or unsimplified.
A1: Correct coordinates in simplest form. Allow e.g. \(y = 2 - \dfrac{12}{k}\) Their final answer must be written as coordinates and not as a column vector but can be written as \(x =\), \(y =\) and \(z =\)
e.g. Eliminates \(z\) and achieves \(4x + 2y = 4\) and \((6 - k)x + 3y = 0\) Uses \(12x + 6y = 12\) and \((12 - 2k)x + 6y = 0\) to produce \(2kx = 12 \Rightarrow x = \dfrac{6}{k}\)
(a) Determine the value of the constant \(c\) for which\[\mathbf{AB} = (3k + c)\mathbf{I}\] (2)
(b) Hence determine the value of \(k\) for which \(\mathbf{A}^{-1}\) does not exist. (2)
Given that \(\mathbf{A}^{-1}\) does exist,
(c) write down \(\mathbf{A}^{-1}\) in terms of \(k\). (1)
(d) Use the answer to part (c) to solve the simultaneous equations\[\begin{aligned}-x - 2y - 7z &= 10\\ 3x + ky + 2z &= 3\\ x + y + 4z &= 1\end{aligned}\]giving the values of \(x\), \(y\) and \(z\) in simplest form in terms of \(k\). (3)
Mark scheme (a)
Scheme
Marks
AO
\(-4k + 2 + 20 - 21 + 7k\) or \(3 + 3k - 2\) or \(7k - 4 - 19 + 24 - 4k\) or \(3k + 1\)
M1
1.1b
\(\{1 + 3k = 3k + c\}\) \(\Rightarrow c = 1\)
A1
1.1b
(2)
Notes
M1: Calculates one of the elements of the leading diagonal of AB, condone sign slips
A1: Sets diagonal = \(3k + c\) and deduces the correct value for \(c\). Award for sight of \(3k + 1\)
Mark scheme (b)
Scheme
Marks
AO
\(3k + 1 = 0 \Rightarrow k = \ldots\) Or Attempts the determinant and sets = 0 leading to a value for \(k\)
M1
1.1b
\(\Rightarrow k = -\dfrac{1}{3}\)
A1ft
1.1b
(2)
Notes
M1: Attempts to solve \(3k + \text{“}1\text{”} = 0\) or attempts the determinant, condone sign slips in the minors, and sets = 0 leading to a value for \(k\)
A1ft: Correct value or follow through their value for \(c\) so allow for \(k = -\dfrac{c}{3}\)
B1ft: Deduces the correct inverse matrix. Follow through their \(c\) so allow for \(\dfrac{1}{3k + c}\mathbf{B}\) or if found determinant \(\dfrac{1}{\text{their det}}\mathbf{B}\)
With respect to the right-hand rule, a rotation through \(\theta^\circ\) anticlockwise about the \(z\)-axis is represented by the matrix\[\begin{pmatrix}\cos\theta & -\sin\theta & 0\\ \sin\theta & \cos\theta & 0\\ 0 & 0 & 1\end{pmatrix}\]
represents a rotation through \(\alpha^\circ\) anticlockwise about the \(z\)-axis with respect to the right-hand rule,
(a) determine the value of \(\alpha\). (1)
(b) Hence determine the smallest possible positive integer value of \(k\) for which \(\mathbf{M}^k = \mathbf{I}\) (2)
The \(3 \times 3\) matrix \(\mathbf{N}\) represents a reflection in the plane with equation \(y = 0\)
(c) Write down the matrix \(\mathbf{N}\). (1)
The point \(A\) has coordinates \((-2, 4, 3)\)
The point \(B\) is the image of the point \(A\) under the transformation represented by matrix \(\mathbf{M}\) followed by the transformation represented by matrix \(\mathbf{N}\).
(d) Show that the coordinates of \(B\) are \(\left(2 + \sqrt{3},\ 2\sqrt{3} - 1,\ 3\right)\) (2)
Given that \(O\) is the origin,
(e) show that, to 3 significant figures, the size of angle \(AOB\) is 66.9° (2)
(f) Hence determine the area of triangle \(AOB\), giving your answer to 3 significant figures. (2)
Mark scheme (a)
Scheme
Marks
AO
\(\alpha = 210\)
B1
1.1b
(1)
Notes
B1: Correct value, check within the question. If more than one value is stated the correct value must clearly be selected.
Mark scheme (b)
Scheme
Marks
AO
Require \(k \times\)their ‘210’ divisible by 360
M1
1.1b
\(k = 12\)
A1
1.1b
(2)
Notes
M1: Uses their answer from part (a) to determine a value for \(k\) so that \(k \times\)their 210 is divisible by 360. If their answer to part (a) is in radians \(k \times \text{their } \dfrac{7\pi}{6}\) is divisible by \(2\pi\).
A1: Correct value must be using an angle of 210. There may be no working but allow M1 A1 for \(k = 12\) following an answer of 210 or \(\dfrac{7\pi}{6}\) in part (a)
Note: an angle of 30, 150, 330 also gives \(\boldsymbol{k = 12}\) but is M1A0
i.e. \(B\left(2 + \sqrt{3},\ 2\sqrt{3} - 1,\ 3\right)\) *
A1*
1.1b
(2)
Notes
M1: Complete method to find the coordinates of \(B\). Look for at least two correct terms for each multiplication, follow through when multiplying by N. Alternatively finds NM (not MN), look for 4 correct non zero terms if no method is shown and then multiplies to find the coordinates of \(B\).
A1*: Correct coordinates (condone vector) Must have been working with exact values throughout. If working in decimals M1 A0 It is insufficient to just write \(\mathbf{NM}\begin{pmatrix}-2\\ 4\\ 3\end{pmatrix} = \begin{pmatrix}\sqrt{3} + 2\\ 2\sqrt{3} - 1\\ 3\end{pmatrix}\) there must be some evidence of matrix multiplication seen.
M1: Identifies and applies an appropriate strategy to find the required angle e.g. cosine rule or scalar product. Note: \(AB^2 = 56 - 12\sqrt{3}\) and \(AB = 3\sqrt{6} - \sqrt{2} = 5.93\ldots\)
M1: Uses the given angle with \(\dfrac{1}{2}ab\sin C\) with appropriate \(a\), \(b\) and \(C\) Outside spec: uses the cross product \(\dfrac{1}{2}\left|\overrightarrow{OA} \times \overrightarrow{OB}\right|\)
(i) \[\mathbf{P} = \begin{pmatrix}k & -2 & 7\\ -3 & -5 & 2\\ k & k & 4\end{pmatrix} \qquad \text{where } k \text{ is a constant}\]Show that \(\mathbf{P}\) is non-singular for all real values of \(k\). (4)
(ii) \[\mathbf{Q} = \begin{pmatrix}2 & -1\\ -3 & 0\end{pmatrix}\]The matrix \(\mathbf{Q}\) represents a linear transformation \(T\)
Under \(T\), the point \(A(a, 2)\) and the point \(B(4, -a)\), where \(a\) is a constant, are transformed to the points \(A'\) and \(B'\) respectively.
Given that the distance \(A' B'\) is \(\sqrt{58}\), determine the possible values of \(a\). (5)
Mark scheme (i)
Scheme
Marks
AO
\(\begin{vmatrix}k & -2 & 7\\ -3 & -5 & 2\\ k & k & 4\end{vmatrix} = k(-20 - 2k) + 2(-12 - 2k) + 7(-3k + 5k)\) or \(\begin{vmatrix}k & -2 & 7 & k & -2\\ -3 & -5 & 2 & -3 & -5\\ k & k & 4 & k & k\end{vmatrix} = k(-5)(4) - 2(2)(k) + 7(-3)(k)\) \(\qquad - 7(-5)(k) - k(2)(k) - (-2)(-3)(4)\)
\(b^2 - 4ac = -92 < 0\) therefore no real roots so non-singular \(b^2 - 4ac = -23 < 0\) therefore no real roots so non-singular Or Square of negative is not real therefore non-singular Or \((k + 2.5)^2 + 5.75 > 0\) therefore no real roots so non-singular \(-2(k + 2.5)^2 - 11.5 < 0\) therefore no real roots so non-singular Or As negative quadratic maximum value of determinant = −11.5 therefore no real roots so non-singular Or Imaginary roots therefore no real roots so non-singular
A1
2.4
(4)
Notes
(Corrected from the printed mark scheme: the completed-square, quadratic-formula and vertex lines are printed with \(-2k^2 - 10k - 25\), \(-2(k + 2.5)^2 - 12.5\), \(-4(-2)(-25)\), "determinant = −5.75" and "maximum value of determinant = −5.25". The determinant is \(-2k^2 - 10k - 24 = -2(k + 2.5)^2 - 11.5\), so these are typed with −24, −11.5 and a maximum value of −11.5.)
M1: Correct method to find the determinant, condone a single sign slip but not on second term must be +2 (…) Note: May expand along any row or column. A1: Correct simplified determinant
M1: Either
Finds the value of the discriminant or sufficient working seen to identify the sign e.g. 100 – 192
Completes the square an rearranges so that \((k \pm a)^2 = -b\)
Completes the square and states that \((k \pm a)^2 \geqslant 0\)
Completes the square and states that \(-\alpha(k \pm a)^2 \leqslant 0\)
Differentiates the determinant to find the coordinates of the vertex
Use the quadratic formula to find the imaginary roots
A1: Correct solution only Either
Correct value for the discriminant (may be implied), concludes less than 0, therefore no real roots and non singular.
Correct completing the square and conclude no real roots as square root of negative therefore non singular
Correct completing the square and shows > 0 therefore no real roots and non singular.
Correct completing the square and shows < 0 therefore no real roots and non singular.
Correct coordinates of the vertex and negative quadratic therefore no real roots and non singular.
Use the quadratics formula to find the correct imaginary roots therefore no real roots/value for \(k\) and non singular.
Note \(k = \dfrac{-5 \pm \sqrt{23}\mathrm{i}}{2}\) which is not real is M0 A0 unless uses the quadratic formula or completing the square to show where this has come from
Mark scheme (ii)
Scheme
Marks
AO
\(\begin{pmatrix}2 & -1\\ -3 & 0\end{pmatrix}\begin{pmatrix}a & 4\\ 2 & -a\end{pmatrix} = \begin{pmatrix}\ldots & \ldots\\ \ldots & \ldots\end{pmatrix}\) can be done separately for each point
M1
3.1a
\(\begin{pmatrix}2a - 2 & 8 + a\\ -3a & -12\end{pmatrix}\) or \((2a - 2,\ -3a)\) and \((8 + a,\ -12)\)
M1: Uses matrix Q to find the coordinates of the points \(A'\) and \(B'\). Condone a sign slip. A1: Correct coordinates for the points \(A'\) and \(B'\), they do not need to be labelled M1: Finds the distance between their points \(A'\) and \(B'\) which must not be equal to \(A\) and \(B\), sets equal to \(\sqrt{58}\), forms a 3TQ. A1: Correct 3TQ form correct coordinates A1: Correct values cso
Misread: A common misread is 3 instead of – 3, the first 3 mark only can be scored using the misread rule
where \(a\) and \(b\) are constants, and \(N_n\), \(J_n\) and \(B_n\) are the respective numbers of the mammals in each category \(n\) months after the start of the study.
At the start of the study the colony has breeders only, with no newborns or juveniles.
According to the model, after 2 months the number of newborns is 48 and the number of juveniles is 40
(b)
(i) Determine the number of mammals in the colony at the start of the study.
(ii) Show that \(a = 0.8\) (4)
(c) Determine, in terms of \(b\),\[\begin{pmatrix}0 & 0 & 2\\ 0.8 & b & 0\\ 0 & 0.48 & 0.96\end{pmatrix}^{-1}\] (3)
Given that the model predicts approximately 1015 mammals in total at the start of a particular month, and approximately 596 newborns, 464 juveniles and 437 breeders at the start of the next month,
(d) determine the value of \(b\), giving your answer to 2 decimal places. (3)
It is decided to monitor the number of newborn males and females as a part of the study. Assuming that 42% of newborns are male,
(e) refine the matrix equation for the model to reflect this information, giving a reason for your answer. (There is no need to estimate any unknown values for the refined model, but any known values should be made clear.) (2)
Mark scheme (a)
Scheme
Marks
AO
Accept E.g.
1 month is too old for “newborn”
The mammals might not start breeding at exactly 3 months old
The mammals will stop breeding beyond a certain age
Being over 3 months old doesn’t necessarily mean the mammal can breed
Some mammals over 3 months may be infertile so will not be breeders
Some juveniles might be breeders
But not
The size of the categories is different
There might be overlap
The exact age of mammals might not be known
The numbers in each category will be different
Breeding age is different for different species
B1
3.5b
(1)
Notes
B1: Any valid limitation – see scheme for some examples. Must refer to a feature of the categories given.
dM1: Forms an equation, in their variable for number of breeders at the start, setting their number of newborns after 2 months equal to 48 and solves for their variable to find the initial number of breeders.
A1: For identifying 25 mammals at the start of the study. Allow 25 mammals or just 25 or e.g. \(B_0 = 25\) so ignore how they label it just look for 25
(ii) A1*: For correctly showing \(a = 0.8\). Must see the correct work to establish the correct value or equivalent by verification with a minimal conclusion e.g.
B1: Deduces correct determinant for the matrix. Allow equivalents e.g. \(\dfrac{96}{125}\) May be implied.
M1: Recognisable attempt at the adjoint matrix. Look for at least 3 non-zero entries correct.
A1: Correct inverse. Accept awrt \(-2.6b\) for the upper right entry and awrt 2.08 for middle right entry, or accept with determinant still outside. Apply isw once a correct answer is seen.
\(\Rightarrow 1015 = x + y + z = 745b + 580 - 1138b - 596 + 910.4 + 298 \Rightarrow b = \ldots\)
dM1
3.4
\(b =\) awrt 0.45
A1
1.1b
(3)
Notes
(d) Alternative:
Scheme
Marks
AO
\(\begin{pmatrix}0 & 0 & 2\\ 0.8 & b & 0\\ 0 & 0.48 & 0.96\end{pmatrix}\begin{pmatrix}x\\ y\\ z\end{pmatrix} = \begin{pmatrix}596\\ 464\\ 437\end{pmatrix} \Rightarrow \begin{aligned}2z &= 596\\ 0.8x + by &= 464\\ 0.48y + 0.96z &= 437\end{aligned}\) \(\Rightarrow z = 298,\ y = \dfrac{3773}{12}\,(314.4\ldots)\) \(x + y + z = 1015 \Rightarrow x = \ldots\dfrac{4831}{12}\,(402.5\ldots)\)
M1
3.1b
\(0.8x + by = 464 \Rightarrow 0.8 \times \dfrac{4831}{12} + b \times \dfrac{3773}{12} = 464 \Rightarrow b = \ldots\)
dM1
3.4
\(b =\) awrt 0.45
A1
1.1b
(3)
Notes
M1: Attempts (their inverse matrix) \(\times \begin{pmatrix}596\\ 464\\ 437\end{pmatrix}\) correctly and adds the 3 expressions together to find the total in terms of \(b\).
M1: Sets their total = 1015 and solves for \(b\).
A1: awrt 0.45
Alternative: M1: Uses the original matrix with \(a = 0.8\) and \(\begin{pmatrix}596\\ 464\\ 437\end{pmatrix}\) to form 3 equations in their variables and \(b\) and uses these and the 1015 to find the number of Newborns. M1: Uses their values in the \(y\) component and solves for \(b\). A1: awrt 0.45
M1: Defines new variables for male and female newborns (accept if a clear notation is used if not defined) and sets up a 4×4 matrix with structure shown, or male and female rows swapped, with the correct 0 entries in at least 4 places.
A1ft: Fully correct matrix system shown, accepting anything (including 0) for the unknown spaces shown – but must have all the 0’s and upper right entries correct. Accept \(b\) or their value of \(b\) in place of 0.45
Hence result is true for \(n = k + 1\). As true for \(n = 1\) and have shown if true for \(n = k\) then it is true for \(n = k + 1\), so it is true for all \(n\).
A1
2.5
(5)
(5 marks)
Notes
B1: Shows true for \(n = 1\). Need to see \(n = 1\) substituted into rhs. The minimum for B1 would be \(\begin{pmatrix}1 & -2 \times 1\\ 0 & 1\end{pmatrix} = \begin{pmatrix}1 & -2\\ 0 & 1\end{pmatrix}\). There is no need to state “True for \(n = 1\)”
M1: (Assumes for \(n = k\) and) multiplies original matrix by \(k\)th power matrix either way round. Note that the assumption statement is not needed for this mark (but see below) so just look for:
A1: Reaches correct form for the matrix with the \(k + 1\) factored out with no errors and the correct unsimplified matrix seen previously. Note that the result may be proved by equivalence (see below).
A1: Correct conclusion with assumption made (which may be implied in their conclusion if they say “if true for \(n = k\) then…”). This mark is dependent on all the previous marks apart from the B mark and is gained by conveying all the underlined points. Allow this mark to score as long as all the underlined points are seen as narrative in their solution. There must be the assumption statement somewhere or the “if…then…” idea in the conclusion. If awarded for the assumption statement condone e.g. true for \(n = k\) in the conclusion.
The conclusion must convey the “if true for \(n = k\) then true for \(n = k + 1\)” idea and not e.g. true for \(k\), true for \(k + 1\), true for 1 therefore…but see the previous note. For the “true for all \(n\)” part condone e.g. “true for \(n\)”, “true for all integers after 1”, “true for \(\mathbb{Z}^+\)”, But do not allow “true for all values”, “true for all real numbers”
Q4 Extra Notes:
1. For candidates who use \(n\) instead of \(k\) throughout withhold the final mark if the work is otherwise correct.
2. For equivalence proofs, this would be minimally acceptable:
“Need to prove” oe e.g. “target is”, “\(n = k + 1\)”, “need” etc. \(\begin{pmatrix}1 & -2\\ 0 & 1\end{pmatrix}^{k+1} = \begin{pmatrix}1 & -2k - 2\\ 0 & 1\end{pmatrix}\)
Note that there must be a reference to \(k + 1\) as above or e.g. (Target =) \(\begin{pmatrix}1 & -2(k + 1)\\ 0 & 1\end{pmatrix} = \begin{pmatrix}1 & -2k - 2\\ 0 & 1\end{pmatrix}\)
Hence result is true for \(n = k + 1\). As true for \(n = 1\) and have shown if true for \(n = k\) then it is true for \(n = k + 1\), so it is true for all \(n\). A1
Without the “Need to prove…” oe the response would score B1M1A1 and then A1 if the factorised form was shown or equivalence shown and then A1 for the correct conclusion.
3. Allow e.g. “correct” for “true” in the conclusion
The transformation \(B\) is represented by the matrix \(\mathbf{B}\). The transformation \(A\) followed by the transformation \(B\) is the transformation \(C\), which is represented by the matrix \(\mathbf{C}\).
To determine matrix \(\mathbf{C}\), a student attempts the following matrix multiplication.
(c) Determine the correct matrix \(\mathbf{C}\). (1)
Mark scheme (a)
Scheme
Marks
AO
Rotation
B1
1.1b
30 degrees or \(\dfrac{\pi}{6}\) about the \(x\)-axis Ignore any reference to direction
B1
1.1b
(2)
Notes
B1: Identifies the single transformation as a rotation only
B1: Correct angle and axis. Ignore any reference to direction. Note \(x\)-plane, \(zy\)-plane and \(x = 0\) are 2nd B0 Any additional incorrect statements is 2nd B0
Mark scheme (b)
Scheme
Marks
AO
They have found AB when they should find BA Multiplication is the wrong way round It should be BA Matrix B should be on the left instead of the right Student has done transformation B followed by transformation A It should be \(\begin{pmatrix}1 & 3 & 0\\ \sqrt{3} & 0 & 5\sqrt{3}\\ 1 & 2 & 0\end{pmatrix}\begin{pmatrix}1 & 0 & 0\\[4pt] 0 & \dfrac{\sqrt{3}}{2} & -\dfrac{1}{2}\\[8pt] 0 & \dfrac{1}{2} & \dfrac{\sqrt{3}}{2}\end{pmatrix}\)
B1
2.3
(1)
Notes
B1: Explains that they should be multiplied the other way around
M1: Evaluates \(\mathbf{M}^2\) and uses in the equation given.
A1: Correct value of \(a\) deduced
A1*: Correct work to show \(k = -9\). If off diagonals are used no further justification is needed (they are “given” the result is true). If the bottom right entry is used there must be a valid reason for rejecting \(-2\) as a solution (ie checking the off diagonal).
Alternative: Using \(k = -9\) M1: Evaluates \(\mathbf{M}^2\) and uses in the equation given. A1: Correct value of \(a\) deduced A1*: Draws the conclusion that \(k = -9\)
\(m = \dfrac{3}{5} \Rightarrow 5m + 10 \neq 0\) so need \(c = 0\) hence \(y = \dfrac{3}{5}x\) is a fixed line
A1
2.2a
\(m = -2 \Rightarrow 5m + 10 = 0\) so \(c\) can be anything, so \(y = -2x + c\) for any \(c\) is fixed.
A1
2.2a
(6)
Notes
M1: Sets up the matrix equation for invariant lines and extracts the simultaneous equations from the matrix equation.
M1: Eliminates “\(X\)” to get a linear equation in “\(x\)”.
A1: Correct equation need not be simplified isw
M1: Solves their quadratic equation in \(m\) by any valid means including calculator
A1: Deduces \(y = \dfrac{3}{5}x\) is a fixed line (where \(c = 0\)). If the value for \(m\) here is wrong, allow this A for \(y = -2x\) if the general case for the final A is not scored.
A1: Deduces \(y = -2x + c\) is a fixed line where \(c\) can be any value. Must include all the lines.
Note: \(y = \dfrac{3}{5}x\) and \(y = -2x\) scores final A1 A0
M1: Sets up the matrix equation for invariant lines and extracts the simultaneous equations from the matrix equation.
M1: Eliminates “\(X\)” to get a linear equation in “\(x\)”. \(\Rightarrow 6x - 9mx = -2mx + 5m^2x\)
A0: Incorrect equation.
M1: Solves their quadratic equation in \(m\) by any valid means. \(\Rightarrow 5m^2 + 7m - 6 = 0 \Rightarrow (m + 2)(5m - 3) \Rightarrow m = -2, \dfrac{3}{5}\)
A1: Deduces \(y = \dfrac{3}{5}x\) is a fixed line (where \(c = 0\)). If the value for \(m\) here is wrong, allow this A for \(y = -2x\) if the general case for the final A is not scored.
A0: Incorrect equation
Special Case 2 Finding the line of invariant points M1M0A0M0A1A0
M1: Sets up the matrix equation for a line of invariant points and extracts the simultaneous equations from the matrix equation.
M0 A0 M0
A1: Deduces \(y = \dfrac{3}{5}x\) is a fixed line
A0: Incorrect equation
Outside the specification
M1: Find the eigenvalues \(\begin{pmatrix}-2 - \lambda & 5\\ 6 & -9 - \lambda\end{pmatrix} \Rightarrow (-2 - \lambda)(-9 - \lambda) - 6 \times 5 = 0\) leading to a 3TQ and solves to find a value for \(\lambda\), \(\lambda^2 + 11\lambda - 12 = 0 \Rightarrow \lambda = \ldots\{1, -12\}\)
M1: Uses one of their eigenvalues to find an equation \(\begin{pmatrix}-2 & 5\\ 6 & -9\end{pmatrix}\begin{pmatrix}x\\ y\end{pmatrix} = -12\begin{pmatrix}x\\ y\end{pmatrix} \Rightarrow \ldots\{y = -2x\}\) or \(\begin{pmatrix}-2 & 5\\ 6 & -9\end{pmatrix}\begin{pmatrix}x\\ y\end{pmatrix} = \begin{pmatrix}x\\ y\end{pmatrix} \Rightarrow \ldots\{5y = 3x\}\)
(corrected from the printed mark scheme: the factor \((-2 - \lambda)\) is printed as \((2 - \lambda)\), and the bottom right entry of the matrix in the two eigenvector equations is printed as \(9\) instead of \(-9\))
A1: One correct equation
M1: Uses both of their eigenvalues to find an equation
A1: Deduces \(y = \dfrac{3}{5}x\)
A1: Deduces \(y = -2x + c\)
Mark scheme (c)
Scheme
Marks
AO
(\((0, c) \rightarrow (5c, -9c)\) so need \(c = 0\),) \((1, m) \rightarrow (-2 + 5m, 6 - 9m)\) so need or \(5m = 3\) hence \(y = \dfrac{3}{5}x\) contains fixed points. or \(\begin{pmatrix}-2 & 5\\ 6 & -9\end{pmatrix}\begin{pmatrix}x\\ \frac{3}{5}x\end{pmatrix} = \begin{pmatrix}-2x + 3x\\ 6x - \frac{27}{5}x\end{pmatrix} = \begin{pmatrix}x\\ \frac{3}{5}x\end{pmatrix} \Rightarrow y = \dfrac{3}{5}x\) or \(\begin{pmatrix}-2 & 5\\ 6 & -9\end{pmatrix}\begin{pmatrix}x\\ y\end{pmatrix} = \begin{pmatrix}x\\ y\end{pmatrix} \Rightarrow \begin{cases}-2x + 5y = x\\ 6x - 9y = y\end{cases} \Rightarrow y = \dfrac{3}{5}x\)
B1
3.2a
(1)
(10 marks)
Notes
B1: Identifies \(y = \dfrac{3}{5}x\) is a line of fixed points with reason. Allow if \(c = 0\) is assumed. See scheme for possible reason.
\[\begin{pmatrix}x & 9\\ y & z\end{pmatrix} - 3\begin{pmatrix}z & y\\ z & y\end{pmatrix} = k\mathbf{I}\]
where \(x\), \(y\), \(z\) and \(k\) are constants.
Determine the value of \(x\), the value of \(y\) and the value of \(z\). (4)
Mark scheme
Scheme
Marks
AO
\(y = 3\)
B1
2.2a
\(z = \dfrac{\text{their } y}{3} = \ldots\{1\}\)
B1ft
1.1b
Uses \(z - 3y = k \Rightarrow k = -8\) and \(x - 3z = k \Rightarrow x = k + 3z = \text{their } k + 3 \times \text{their } z\) leading to a value for \(x\) Alternatively uses \(x - 3z = k = z - 3y\) with values for \(y\) and \(z\) to find a value for \(x\).
M1
3.1a
\(x = -5\)
A1
1.1b
(4)
(4 marks)
Notes
B1: \(y = 3\)
B1ft: Follow through on the value of \(z\) which comes from their \(y\) divided by 3
M1: A complete method to find the value of \(x\). Uses \(z - 3y = k\) to find a value for \(k\) then finds a value for \(x\) using \(x - 3z = k\) and their values for \(z\) and \(k\). Condone a slip with the coefficients if the intention is clear but must have the correct letters. Alternatively uses \(x - 3z = k = z - 3y\) with values for \(y\) and \(z\) to find a value for \(x\).
A1: \(x = -5\) Correct answers only scores full marks.
Achieves from fully correct working \(= \begin{pmatrix}-5 - 6k & 9 + 9k\\ -4 - 4k & 7 + 6k\end{pmatrix}\)
A1
1.1b
\(= \begin{pmatrix}1 - 6(k + 1) & 9(k + 1)\\ -4(k + 1) & 1 + 6(k + 1)\end{pmatrix}\) Hence the result is true for \(n = k + 1\). Since it is true for \(n = 1\), and if true for \(n = k\) then true for \(n = k + 1\), thus by mathematical induction the result holds for all \(n \in \mathbb{N}\)
A1cso
2.4
(6)
(6 marks)
Notes
B1: Shows the statement is true for \(n = 1\). Accept as minimum \(\begin{pmatrix}1 - 6 & 9\\ -4 & 1 + 6\end{pmatrix} = \begin{pmatrix}-5 & 9\\ -4 & 7\end{pmatrix}\)
M1: Makes the inductive assumption, assume true \(\boldsymbol{n = k}\). This may appear in the conclusion.
M1: A correct statement for \(\begin{pmatrix}-5 & 9\\ -4 & 7\end{pmatrix}^{k+1}\) in terms of \(\begin{pmatrix}-5 & 9\\ -4 & 7\end{pmatrix}^k\), can be either way round. Can be implied by \(\begin{pmatrix}1 - 6k & 9k\\ -4k & 1 + 6k\end{pmatrix}\times\begin{pmatrix}-5 & 9\\ -4 & 7\end{pmatrix}\) or \(\begin{pmatrix}-5 & 9\\ -4 & 7\end{pmatrix}\times\begin{pmatrix}1 - 6k & 9k\\ -4k & 1 + 6k\end{pmatrix}\)
M1: Carries out the multiplication correctly, condone sign slips
A1: Correct simplified matrix from fully correct working
A1: Completes the inductive argument by showing clearly the matrix has the correct form (must have \((k + 1)\) factors in terms) or uses the result with \(n = k + 1\) and shows that their result is the same. Conclusion conveying all three underlined points or equivalent at some point in their argument. Depends on all three M’s and A marks but can be scored without the B mark as long as it is stated true for \(n = 1\)
\[\mathbf{M} = \begin{pmatrix}a & 2 & -3\\ 2 & 3 & 0\\ 4 & a & 2\end{pmatrix} \qquad \text{where } a \text{ is a constant}\]
(a) Show that \(\mathbf{M}\) is non-singular for all values of \(a\). (2)
(b) Determine, in terms of \(a\), \(\mathbf{M}^{-1}\) (4)
Mark scheme (a)
Scheme
Marks
AO
\(\det(\mathbf{M}) = a(6) - 2(4) - 3(2a - 12)\)
M1
1.1b
\(\det(\mathbf{M}) = 28 \neq 0\) therefore, non-singular for all values of \(a\)
A1
2.4
(2)
Notes
M1: Finds the determinant of the matrix \(\mathbf{M}\). Must be seen in part (a). Allow one slip if no method shown.
A1: Correct value for determinant, states doesn’t equal 0 (accept \(\gt 0\)) and draws the conclusion that the matrix is non-singular. If non-singular meaning determinant is non-zero is given in a preamble then accept a minimal conclusion (e.g. “hence shown”), but there must be a conclusion.
M1: Finds the matrix of minors, at least 5 correct values.
M1: Finds the matrix of cofactors and transposes (in either order). Note: some will do all these steps in one go, which is fine as long as it is clear what they have done. Allow minor slips if the process is clearly correct.
M1: Completes the process to find the inverse matrix, divides by the determinant.
With respect to the right-hand rule, a rotation through \(\theta^\circ\) anticlockwise about the \(y\)-axis is represented by the matrix\[\begin{pmatrix}\cos\theta & 0 & \sin\theta\\ 0 & 1 & 0\\ -\sin\theta & 0 & \cos\theta\end{pmatrix}\]
The point \(P\) has coordinates (8, 3, 2)
The point \(Q\) is the image of \(P\) under the transformation reflection in the plane \(y = 0\)
(a) Write down the coordinates of \(Q\) (1)
The point \(R\) is the image of \(P\) under the transformation rotation through 120° anticlockwise about the \(y\)-axis, with respect to the right-hand rule.
(b) Determine the exact coordinates of \(R\) (2)
(c) Hence find \(\left|\overrightarrow{PR}\right|\) giving your answer as a simplified surd. (2)
(d) Show that \(\overrightarrow{PR}\) and \(\overrightarrow{PQ}\) are perpendicular. (1)
(e) Hence determine the exact area of triangle \(PQR\), giving your answer as a surd in simplest form. (2)
Mark scheme (a)
Scheme
Marks
AO
Coordinates of \(Q\) are \((8, -3, 2)\)
B1
2.2a
(1)
Notes
B1: Coordinates of \(Q\) correctly stated, accept as a column vector.
So \(R\) is \(\left(-4 + \sqrt{3},\ 3,\ -4\sqrt{3} - 1\right)\)
A1
1.1b
(2)
Notes
M1: Correct attempt to find coordinates of \(R\) using the given matrix with \(\theta = 120\). Must be multiplying in the correct way round. With no working two correct values or (−2.27, 3, −7.93) implies this mark.
A1: Correct exact coordinates as shown in scheme. Accept as a column vector. Cos 120 and sin 120 must have been evaluated.
Mark scheme (c)
Scheme
Marks
AO
Finds the distance\[PR = \sqrt{\left(8 - \text{‘}\left(-4 + \sqrt{3}\right)\text{’}\right)^2 + (3 - \text{‘}3\text{’})^2 + \left(2 - \text{‘}\left(-4\sqrt{3} - 1\right)\text{’}\right)^2}\]Alternatively finds their \(\overrightarrow{PR}\) or their \(\overrightarrow{RP}\) then applies length of a vector formula.\[\sqrt{\left(12 - \sqrt{3}\right)^2 + \left(3 + 4\sqrt{3}\right)^2}\ \text{ or }\ \sqrt{\left(-12 + \sqrt{3}\right)^2 + \left(-3 - 4\sqrt{3}\right)^2}\]
M1
2.1
\(= \sqrt{204}\ \left(= 2\sqrt{51}\right)\) cso
A1
1.1b
(2)
Notes
M1: Applies the distance formula with the coordinates of \(P\) and their \(R\). Alternatively finds the vector \(\overrightarrow{PR}\) or \(\overrightarrow{RP}\) then applies length of a vector formula.
A1: Correct answer following correct coordinates of \(R\), must be a surd but need not be fully simplified.
B1ft: Shows the dot product is zero between the vectors \(\overrightarrow{PR}\) and \(\overrightarrow{PQ}\) and draws the conclusion perpendicular. Accept with \(\pm\) vectors for each. Follow through as long as the vectors are of the correct form, so \(\overrightarrow{PR} = \begin{pmatrix}a\\ 0\\ b\end{pmatrix}\) and \(\overrightarrow{PQ} = \begin{pmatrix}0\\ c\\ 0\end{pmatrix}\)
Note They could state if vectors \(\overrightarrow{PR}\) and \(\overrightarrow{PQ}\) are perpendicular then \(\overrightarrow{PR}.\overrightarrow{PQ} = 0\) then shows \(\overrightarrow{PR}.\overrightarrow{PQ} = 0\) this is B1
Mark scheme (e)
Scheme
Marks
AO
\(PQ\) is perpendicular to \(PR\) so Area \(= \dfrac{1}{2} \times PQ \times PR\)
M1: Correct method for the area of the triangle, follow through on their coordinates of \(R\) and \(Q\). May see longer methods if they do not realise the triangle is right angled.
A1: For \(6\sqrt{51}\) cso following correct coordinates of \(R\)
Alternative 1
M1 Complete method to find the correct area Finding all the lengths \(|PQ| = 6,\ |PR| = \sqrt{204} = 2\sqrt{51},\ |QR| = \sqrt{240} = 4\sqrt{15}\) Use cosine rule to find an angle e.g. \(\cos PRQ = \dfrac{240 + 204 - 36}{2 \times \sqrt{240} \times \sqrt{204}} = \dfrac{\sqrt{85}}{10}\) leading to \(PRQ = 22.7\ldots\) or \(\sin PRQ = \sqrt{1 - \left(\dfrac{\sqrt{85}}{10}\right)^2} = \ldots\left\{\dfrac{\sqrt{15}}{10}\right\}\) Uses the area of the triangle \(= \dfrac{1}{2} \times \sqrt{240} \times \sqrt{204} \times \dfrac{\sqrt{15}}{10}\) or \(= \dfrac{1}{2} \times \sqrt{240} \times \sqrt{204} \times \sin 22.8\)
(Corrected from the printed mark scheme: the printed scheme has \(|PR| = \sqrt{240} = 4\sqrt{15}\) and \(|QR| = \sqrt{204} = 2\sqrt{51}\); these two lengths are the wrong way round, since part (c) gives \(|PR| = \sqrt{204}\).)
(Corrected from the printed mark scheme: the printed cross product is \(-6\left(12 - \sqrt{3}\right)\mathbf{i} + 6\left(3 + 4\sqrt{3}\right)\mathbf{k}\), with the \(\mathbf{i}\) and \(\mathbf{k}\) components the wrong way round. The area is unchanged.)
If true for \(n = k\) then true for \(n = k + 1\) and as it is true for \(n = 1\) the statement is true for all (positive integers) \(\boldsymbol{n}\)
A1
2.4
(6)
Notes
B1: Shows that the result holds for \(n = 1\). Must see substitution in the RHS minimum required is \(\begin{pmatrix}3 & \frac{a}{2}(3 - 1)\\ 0 & 1\end{pmatrix}\) and reaches \(\begin{pmatrix}3 & a\\ 0 & 1\end{pmatrix}\)
M1: Assumes the result is true for some value of \(n = k\). Assume (true for) \(n = k\) is sufficient. Alternatively states assume \(\mathbf{M}^n\) or \(\begin{pmatrix}3 & a\\ 0 & 1\end{pmatrix}^k = \begin{pmatrix}3^{k} & \dfrac{a}{2}\left(3^{k} - 1\right)\\ 0 & 1\end{pmatrix}\)
M1: Sets up a matrix multiplication of their assumed result multiplied by the original matrix, either way round. Allow a slip as long as the intention is clear.
A1: Achieves a correct un-simplified matrix
A1: Reaches a correct simplified matrix with no errors, the correct un-simplified matrix seen previously and at least one intermediate line which must be correct.
A1: Correct conclusion. This mark is dependent on all previous marks except B mark but \(n = 1\) must have been attempted. It is gained by conveying the ideas of all four bold points either at the end of their solution or as a narrative in their solution. Condone \(n \in \mathbb{Z}\)
Mark scheme (b)
Scheme
Marks
AO
(i) \(\det\left(\mathbf{M}^n\right) = 3^n\) or \(\det(\mathbf{M}) = 3\)
(i) B1: States correct determinant. This can be implied by a correct equation
M1: Correct method to find a value of \(n\) using \(5 \times \text{`their } \det\left(\mathbf{M}^n\right)\text{'} = 1215\) which involves solving an index equation of the form \(p^n = q\) where \(n \gt 1\)
A1: \(n = 5\)
(ii) M1: Sets up an equation by multiplying the matrix \(\mathbf{M}^n\) by \(\begin{pmatrix}2\\ -2\end{pmatrix}\) setting equal to \(\begin{pmatrix}123\\ -2\end{pmatrix}\) and reaches a value for \(a\). You may just see \(2\left(3^n\right) - 2\dfrac{a}{2}\left(3^n - 1\right) = 123 \Rightarrow a = \ldots\) Follow through on their value for \(n\).
A1: \(a = 1.5\)
(Corrected from the printed mark scheme: in the inverse-matrix line the printed scheme has \(a\) in place of 243 in the bottom right of the inverse matrix, and the equation as \(\dfrac{123 - 2\frac{a}{2}(243 - 1)}{243} = -2\).)
In this question you must show all stages of your working.
A college offers only three courses: Construction, Design and Hospitality.
Each student enrols on just one of these courses.
In 2019, there was a total of 1110 students at this college.
There were 370 more students enrolled on Construction than Hospitality.
In 2020 the number of students enrolled on
Construction increased by 1.25%
Design increased by 2.5%
Hospitality decreased by 2%
In 2020, the total number of students at the college increased by 0.27% to 2 significant figures.
(a)
(i) Define, for each course, a variable for the number of students enrolled on that course in 2019.
(ii) Using your variables from part (a)(i), write down three equations that model this situation. (4)
(b) By forming and solving a matrix equation, determine how many students were enrolled on each of the three courses in 2019. (4)
Mark scheme (a)
Scheme
Marks
AO
(i) \(x\) / \(C\) = number of Construction students \(y\) / \(D\) = number of Design students \(z\) / \(H\) = number of Hospitality students
B1
3.3
(ii) The increase in number of students in 2020 \(1110 \times 0.0027\{= 2.997 \approx 3\}\) Or The number of students in 2020 \(1110 \times 1.0027 = \{1112.997 \approx 1113\}\)
M1
1.1b
\(x + y + z = 1110 \qquad C + D + H = 1110\) \(x - z = 370\) o.e. \(\qquad C - H = 370\) o.e. \(0.0125C + 0.025D - 0.02H = 3\) or 2.997 o.e \(\quad 1.0125C + 1.025D + 0.98H = 1113\) or 1112.997 o.e. \(0.0125x + 0.025y - 0.02z = 3\) or 2.997 o.e \(\quad 1.0125x + 1.025y + 0.98z = 1113\) or 1112.997 o.e.
M1 A1
3.3 1.1b
(4)
Notes
Mark (i) and (ii) together
(i) B1: Defines 3 variables, minimum e.g. construction = \(C\), Design = \(D\), Hospitality = \(H\). This may be seen in text of the question, abbreviations may be used
(ii) M1: Finds either the increase or the number of students in 2020. This may be implied by any equation which equals 1113 or 1112.997. If students use 1100 instead of 1110 this is slip and we can award this mark.
M1: Attempts to use the model to set up at least 2 equations
A1: All 3 simplified equations correct (decimals or fractions), one for each different piece of information. Award with mark even if B0 is scored and it is clear what the variables used stand for. Ignore any additional equations even if incorrect. As soon as 3 correct equations are seen you may award this mark.
Alternative approach (i) B1: Construction = \(H + 370\), Design = \(D\), Hospitality = \(H\) (ii) M1M1A1: \(H + 370 + D + H = 1110\) o.e \(\quad C = H + 370 \quad 1.0125(H + 370) + 1.025D + 0.98H = 1113\) or 1112.997 o.e. they do not need to be simplified
Special Case: Forming an equation in one variable (a)(i) B1: Hospitality = \(x\), Construction = \(x + 370\), Design = \(740 - 2x\) (ii) M1M1A1: \(1.0125(x + 370) + 1.025(740 - 2x) + 0.98x = 1113\) or 1112.997
(a)(i) B1: Hospitality = \(x - 370\), Construction = \(x\), Design = \(1480 - 2x\) (ii) M1M1A1: \(1.0125(x) + 1.025(1480 - 2x) + 0.98(x - 370) = 1113\) or 1112.997
(b) M0A0M0A0: They have an equation and are not forming and solving a matrix equation
So in 2019, 720 students studied Construction, 40 students studied Design and 350 students studied Hospitality
A1
3.2a
(4)
(8 marks)
Notes
This is M1 M1 A1 A1 on ePen but is marked M1A1M1A1
M1: Uses their equation in part(a) to set up a matrix equation of the form \(\begin{pmatrix}\ldots & \ldots & \ldots\\ \ldots & \ldots & \ldots\\ \ldots & \ldots & \ldots\end{pmatrix}\begin{pmatrix}C\\ D\\ H\end{pmatrix} = \begin{pmatrix}\ldots\\ \ldots\\ \ldots\end{pmatrix}\), where “…” are numerical values.
A1ft: Correct matrix equation for their equations
dM1: Dependent on previous method mark. Writes \(\left(\text{their } \mathbf{A}\right)^{-1}\begin{pmatrix}1110\\ \text{their ``370''}\\ \text{their ``3''}\end{pmatrix}\) and obtains at least one value of \(C\), \(D\) or \(H\). The inverse matrix need not be found, writing \(\mathbf{A}^{-1}\begin{pmatrix}1110\\ 370\\ \text{their ``3''}\end{pmatrix} = \ldots\) is sufficient. A correct matrix equation followed by correct values implies this mark. Condone \(\begin{pmatrix}1110\\ \text{their ``370''}\\ \text{their ``3''}\end{pmatrix}\mathbf{A}^{-1} = \ldots\) as long as they reach some values. The values imply the correct method
A1: Interprets the answer in the context of the question, minimum is \(C = 720\), \(D = 40\), \(H = 350\) with their variables. Condone the variable not been defined for this mark if it is clear which variable belong to what course.
Note: they must be using a matrix equation to solve the equation to score any marks.
Alternative approach For example Equations simplifies to \(C - H = 370\), \(D + 2H = 740\) and \(1.025D + 1.9925H = 738.375\) which leads to \(\begin{pmatrix}0 & 1 & 2\\ 1 & 0 & -1\\ 0 & 1.025 & 1.9925\end{pmatrix}\begin{pmatrix}C\\ D\\ H\end{pmatrix} = \begin{pmatrix}740\\ 370\\ 738.375\end{pmatrix}\) then \(\begin{pmatrix}C\\ D\\ H\end{pmatrix} =\) \(\begin{pmatrix}17.826 & 1 & -17.3913\\ -34.6521 & 0 & 34.7826\\ 17.826 & 0 & -17.3913\end{pmatrix}\begin{pmatrix}740\\ 370\\ 738.375\end{pmatrix} = \begin{pmatrix}720\\ 40\\ 350\end{pmatrix}\)
Note: A 2 x 2 matrix is fine if it is appropriate for their equation.
Given that \(\mathbf{I}\) is the \(3 \times 3\) identity matrix,
(a)
(i) show that there is an integer \(k\) for which\[\mathbf{AB} - 3\mathbf{C} + k\mathbf{I} = \mathbf{0}\]stating the value of \(k\)
(ii) explain why there can be no constant \(m\) such that\[\mathbf{BA} - 3\mathbf{C} + m\mathbf{I} = \mathbf{0}\]
(4)
(b)
(i) Show how the matrix \(\mathbf{C}\) can be used to solve the simultaneous equations\[\begin{aligned}-5x + 2y + z &= -14\\ 4x + 3y + 8z &= 3\\ -6x + 11y + 2z &= 7\end{aligned}\]
(ii) Hence use your calculator to solve these equations.
finds matrix 3C and comments that they have different dimensions / can’t be done
can’t subtract matrices of different sizes
3C or C is a 3×3 matrix
BA needs to be a 3×3 matrix
B1
2.4
(4)
Notes
(a)(i) M1: Attempts to find AB. Usually this will be done on calculator so answer implies the method. If answer is incorrect allow for at least 6 correct entries or calculations shown. This mark can be implied by a correct matrix for \(\mathbf{AB} - 3\mathbf{C}\) gives the first M1
M1: Uses their AB and 3C matrices to find a multiple I and states a value for \(k\)
A1: Correct proof with \(k = -24\) seen explicitly (may be in equation).
Minimum working required is \(\mathbf{AB} - 3\mathbf{C} = \begin{pmatrix}24 & 0 & 0\\ 0 & 24 & 0\\ 0 & 0 & 24\end{pmatrix}\) gets M1 then states a value for \(k\) M1 then \(k = -24\) gets A1
Special case: If minimum working required is not seen and just \(k = -24\) stated then M1 M0 A0 as they have not shown that the value of \(k\) works.
(ii) B1: Correct explanation referring to the dimensions of BA and C (or 3C) and that they do not match in the equation. They can find both these matrices and then comment they cannot be subtracted.
So solution is \(x = \dfrac{7}{2},\ y = 3,\ z = -\dfrac{5}{2}\) or \((3.5,\ 3,\ -2.5)\)
A1
1.1b
(3)
(7 marks)
Notes
(b) Mark (i) and (ii) altogether
M1: States or implies use of the correct method of using the inverse matrix.
M1: Carries out the process of multiplying after finding the inverse. May find inverse long hand first. Finding the inverse matrix then writes down an answer gains M1.
Note: There is no need to find the inverse matrix. If the inverse matrix is not stated just answers written down then two out of the three correct ordinates imply the M1.
A1: Correct solution. Must be clear that \(x = \dfrac{7}{2},\ y = 3,\ z = -\dfrac{5}{2}\) allow \(\begin{pmatrix}x\\ y\\ z\end{pmatrix} = \begin{pmatrix}3.5\\ 3\\ -2.5\end{pmatrix}\)
Note: If they solve using simultaneous equations only this is M0 M0 A0 If there is no reference to the inverse matrix and correct answers stated this is M0 M0 A0
(i) \(\mathbf{A}\) is a 2 by 2 matrix and \(\mathbf{B}\) is a 2 by 3 matrix. Giving a reason for your answer, explain whether it is possible to evaluate
(a) \(\mathbf{AB}\)
(b) \(\mathbf{A} + \mathbf{B}\) (2)
(ii) Given that\[\begin{pmatrix}-5 & 3 & 1\\ a & 0 & 0\\ b & a & b\end{pmatrix}\begin{pmatrix}0 & 5 & 0\\ 2 & 12 & -1\\ -1 & -11 & 3\end{pmatrix} = \lambda\mathbf{I}\]where \(a\), \(b\) and \(\lambda\) are constants,
(a) determine
the value of \(\lambda\)
the value of \(a\)
the value of \(b\)
(b) Hence deduce the inverse of the matrix \(\begin{pmatrix}-5 & 3 & 1\\ a & 0 & 0\\ b & a & b\end{pmatrix}\) (3)
(iii) Given that\[\mathbf{M} = \begin{pmatrix}1 & 1 & 1\\ 0 & \sin\theta & \cos\theta\\ 0 & \cos 2\theta & \sin 2\theta\end{pmatrix} \qquad \text{where } 0 \leqslant \theta \lt \pi\]determine the values of \(\theta\) for which the matrix \(\mathbf{M}\) is singular. (4)
Mark scheme (i)
Scheme
Marks
AO
(a) It is possible as the number of columns of matrix A matches the number of rows of matrix B.
B1
2.4
(b) It is not possible as matrix A and matrix B have different dimensions o.e. different number of columns
B1
2.4
(2)
Notes
(a) B1: Comments that the number of columns of matrix A (2) equals the number of rows of matrix B (2) therefore it is possible. Accept other terminology that is clear in intent e.g. “length of A” and “height of B”
(b) B1: Comments that matrix A and matrix B have different dimensions therefore it is not possible.
(a) B1: Deduces the correct value for \(\lambda = 5\)
B1: Deduces the correct values for \(a\) and \(b\)
(b) B1ft: Identifies and applies a correct method find the inverse matrix. May multiply from the given equation, in which case follow through on their value of lambda. Alternatively, award for a correct matrix found by calculator or long hand having found \(a\) and \(b\) and using these values in the matrix.
Mark scheme (iii)
Scheme
Marks
AO
A complete method to find the determinant of the matrix and set equal to zero.
Uses compound angle formula to achieve \(\cos 3\theta = 0\) leading to \(\theta = \ldots\) or use of \(\sin 2\theta = 2\sin\theta\cos\theta\) and \(\cos 2\theta = 1 - 2\sin^2\theta\) (e.g. to achieve \(\cos\theta\left(4\sin^2\theta - 1\right) = 0\)) leading to \(\theta = \ldots\) or use of \(\sin 2\theta = 2\sin\theta\cos\theta\) and \(\cos 2\theta = 2\cos^2\theta - 1\) (e.g. to achieve \(4\cos^3\theta - 3\cos\theta = 0\)) leading to \(\theta = \ldots\)
The matrix \(\mathbf{A}\) represents the linear transformation \(M\).
Prove that, for the linear transformation \(M\), there are no invariant lines.
(5)
Mark scheme
Scheme
Marks
AO
\(\begin{pmatrix} 4 & -2 \\ 5 & 3 \end{pmatrix}\begin{pmatrix} x \\ mx + c \end{pmatrix} = \begin{pmatrix} X \\ mX + c \end{pmatrix}\) leading to an equation in \(x\), \(m\), \(c\) and \(X\)
M1
3.1a
\(4x - 2(mx + c) = X\) and \(5x + 3(mx + c) = mX + c\)
A1
1.1b
\(5x + 3(mx + c) = m\left(4x - 2(mx + c)\right) + c\) leading to \(5 + 3m = 4m - 2m^2\) \(\quad\left(3c = -2mc + c\right)\)
M1
2.1
\(2m^2 - m + 5 = 0 \Rightarrow b^2 - 4ac = (-1)^2 - 4(2)(5) = \ldots\) or Solves \(3c = -2mc + c \Rightarrow m = \ldots\)
dM1
1.1b
Correct expression for the discriminant \(= \{-39\} \lt 0\) therefore there are no invariant lines. or \(m = -1\) and shows a contradiction in \(5 + 3m = 4m - 2m^2\) therefore there are no invariant lines.
A1
2.4
(5)
Alternative
Scheme
Marks
AO
\(\begin{pmatrix} 4 & -2 \\ 5 & 3 \end{pmatrix}\begin{pmatrix} x \\ mx \end{pmatrix} = \begin{pmatrix} X \\ mX \end{pmatrix}\) leading to an equation in \(x\), \(m\) and \(X\)
M1
3.1a
\(4x - 2(mx) = X\) and \(5x + 3(mx) = mX\)
A1
1.1b
\(5x + 3(mx) = m\left(4x - 2(mx)\right)\) leading to \(5 + 3m = 4m - 2m^2\)
Correct expression for the discriminant \(= \{-39\} \lt 0\) therefore there are no invariant lines that pass through the origin / no invariant lines.
A1
2.4
(5)
(5 marks)
Notes
M1: Sets up a matrix equation in an attempt to find a fixed line and extract at least one equation. A1: Correct equations. M1: Eliminates \(X\) from the simultaneous equations and equates the coefficients of \(x\) leading to a quadratic equation in terms of \(m\). dM1: Dependent on the previous method, finds the value of the discriminant, this can be seen in an attempt to solve the quadratic using the formula. Alternatively solves \(3c = -2mc + c\) and finds a value for \(m\). Note: If the quadratic equation in \(m\) is solved on a calculator and complex roots given this is M0 as they are not showing why there are no real roots. A1: Correct expression for the discriminant, states \(\lt 0\) and draws the required conclusion. Alternatively, correct value for \(m\), shows a contradiction in \(5 + 3m = 4m - 2m^2\) and draws the required conclusion.
Alternative M1: Sets up a matrix equation in an attempt to find a fixed line and extract at least one equation. A1: Correct equations. M1: Eliminates \(X\) from the simultaneous equations and equates the coefficients of \(x\) leading to a quadratic equation in terms of \(m\). dM1: Dependent on the previous method, finds the value of the discriminant. A1: Correct expression for the discriminant, states \(\lt 0\) and draws the required conclusion.
M1: A full method to find \(k\) such as attempting the square root of the determinant of \(\mathbf{M}\). It is immediately deducible so the method may be implied by \(k = 8\).
A1: \(k = 8\)
M1: A full method to find a value of \(\theta\) using their \(k\), no need to justify quadrant. Only one equation needed for this mark. Allow if a radians answer is given. May be implied by a correct angle.
M1: Multiplies the correct matrix representing transformation \(Q\) by the matrix representing transformation \(P\) and sets equal to matrix \(\mathbf{M}\). Allow for the matrices either way round as the transformations commute. No need to see the identity matrix, just multiplying through by \(k\) is sufficient.
A1: Both correct equations. Note that if a correct value of \(k\) is found, this A is scored under Way 1.
M1: Solves their simultaneous equations to find a value for \(\theta\) (or \(k\))
A1: \(\theta = 120^\circ\) and \(k = 8\)
Mark scheme (b)
Scheme
Marks
AO
Area of \(S^{\prime}\) = area of \(S \times k^2\) (The area of the square \(S = 2a^2\))
M1
1.1b
Area of \(S^{\prime} = 128a^2\)
A1ft
2.2a
(2)
(6 marks)
Notes
M1: Complete method to find the area of \(S^{\prime}\): \(\text{``}\text{their } k^2\text{''} \times \text{``}\text{their } 2a^2\text{''}\). Must be an attempt at the area of \(S\) but it need not be correct.
A1ft: Deduces the correct area for \(S^{\prime}\), follow through their value of \(k\)
Given that the matrix \(\mathbf{A}\) is self-inverse,
(a) determine the value of \(b\) and the possible values for \(a\). (5)
The matrix \(\mathbf{A}\) represents a linear transformation \(M\).
Using the smaller value of \(a\) from part (a),
(b) show that the invariant points of the linear transformation \(M\) form a line, stating the equation of this line. (3)
(ii) \[\mathbf{P} = \begin{pmatrix}p & 2p\\ -1 & 3p\end{pmatrix}\]
where \(p\) is a positive constant.
The matrix \(\mathbf{P}\) represents a linear transformation \(U\). The triangle \(T\) has vertices at the points with coordinates (1, 2), (3, 2) and (2, 5). The area of the image of \(T\) under the linear transformation \(U\) is 15
(a) Determine the value of \(p\). (4)
The transformation \(V\) consists of a stretch scale factor 3 parallel to the \(x\)-axis with the \(y\)-axis invariant followed by a stretch scale factor \(-2\) parallel to the \(y\)-axis with the \(x\)-axis invariant. The transformation \(V\) is represented by the matrix \(\mathbf{Q}\).
(b) Write down the matrix \(\mathbf{Q}\). (2)
Given that \(U\) followed by \(V\) is the transformation \(W\), which is represented by the matrix \(\mathbf{R}\),
(c) find the matrix \(\mathbf{R}\). (2)
Mark scheme (i)(a)
Scheme
Marks
AO
Multiplies the matrix \(\mathbf{A}\) by itself and sets equal to \(\mathbf{I}\) to form one equation in \(a\) only and another equation involving both \(a\) and \(b\). \(\begin{pmatrix}2 & a\\ a - 4 & b\end{pmatrix}\begin{pmatrix}2 & a\\ a - 4 & b\end{pmatrix} = \begin{pmatrix}1 & 0\\ 0 & 1\end{pmatrix} \Rightarrow 4 + a(a - 4) = 1\) and either \(2a + ab = 0\) or \(2(a - 4) + b(a - 4) = 0\) or \(a(a - 4) + b^2 = 1\)
M1
3.1a
Solves a 3TQ involving only the constant \(a\). This could come after a value of \(b\) is found and this value substituted into an equation involving both \(a\) and \(b\) \(a^2 - 4a + 3 = 0 \Rightarrow (a - 3)(a - 1) = 0 \Rightarrow a = \ldots\)
dM1
1.1b
\(a = 1, a = 3\)
A1
1.1b
Substitutes a value for \(a\) into an equation involving both \(a\) and \(b\) and solves for \(b\). e.g. \(2(1) + (1)b \Rightarrow b = \ldots\) \(2(1 - 4) + b(1 - 4) = 0 \Rightarrow b = \ldots\) \((1)(1 - 4) + b^2 = 1 \Rightarrow b = \ldots\) Alternatively uses \(2a + ab = 0\) \(a(2 + b) = 0\) As \(a \neq 0\quad 2 + b = 0 \Rightarrow b = \ldots\)
dM1
1.1b
\(b = -2\)
A1
1.1b
(5)
Notes
(Corrected from the printed mark scheme: the printed example is \(2(1 - 4)b + (1 - 4) = 0\); from \(2(a - 4) + b(a - 4) = 0\) with \(a = 1\) it is \(2(1 - 4) + b(1 - 4) = 0\).)
M1: Forming two equations, one involving \(a\) only and one involving \(a\) and \(b\)
dM1: Dependent on previous mark, solves a 3TQ involving \(a\)
A1: Correct values for \(a\)
dM1: Dependent on first method mark Substitutes one of their values of \(a\) into an equation involving \(a\) and \(b\) and solve to find a value for \(b\). Alternatively factorises either \(2a + ab = 0\) and uses \(a \neq 0\) to find a value for \(b\).
A1: Correct value for \(b\)
Alternative (i)(a)
Scheme
Marks
AO
Finds \(\mathbf{A}^{-1}\) in terms of \(a\) and \(b\), sets equal to \(\mathbf{A}\) and attempts to find at least two different equations. Allow a single sign slip\[\frac{1}{2b - a(a - 4)}\begin{pmatrix}b & -a\\ -(a - 4) & 2\end{pmatrix} = \begin{pmatrix}2 & a\\ a - 4 & b\end{pmatrix}\]One equation from \(\dfrac{b}{2b - a(a - 4)} = 2,\ \dfrac{2}{2b - a(a - 4)} = b\) One equation from \(\dfrac{-a}{2b - a(a - 4)} = a,\ \dfrac{-(a - 4)}{2b - a(a - 4)} = a - 4\)
M1
3.1a
Uses their value of \(b\) and their value of the determinant to form and solve a 3TQ involving only the constant \(a\) \(a^2 - 4a + 3 = 0 \Rightarrow (a - 3)(a - 1) = 0 \Rightarrow a = \ldots\) or Eliminates \(b\) from their equations and solve a 3TQ involving only the constant \(a\) \(a^2 - 4a + 3 = 0 \Rightarrow (a - 3)(a - 1) = 0 \Rightarrow a = \ldots\)
dM1
1.1b
\(a = 1, a = 3\)
A1
1.1b
\(\dfrac{-a}{2b - a(a - 4)} = a \Rightarrow 2b - a(a - 4) = -1 \Rightarrow \dfrac{b}{-1} = 2\) Or \(\dfrac{-(a - 4)}{2b - a(a - 4)} = a - 4 \Rightarrow 2b - a(a - 4) = -1 \Rightarrow \dfrac{2}{-1} = b\) or Substitutes a value for \(a\) into an equation to find a value for \(b\)
dM1
1.1b
\(b = -2\)
A1
1.1b
(5)
M1: Finds \(\mathbf{A}^{-1}\) and sets equal to \(\mathbf{A}\) and forms two different equations
dM1: Dependent on previous mark. Eliminates \(b\) from their equations and solves a 3TQ involving only the constant \(a\). Alternatively if the value of \(b\) is found first substitutes their value for \(b\) into their determinant = –1 to form and solve a 3TQ for \(a\)
A1: Correct value for \(a\)
dM1: Dependent on first method mark. Substitutes a value for \(a\) into an equation to find a value for \(b\). Alternatively uses one equation to find the determinant = –1 and uses this to find a value of \(b\).
A1: Correct values for \(b\)
Mark scheme (i)(b)
Scheme
Marks
AO
Uses their smallest value of \(a\) and their value for \(b\) to form two equations \(\begin{pmatrix}2 & \text{'}a\text{'}\\ \text{'}a - 4\text{'} & \text{'}b\text{'}\end{pmatrix}\begin{pmatrix}x\\ y\end{pmatrix} = \begin{pmatrix}x\\ y\end{pmatrix} \Rightarrow 2x + ay = x\) and \((a - 4)x + by = y\) \(\begin{pmatrix}2 & 1\\ -3 & -2\end{pmatrix}\begin{pmatrix}x\\ y\end{pmatrix} = \begin{pmatrix}x\\ y\end{pmatrix} \Rightarrow 2x + y = x\) and \(-3x - 2y = y\)
M1
3.1a
\(2x + y = x \Rightarrow x + y = 0\) o.e. and \(-3x - 2y = y \Rightarrow x + y = 0\) o.e.
M1
1.1b
\(x + y = 0\) o.e.
A1
2.1
(3)
Notes
M1: Extracts simultaneous equations using their matrix A with their smaller value of \(a\).
M1: Gathers terms from their two equations.
A1: Achieves the correct equations and deduces the correct line. Accept equivalent equations as long as both have been shown to be the same.
Mark scheme (ii)(a)
Scheme
Marks
AO
Area of the triangle \(T = 3\)
B1
1.1b
Complete method to find a value for \(p\). Need to see an attempt at the determinant and setting equal to 15 divided by their area of \(T\). The resulting 3TQ needs to be solved to find a value of \(p\). Determinant \(3p \times p - (-1) \times 2p = \dfrac{15}{\text{‘their area’}} \Rightarrow p = \ldots\)
M1
3.1a
\(3p^2 + 2p - 5\,(= 0)\)
A1
1.1b
\(p = 1\) must reject \(p = -\dfrac{5}{3}\)
A1
1.1b
(4)
Notes
B1: Area of the triangle \(T = 3\)
M1: Full method. Finds the determinant, sets equal to 15/their area and solves the resulting 3TQ
\[\mathbf{M} = \begin{pmatrix}k & 5 & 7\\ 1 & 1 & 1\\ 2 & 1 & -1\end{pmatrix} \qquad \text{where } k \text{ is a constant}\]
(a) Given that \(k \neq 4\), find, in terms of \(k\), the inverse of the matrix \(\mathbf{M}\). (4)
(b) Find, in terms of \(p\), the coordinates of the point where the following planes intersect.\[\begin{aligned} 2x + 5y + 7z &= 1\\ x + y + z &= p\\ 2x + y - z &= 2 \end{aligned}\] (3)
(c)
(i) Find the value of \(q\) for which the following planes intersect in a straight line.\[\begin{aligned} 4x + 5y + 7z &= 1\\ x + y + z &= q\\ 2x + y - z &= 2 \end{aligned}\]
(ii) For this value of \(q\), determine a vector equation for the line of intersection.
(a) M1: Correct method to find the determinant. Condone one sign slip M1: A correct first step in obtaining the inverse. Could be the matrix of minors or cofactors. Condone sign slips as long as the intention is clear. M1: Fully correct method to obtain the inverse. Attempts matrix of minors, cofactors, transposes and 1/determinant A1: Correct matrix
Mark scheme (b)
Scheme
Marks
AO
\(\mathbf{M}^{-1} = \dfrac{1}{4}\begin{pmatrix}-2 & 12 & -2\\ 3 & -16 & 5\\ -1 & 8 & -3\end{pmatrix} \Rightarrow \begin{pmatrix}x\\ y\\ z\end{pmatrix} = \mathbf{M}^{-1}\begin{pmatrix}1\\ p\\ 2\end{pmatrix}\) Solve the equations simultaneously to achieve values for \(x\), \(y\) and \(z\) \(y + 3z = 2p - 2\) and \(4y + 8z = -1 \Rightarrow x = \ldots,\ y = \ldots,\ z = \ldots\)
(b) M1: A complete strategy for solving the given equations e.g. multiplies the given coordinates by their inverse or solves simultaneously to achieve values for \(x\), \(y\) and \(z\) A1ft: Correct calculation on their inverse matrix (unsimplified) or at least on correct value if solving simultaneously A1: Correct coordinates
Mark scheme (c)
(c)(i)
Scheme
Marks
AO
For consistency: E.g. eliminates \(z\) to find two equations from \(3x + 2y = q + 2\) \(3x + 2y = 7q - 1\) \(18x + 12y = 15\)
For consistency: E.g. eliminates \(x\) to find two equations from \(y + 3z = 1 - 4q\) \(3y + 9z = -3\) \(y + 3z = 2q - 2\)
For consistency: E.g. eliminates \(y\) to find two equations from \(x - 2z = 2 - q\) \(-x + 2z = 1 - 5q\) \(-6x + 12z = -9\)
e.g. \(-3 = 3(1 - 4q)\) \(\Rightarrow q = \ldots\)
e.g. \(-9 = 6(1 - 5q)\) \(\Rightarrow q = \ldots\)
M1
1.1b
\(q = \dfrac{1}{2}\)
A1
1.1b
Alternative (c)(i)
Scheme
Marks
AO
Equating coefficients leading to two out of three equations and solves to find values for a and b \(4a + b = 2,\ 5a + b = 1,\ 7a + b = -1\) \(\{a = -1,\ b = 6\}\)
M1
3.1a
Forms the fourth equation involving \(q\) \(a + bq = 2\) and substitutes in the values of \(a\) and \(b\) to finds a value for \(q\)
M1
1.1b
\(q = \dfrac{1}{2}\)
A1
1.1b
Alternative (c)(i)
Scheme
Marks
AO
Finds a coordinate of intersection of the planes \(4x + 5y + 7z = 1\) and \(2x + y - z = 2\) e.g let \(z = 0 \Rightarrow 4x + 5y = 1\) and \(2x + y = 2 \Rightarrow y = -1,\ x = 1.5\)
M1
3.1a
Substitutes the values for \(x\), \(y\) and \(z\) into \(x + y + z = q\) to reach a value for \(q\)
M1
1.1b
\(q = \dfrac{1}{2}\)
A1
1.1b
(c)(ii)
Scheme
Marks
AO
For example: \(x = \lambda \Rightarrow 3\lambda + 2y = \dfrac{5}{2},\ \lambda - 2z = \dfrac{3}{2} \Rightarrow y = \mathrm{f}(\lambda), z = \mathrm{f}(\lambda)\) \(y = \lambda \Rightarrow 3x + 2\lambda = \dfrac{5}{2},\ \lambda + 3z = -1 \Rightarrow x = \mathrm{f}(\lambda), z = \mathrm{f}(\lambda)\) \(z = \lambda \Rightarrow 3y + 9\lambda = -3,\ -6x + 12\lambda = -9 \Rightarrow x = \mathrm{f}(\lambda), y = \mathrm{f}(\lambda)\)
M1
3.1a
Let \(x = \lambda\), \(\lambda = \dfrac{y - \frac{5}{4}}{-\frac{3}{2}} = \dfrac{z + \frac{3}{4}}{\frac{1}{2}}\) or \(y = \dfrac{5}{4} - \dfrac{3}{2}\lambda,\ z = -\dfrac{3}{4} + \dfrac{1}{2}\lambda\) Let \(y = \lambda\), \(\lambda = \dfrac{x - \frac{5}{6}}{-\frac{2}{3}} = \dfrac{z + \frac{1}{3}}{-\frac{1}{3}}\) or \(x = \dfrac{5}{6} - \dfrac{2}{3}\lambda,\ z = -\dfrac{1}{3} - \dfrac{1}{3}\lambda\) Let \(z = \lambda\), \(\lambda = \dfrac{x - \frac{3}{2}}{2} = \dfrac{y + 1}{-3}\) or \(x = \dfrac{3}{2} + 2\lambda,\ y = -1 - 3\lambda\)
Finds two different coordinates that lie on the line of intersection For example: setting \(x = 0 \Rightarrow \left(0, \dfrac{5}{4}, -\dfrac{3}{4}\right)\) setting \(y = 0 \Rightarrow \left(\dfrac{5}{6}, 0, -\dfrac{1}{3}\right)\) setting \(z = 0 \Rightarrow \left(\dfrac{3}{2}, -1, 0\right)\)
M1 A1
3.1a 1.1b
Finds the vector equation of the line passing through their two points
(c)(i) M1: Uses a correct strategy that will lead to establishing a value for \(q\). E.g. eliminating one of \(x\), \(y\) or \(z\) M1: Solves a suitable equation to obtain a value for \(q\) A1: Correct value
(c)(i) Alternative 1 M1: Equating coefficients leading to two out of three equations and solves to find values for a and b M1: Solves a suitable equation to obtain a value for \(q\) using their values for \(a\) and \(b\)
(c)(i) Alternative 2 M1: Finds a coordinate of intersection of the planes \(4x + 5y + 7z = 1\) and \(2x + y - z = 2\) M1: Substitutes the values for \(x\), \(y\) and \(z\) into \(x + y + z = q\) to reach a value for \(q\) A1: Correct value
(ii) M1: Uses a correct strategy to obtain the Cartesian equation of the line or the general coordinates A1: Correct Cartesian equation or coordinates in terms of a parameter. M1: Uses their Cartesian equation to correctly extract the position and direction to form a vector equation for the required line A1: Correct equation (o.e.) look out for multiples of the direction vector
Alternative (ii) M1: Finds two different coordinates that lie on the line of intersection A1: Correct coordinates M1: Uses their coordinates to find the vector equation of the line that passes through them. A1: Correct equation (o.e.), look out for multiples of the direction vector. Must have \(\mathbf{r} = \ldots\)
Alternative (ii) outside spec M1: Finds the cross product between the normal vectors of two of the planes and a coordinate that lies on all three planes. If a coordinate is found in (i) it must be used in this part to award this mark. A1: Correct cross product M1: Uses the coordinate and the cross product to find the equation of the line A1: Correct equation (o.e.), look out for multiples of the direction vector. Must have \(\mathbf{r} = \ldots\)
(corrected from the printed mark scheme: in (c)(ii), \(\lambda + 3z = -1\) is printed as \(\lambda + 3z = 1\), and \(x = \dfrac{5}{6} - \dfrac{2}{3}\lambda\) is printed as \(x = \dfrac{5}{5} - \dfrac{2}{3}\lambda\))
(Note: the cross products in the “outside the spec” alternative are as printed. The correct values are \((4\mathbf{i} + 5\mathbf{j} + 7\mathbf{k}) \times (\mathbf{i} + \mathbf{j} + \mathbf{k}) = -2\mathbf{i} + 3\mathbf{j} - \mathbf{k}\), \((4\mathbf{i} + 5\mathbf{j} + 7\mathbf{k}) \times (2\mathbf{i} + \mathbf{j} - \mathbf{k}) = -12\mathbf{i} + 18\mathbf{j} - 6\mathbf{k}\) and \((\mathbf{i} + \mathbf{j} + \mathbf{k}) \times (2\mathbf{i} + \mathbf{j} - \mathbf{k}) = -2\mathbf{i} + 3\mathbf{j} - \mathbf{k}\), each a multiple of \(2\mathbf{i} - 3\mathbf{j} + \mathbf{k}\).)
Solves det = 0 \(\Rightarrow 2k^2 + 12k - 32 = 0\) or \(k^2 + 6k - 16 = 0\) To achieve \(k = 2\) (\(k = -8\) must be rejected)
A1
1.1b
(2)
Notes
M1: Finds the determinant of the matrix corresponding to the system of equations.
A1: Sets determinant = 0 and solves their 3TQ to achieve \(k = 2\) (\(k = -8\) must be rejected)
Special case
Scheme
Marks
AO
\[\begin{vmatrix}2 & 3 & -1\\ 3 & -1 & 1\\ -16 & -2 & -2\end{vmatrix} = 2(2 + 2) - 3(-3 \times 2 + 16) - 1(-3 \times 2 - 16)\]Shows det = 0, therefore when \(k = 2\) there is no unique solution
M1 A0
2.1 1.1b
M1A0: Uses \(k = 2\) and finds the determinant of the matrix corresponding to the system of equations Shows that determinant = 0 and concludes that when \(k = 2\) there is no unique solution
Mark scheme (b)
Scheme
Marks
AO
Eliminates \(z\) to achieve two equations in \(x\) and \(y\) e.g.\[\begin{aligned}5x + 2y &= 1\\ -10x - 4y &= -2\\ 20x + 8y &= 4\end{aligned}\]or eliminates \(x\) to achieve two equations in \(y\) and \(z\) e.g.\[\begin{aligned}11y - 5z &= 13\\ 22y - 10z &= 26\\ -22y - 10z &= -26\end{aligned}\]or eliminates \(y\) to achieve two equations in \(x\) and \(z\) e.g.\[\begin{aligned}11x + 2z &= -3\\ 22x + 4z &= -6\\ -44x - 8z &= 12\end{aligned}\]
M1 A1
3.1a 1.1b
Must give a reason: e.g. Two equations are a linear multiple of each other e.g. shows they are the same equation therefore the equations are consistent.
A1
2.4
(3)
Notes
M1: A complete method eliminating one variable from the equations using two different pairs of equations. Condone if a different value of \(k\) is used
A1: Achieves two equations in the same two variables
A1: Must give a reason, shows that the equations are a linear multiple of each other therefore they are consistent.
Alternative
Scheme
Marks
AO
Eliminates two different variables to form two equations, should be one equation from two of the three sections in the main scheme. e.g \(5x + 2y = 1\) and \(11y - 5z = 13\) rearranges and substitutes in to one of the original equations in three variables. e.g. \(2x + 3\left(\dfrac{1 - 5x}{2}\right) - \left(\dfrac{-3 - 11x}{2}\right) = 3\)
Shows that the equations are a solution e.g. 3 = 3 therefore consistent
A1
2.4
(Note: the substitution shown uses \(5x + 2y = 1\) and \(11x + 2z = -3\).)
M1: A complete method eliminating one variable from the equations using two different pairs of equations. Substitutes these equations into one of the original equations in three variables.
A1: Achieves two correct equations in two different variables
A1: Shows that the equation works therefore they are consistent.
Mark scheme (c)
Scheme
Marks
AO
The three planes form a sheaf.
B1
2.2a
(1)
(6 marks)
Notes
B1: The three planes form a sheaf. They must have full marks in (b) to award this mark.
10. The population of chimpanzees in a particular country consists of juveniles and adults. Juvenile chimpanzees do not reproduce.
In a study, the numbers of juvenile and adult chimpanzees were estimated at the start of each year. A model for the population satisfies the matrix system
where \(a\) is a constant, and \(J_n\) and \(A_n\) are the respective numbers of juvenile and adult chimpanzees \(n\) years after the start of the study.
(a) Interpret the meaning of the constant \(a\) in the context of the model. (1)
At the start of the study, the total number of chimpanzees in the country was estimated to be 64 000
According to the model, after one year the number of juvenile chimpanzees is 15 360 and the number of adult chimpanzees is 43 008
(b)
(i) Find, in terms of \(a\)\[\begin{pmatrix}a & 0.15\\ 0.08 & 0.82\end{pmatrix}^{-1}\](3)
(ii) Hence, or otherwise, find the value of \(a\). (3)
(iii) Calculate the change in the number of juvenile chimpanzees in the first year of the study, according to this model. (2)
Given that the number of juvenile chimpanzees is known to be in decline in the country,
(c) comment on the short-term suitability of this model. (1)
A study of the population revealed that adult chimpanzees stop reproducing at the age of 40 years.
(d) Refine the matrix system for the model to reflect this information, giving a reason for your answer. (There is no need to estimate any unknown values for the refined model, but any known values should be made clear.)(2)
Mark scheme (a)
Scheme
Marks
AO
\(a\) represents the proportion of juvenile chimpanzees that (survive and) remain juvenile chimpanzees the next year.
B1
3.4
(1)
Notes
B1: Correct interpretation. Need not mention survival but must be clear it is the (proportion of) juveniles that remain as juveniles the next year (ie those that survive but don’t progress to adulthood). E.g. accept “(number of) juveniles who do not become adults” but do not accept “surviving juveniles”.
M1: Attempts the determinant in terms of \(a\). Allow miscopies for the attempt. Allow \(0.82a - 0.12\) as a slip.
M1: Attempts the form of the inverse, swapped leading diagonals and sign changed on both off diagonals. Allow miscopies of the numbers but the signs must be correct.
(Corrected from the printed mark scheme: the factor \(0.15 \times\) is missing in the printed expression \(a = \dfrac{15360 - (64000 - J_0)}{J_0}\).)
Notes
M1: Use the inverse matrix and attempts to find the initial juvenile and adult populations. (May have determinant 1 for this mark.) Alternatively, sets up simultaneous equations from the original system, \(15360 = aJ_0 + 0.15 \times A_0\) and \(43008 = 0.08 \times J_0 + 0.82 \times A_0\). Accept with \(J_n\) and \(A_n\) or other appropriate variables.
M1: Uses the sum of initial populations equals 64000 in an attempt to find \(a\). (May have determinant 1 for this mark.) If using alternative, use of e.g. \(A_0 = 64000 - J_0\) in second equation to find \(J_0\), followed by attempt to find \(a\). Award for an attempt to solve the equations, but don’t be too concerned with the algebraic process as long as they are attempting to use all three equations.
A1: Correct value, \(a = 0.6\) (or 0.60 or \(\frac{3}{5}\)).
Mark scheme (b)(iii)
Scheme
Marks
AO
Initial juvenile population \(= \dfrac{\text{“}6144\text{”}}{\text{“}0.48\text{”}} = 12800\)
M1
3.4
So change of 2560 juvenile chimpanzees
A1
1.1b
(2)
Notes
M1: Uses their \(a\) to find the value of \(J_0\). This mark may be gained for work done in (ii) if the alternative has been used but must have come from a correct method.
A1: Correct difference found, as long as there is no contradictory statement – so “decrease of 2560” is A0.
Mark scheme (c)
Scheme
Marks
AO
As the number of juveniles has increased, the model is not initially predicting a decline, so is not suitable in the short term. (Follow through their answer to (b) – but they must have made an attempt at it to find at least a value for \(J_0\))
B1ft
3.5a
(1)
Notes
B1ft: Comments that the change is an increase so does not fit the model. Follow through their answer to (b) as long as at least a value for \(J_0\) has been found. If a decrease has been found allow for commenting the model is suitable. If an answer is given to (b)(iii), follow through on whatever their answer is. If no answer has been given, but an initial population found, a comparison should be made between this value and 15360 with conclusion must be consistent with their answer for \(J_0\)
(Corrected from the printed mark scheme: the value to compare with is printed as 153600; it is 15360.)
Mark scheme (d)
Scheme
Marks
AO
Third category needs to be introduced for chimpanzees aged 40 and above, mature chimpanzees \(M_n\), and a matrix multiplication of increased dimension set up. Accept \(3 \times 3\), \(3 \times 2\) or \(2 \times 3\) matrices including all three categories in the column vector.
M1
3.5c
The corresponding matrix model will have the form\[\begin{pmatrix}J_{n+1}\\ A_{n+1}\\ M_{n+1}\end{pmatrix} = \begin{pmatrix}a & b & \underline{\mathbf{0}}\\ 0.08 & c & 0\\ 0 & d & e\end{pmatrix}\begin{pmatrix}J_n\\ A_n\\ M_n\end{pmatrix}\](The underlined zero must be correct but do not be concerned about any values used in the other entries.)
A1
3.3
(2)
(12 marks)
Notes
M1: Introduces a third category (may be Mature, Elderly or any suitable letter used) and sets up a matrix multiplication (the left hand side may be missing for this mark) with all three categories in the column vector. The dimension of the matrix should be 3 in at least either row or column, and there should be a \(3 \times 1\) vector.
A1: Sets up the new matrix equation, including both sides and making clear the zero (underlined) so that the correct progression that no new juveniles arise from the mature chimpanzees is clear. Overlook other values, though ideally the other two zeroes are shown too, to indicate mature chimpanzees do not regress to adulthood, and juveniles cannot proceed directly to mature chimpanzees.
\[\mathbf{M} = \begin{pmatrix}2 & -1 & 1\\ 3 & k & 4\\ 3 & 2 & -1\end{pmatrix} \qquad \text{where } k \text{ is a constant}\]
(a) Find the values of \(k\) for which the matrix \(\mathbf{M}\) has an inverse. (2)
(b) Find, in terms of \(p\), the coordinates of the point where the following planes intersect\[\begin{aligned}2x - y + z &= p\\ 3x - 6y + 4z &= 1\\ 3x + 2y - z &= 0\end{aligned}\] (5)
(c)
(i) Find the value of \(q\) for which the set of simultaneous equations\[\begin{aligned}2x - y + z &= 1\\ 3x - 5y + 4z &= q\\ 3x + 2y - z &= 0\end{aligned}\]can be solved.
(ii) For this value of \(q\), interpret the solution of the set of simultaneous equations geometrically. (4)
M1: Attempts determinant, equates to zero and attempts to solve for \(k\) in order to establish the restriction for \(k\). For the determinant, at least 2 of the 3 “elements” should be correct.
M1: A complete strategy for solving the given equations. Need to see an attempt at the inverse followed by a correct method for finding \(x\), \(y\) and \(z\)
B1: Correct inverse matrix
M1: Uses their inverse and attempts the multiplication with the correct vector
A1: Correct values for \(x\), \(y\) and \(z\) in any form
A1ft: Correct values given in coordinate form only. Follow through their \(x\), \(y\) and \(z\).
Alternative: Way 2
Scheme
Marks
AO
\(\begin{aligned}2x - y + z &= p\\ 3x - 6y + 4z &= 1\\ 3x + 2y - z &= 0\end{aligned} \Rightarrow \text{e.g. } \begin{aligned}8y - 5z &= -1\\ 9y - 5z &= 3p - 2\end{aligned} \Rightarrow y = \ldots\) \(\Rightarrow x = \ldots,\ z = \ldots\)
M1: A complete strategy for solving the given equations. Need to see an attempt at eliminating one variable followed by a correct method for finding \(x\), \(y\) and \(z\)
B1: One correct value
M1: Uses the equations to find values for the other 2 variables
A1: Correct values for \(x\), \(y\) and \(z\) in any form
A1ft: Correct values given in coordinate form only. Follow through their \(x\), \(y\) and \(z\).
Mark scheme (c)
Scheme
Marks
AO
(i) For consistency: E.g. \(5x + y = 4 - q\) and \(15x + 3y = q\)
M1
3.1a
\(4 - q = \dfrac{q}{3} \Rightarrow q = \ldots\)
M1
2.1
\(q = 3\)
A1
1.1b
Alternative for (c)(i): \(x = 1 \Rightarrow 2 - y + z = 1,\ 3 + 2y - z = 0 \Rightarrow y = \ldots,\ z = \ldots\) M1 for allocating a number to one variable and solves for the other 2 \(x = 1,\ y = -4,\ z = -5 \Rightarrow 3 + 20 - 20 = q\) M1 substitutes into the second equation and solves for \(q\) A1: \(q = 3\)
(ii) Three planes that intersect in a line Or Three planes that form a sheaf allow sheath!
B1
2.4
(4)
(11 marks)
Notes
(c)(i)
M1: Uses a correct strategy that will lead to establishing a value for \(q\). E.g. eliminating one of \(x\), \(y\) or \(z\)
M1: Solves a suitable equation to obtain a value for \(q\)
A1: Correct value
(ii)
B1: Describes the correct geometrical configuration.
Must include the two ideas of planes and meeting in a line or forming a sheaf with no contradictory statements.
(a) Show that the matrix \(\mathbf{M}\) is non-singular. (2)
The transformation \(T\) of the plane is represented by the matrix \(\mathbf{M}\). The triangle \(R\) is transformed to the triangle \(S\) by the transformation \(T\). Given that the area of \(S\) is 63 square units,
(b) find the area of \(R\). (2)
(c) Show that the line \(y = 2x\) is invariant under the transformation \(T\). (2)
Mark scheme (a)
Scheme
Marks
AO
\((\det(\mathbf{M}) =)\ (4)(-7) - (2)(-5)\)
M1
1.1a
\(\mathbf{M}\) is non-singular because \(\det(\mathbf{M}) = -18\) and so \(\det(\mathbf{M}) \ne 0\)
A1
2.4
(2)
Notes
M1: An attempt to find \(\det(\mathbf{M})\). Just the calculation is sufficient. Sight of \(-18\) implies this mark, which may be embedded in an attempt at the inverse.
A1: \(\det(\mathbf{M}) = -18\) and reference to zero, e.g. \(-18 \ne 0\) and conclusion. The conclusion may precede finding the determinant (e.g. “Non-singular if \(\det(\mathbf{M}) \ne 0\), \(\det(\mathbf{M}) = -18 \ne 0\)” is sufficient or accept “Non-singular if \(\det(\mathbf{M}) \ne 0\), \(\det(\mathbf{M}) = -18\), therefore non-singular” or some other indication of conclusion.) Need not mention “\(\det(\mathbf{M})\)” to gain both marks here, a correct calculation, statement \(-18 \ne 0\), and conclusion hence \(\mathbf{M}\) is non-singular can gain M1A1.
Mark scheme (b)
Scheme
Marks
AO
Area \(R = \dfrac{\text{Area } S}{(\pm)|\det \mathbf{M}|} = \ldots\)
M1: Recalls determinant is needed for area scale factor by dividing 63 by \(\pm\)their determinant.
A1ft: \(\dfrac{7}{2}\) or follow through \(\dfrac{63}{|\text{their det}|}\). Must be positive and should be simplified to single fraction or exact decimal. (Allow if made positive following division by a negative determinant.)
\(= \begin{pmatrix}-6x\\ -12x\end{pmatrix}\) and so all points on \(y = 2x\) map to points on \(y = 2x\), hence the line is invariant. OR \(= -6\begin{pmatrix}x\\ 2x\end{pmatrix}\) hence \(y = 2x\) is invariant.
A1
2.1
(2)
(6 marks)
Notes
M1: Attempts the matrix multiplication shown or with equivalent, e.g. \(\begin{pmatrix}\frac{1}{2}y\\ y\end{pmatrix}\). May use \(\begin{pmatrix}x\\ y\end{pmatrix}\) and substitute \(y = 2x\) later and this is fine for the method.
A1: Correct multiplication and working leading to conclusion that the line is invariant. If the \(-6\) is not extracted, they must make reference to image points being on line \(y = 2x\). If the \(-6\) is extracted to show it is a multiple of \(\begin{pmatrix}x\\ 2x\end{pmatrix}\) followed by a conclusion “invariant” as minimum.
\(= -\dfrac{1}{18}\begin{pmatrix}3x\\ 6x\end{pmatrix}\left(= -\dfrac{1}{6}\begin{pmatrix}x\\ 2x\end{pmatrix}\right) \Rightarrow b = 2a\) so points on line \(y = 2x\) map to points on \(y = 2x\), hence it is invariant.
A1
2.1
Marks as per main scheme.
Alternative (Alt 2)
Scheme
Marks
AO
(Since linear transformations map straight lines to straight lines…) E.g. \((1, 2)\) is on line \(y = 2x\), and \(\begin{pmatrix}4 & -5\\ 2 & -7\end{pmatrix}\begin{pmatrix}1\\ 2\end{pmatrix} = \begin{pmatrix}4 - 10\\ 2 - 14\end{pmatrix}\)
M1
1.1b
\(= \begin{pmatrix}-6\\ -12\end{pmatrix}\), which is also on the line \(y = 2x\), hence as \((0, 0)\) and \((1, 2)\) both map to points on \(y = 2x\) (and transformation is linear) then \(y = 2x\) is invariant.
A1
2.1
M1: Identifies a point on the line \(y = 2x\) and finds its image under \(T\). If \((0, 0)\) is used there must be a clear statement it is because this is on the line, but for other points accept with any line on \(y = 2x\) without statement.
A1: Shows the image and another point, which may be \((0, 0)\), on \(y = 2x\) both map to points on \(y = 2x\), concludes line is invariant. Need not reference transformation being linear for either mark here.
\((5m - 8 \ne 0 \Rightarrow c = 0)\) Hence \(m = 2\) gives an invariant line (with \(c = 0\)), so \(y = 2x\) is invariant.
A1
1.1b
M1: Attempts to find the equation of a general invariant line, or general invariant line through the origin (so may have \(c = 0\) throughout). To gain the method mark they must progress from finding the simultaneous equations to forming a quadratic in \(m\) and solving to a value of \(m\).
A1: Correct quadratic in \(m\) found, with \(m = 2\) as solution (ignore the other) and deduction that hence \(y = 2x\) is an invariant line. Ignore errors in the \((5m - 8)\) here as \(c = 0\) is always a possible solution. No need to see \(c = 0\) derived.
If true for \(n = k\) then true for \(n = k + 1\), true for \(n = 1\) so true for all (positive integers) \(n\) (Allow “for all values”)
A1
2.4
(6)
Notes
B1: Shows that the result holds for \(n = 1\). Must see substitution into the rhs. The minimum would be: \(\begin{pmatrix}4 + 1 & -8\\ 2 & 1 - 4\end{pmatrix} = \begin{pmatrix}5 & -8\\ 2 & -3\end{pmatrix}\).
M1: Makes a statement that assumes the result is true for some value of \(n\) (Assume (true for) \(n = k\) is sufficient – note that this may be recovered in their conclusion if they say e.g. if true for \(n = k\) then … etc.)
M1: Sets up a correct multiplication statement either way round
A1: Achieves a correct un-simplified matrix
A1: Reaches a correct simplified matrix with no errors and the correct un-simplified matrix seen previously. Note that the simplified result may be proved by equivalence.
A1: Correct conclusion. This mark is dependent on all previous marks apart from the B mark. It is gained by conveying the ideas of all four underlined points either at the end of their solution or as a narrative in their solution.
Mark scheme (ii)
Way 1: \(\mathrm{f}(k + 1) - \mathrm{f}(k)\)
Scheme
Marks
AO
When \(n = 1\), \(4^{n+1} + 5^{2n-1} = 16 + 5 = 21\) so the statement is true for \(n = 1\)
B1
2.2a
Assume true for \(n = k\) so \(4^{k+1} + 5^{2k-1}\) is divisible by 21
\(= 3\mathrm{f}(k) + 21 \times 5^{2k-1}\) or e.g. \(= 24\mathrm{f}(k) - 21 \times 4^{k+1}\)
A1
1.1b
\(\mathrm{f}(k + 1) = 4\mathrm{f}(k) + 21 \times 5^{2k-1}\) or e.g. \(\mathrm{f}(k + 1) = 25\mathrm{f}(k) - 21 \times 4^{k+1}\)
A1
1.1b
If true for \(n = k\) then true for \(n = k + 1\), true for \(n = 1\) so true for all (positive integers) \(n\) (Allow “for all values”)
A1
2.4
(6)
(12 marks)
Notes
(ii) Way 1
B1: Shows that f(1) = 21
M1: Makes a statement that assumes the result is true for some value of \(n\) (Assume (true for) \(n = k\) is sufficient – note that this may be recovered in their conclusion if they say e.g. if true for \(n = k\) then … etc.)
M1: Attempts f(\(k\) + 1) – f(\(k\)) or equivalent work
A1: Achieves a correct expression for f(\(k\) + 1) – f(\(k\)) in terms of f(\(k\))
A1: Reaches a correct expression for f(\(k\) + 1) in terms of f(\(k\))
A1: Correct conclusion. This mark is dependent on all previous marks apart from the B mark. It is gained by conveying the ideas of all four underlined points either at the end of their solution or as a narrative in their solution.
Alternative: Way 2: \(\mathrm{f}(k + 1)\)
Scheme
Marks
AO
When \(n = 1\), \(4^{n+1} + 5^{2n-1} = 16 + 5 = 21\) so the statement is true for \(n = 1\)
B1
2.2a
Assume true for \(n = k\) so \(4^{k+1} + 5^{2k-1}\) is divisible by 21
If true for \(n = k\) then true for \(n = k + 1\), true for \(n = 1\) so true for all (positive integers) \(n\) (Allow “for all values”)
A1
2.4
(6)
B1: Shows that f(1) = 21
M1: Makes a statement that assumes the result is true for some value of \(n\) (Assume (true for) \(n = k\) is sufficient – note that this may be recovered in their conclusion if they say e.g. if true for \(n = k\) then … etc.)
M1: Attempts f(\(k\) + 1)
A1: Correctly obtains 4f(\(k\)) or \(21 \times 5^{2k-1}\)
A1: Reaches a correct expression for f(\(k\) + 1) in terms of f(\(k\))
A1: Correct conclusion. This mark is dependent on all previous marks apart from the B mark. It is gained by conveying the ideas of all four underlined points either at the end of their solution or as a narrative in their solution.
Alternative: Way 3: \(\mathrm{f}(k + 1) - m\mathrm{f}(k)\)
Scheme
Marks
AO
When \(n = 1\), \(4^{n+1} + 5^{2n-1} = 16 + 5 = 21\) so the statement is true for \(n = 1\)
B1
2.2a
Assume true for \(n = k\) so \(4^{k+1} + 5^{2k-1}\) is divisible by 21
If true for \(n = k\) then true for \(n = k + 1\), true for \(n = 1\) so true for all (positive integers) \(n\) (Allow “for all values”)
A1
2.4
(6)
B1: Shows that f(1) = 21
M1: Makes a statement that assumes the result is true for some value of \(n\) (Assume (true for) \(n = k\) is sufficient – note that this may be recovered in their conclusion if they say e.g. if true for \(n = k\) then … etc.)
M1: Attempts f(\(k\) + 1) – \(m\)f(\(k\))
A1: Achieves a correct expression for f(\(k\) + 1) – \(m\)f(\(k\)) in terms of f(\(k\))
A1: Reaches a correct expression for f(\(k\) + 1) in terms of f(\(k\))
A1: Correct conclusion. This mark is dependent on all previous marks apart from the B mark. It is gained by conveying the ideas of all four underlined points either at the end of their solution or as a narrative in their solution.
Alternative: Way 4: \(\mathrm{f}(k) = 21M\)
Scheme
Marks
AO
When \(n = 1\), \(4^{n+1} + 5^{2n-1} = 16 + 5 = 21\) so the statement is true for \(n = 1\)
B1
2.2a
Assume true for \(n = k\) so \(4^{k+1} + 5^{2k-1} = 21M\)
If true for \(n = k\) then true for \(n = k + 1\), true for \(n = 1\) so true for all (positive integers) \(n\) (Allow “for all values”)
A1
2.4
(6)
B1: Shows that f(1) = 21
M1: Makes a statement that assumes the result is true for some value of \(n\) (Assume (true for) \(n = k\) is sufficient – note that this may be recovered in their conclusion if they say e.g. if true for \(n = k\) then … etc.)
M1: Attempts f(\(k\) + 1)
A1: Correctly obtains \(84M\) or \(21 \times 5^{2k-1}\)
A1: Reaches a correct expression for f(\(k\) + 1) in terms of \(M\) and \(5^{2k-1}\)
A1: Correct conclusion. This mark is dependent on all previous marks apart from the B mark. It is gained by conveying the ideas of all four underlined points either at the end of their solution or as a narrative in their solution.
M1: Multiplies the matrices in the correct order (evidence of multiplication can be taken from 3 correct or 3 correct ft elements)
A1ft: Correct matrix (follow through their matrix from part (b))
A correct matrix or a correct follow through matrix implies both marks.
Mark scheme (d)
Scheme
Marks
AO
\[\begin{pmatrix}-\dfrac{\sqrt{3}}{2} & \dfrac{1}{2}\\[8pt] \dfrac{1}{2} & \dfrac{\sqrt{3}}{2}\end{pmatrix}\begin{pmatrix}1\\ k\end{pmatrix} = \begin{pmatrix}1\\ k\end{pmatrix} = \ldots \text{ or } \begin{pmatrix}-\dfrac{\sqrt{3}}{2} & \dfrac{1}{2}\\[8pt] \dfrac{1}{2} & \dfrac{\sqrt{3}}{2}\end{pmatrix}\begin{pmatrix}x\\ y\end{pmatrix} = \begin{pmatrix}x\\ y\end{pmatrix} = \ldots\]Note: \(\begin{pmatrix}-\dfrac{\sqrt{3}}{2} & \dfrac{1}{2}\\[8pt] \dfrac{1}{2} & \dfrac{\sqrt{3}}{2}\end{pmatrix}\begin{pmatrix}1\\ k\end{pmatrix} = \begin{pmatrix}-\dfrac{\sqrt{3}}{2} + \dfrac{1}{2}k\\[8pt] \dfrac{1}{2} + \dfrac{\sqrt{3}}{2}k\end{pmatrix} = \begin{pmatrix}1\\ k\end{pmatrix}\) can score M1 (for the matrix equation) but needs an equation to be “extracted” to score the next A1
M1
3.1a
\[-\frac{\sqrt{3}}{2} + \frac{1}{2}k = 1 \text{ or } \frac{1}{2} + \frac{\sqrt{3}}{2}k = k\]or\[x = -\frac{\sqrt{3}}{2}x + \frac{1}{2}y \text{ or } y = \frac{1}{2}x + \frac{\sqrt{3}}{2}y\](Note that candidates may then substitute \(x = 1\) which is acceptable)
A1ft
1.1b
\[-\frac{\sqrt{3}}{2} + \frac{1}{2}k = 1 \text{ or } x = -\frac{\sqrt{3}}{2}x + \frac{1}{2}y \Rightarrow k = 2 + \sqrt{3}\left(\text{or } \frac{1}{2 - \sqrt{3}}\right)\]
A1
1.1b
\[\frac{1}{2} + \frac{\sqrt{3}}{2}k = k \text{ or } y = \frac{1}{2}x + \frac{\sqrt{3}}{2}y \Rightarrow k = 2 + \sqrt{3}\left(\text{or } \frac{1}{2 - \sqrt{3}}\right)\]
B1
1.1b
(4)
(10 marks)
Notes
M1: Translates the problem into a matrix multiplication to obtain at least one equation in \(k\) or in \(x\) and \(y\)
A1ft: Obtains one correct equation (follow through their matrix from part (c))
A1: Correct value for \(k\) in any form
B1: Checks their answer by independently solving both equations correctly to obtain \(2 + \sqrt{3}\) both times or substitutes \(2 + \sqrt{3}\) into the other equation to confirm its validity
B1: Evidence that the determinant is \(\pm 69\) (may be implied by their matrix e.g. where entries are not in exact form: \(\pm\begin{pmatrix}0.014 & 0.188 & 0.072\\ -0.159 & -0.072 & 0.203\\ -0.377 & 0.101 & 0.116\end{pmatrix}\)) (Should be mostly correct)
Must be seen in part (a).
B1: Fully correct inverse with all elements in exact form
Selects an appropriate method eg equates one variable to zero and forms simultaneous equations in two variables. or Sets one variable equal to a multiple of a parametric variable
M1
3.1a
Obtains one correct point on the line. or Correctly obtains a second variable in terms of the parametric variable
A1
1.1b
Uses a correct method to obtain a direction vector eg Uses two points on their line to form a direction vector or Obtains the cross product of two normal vectors. or substitutes to find the third variable in terms of the parametric variable
M1
1.1a
Obtains a correct direction vector. or Correctly obtains the third variable in terms of the parametric variable
A1
1.1b
Completes a reasoned argument to obtain a correct vector equation.
R1
2.2a
(5)
(9 marks)
Typical solution
\[\begin{alignedat}{3} x &\; + \;& 2y &\; - \;& z &= 9 \\ x &\; - \;& 3y &\; + \;& 3z &= 6 \end{alignedat}\]
Let \(x = 0\):
\[\begin{aligned} 2y - z &= 9 \\ -3y + 3z &= 6 \\ -y + z &= 2 \end{aligned}\]\[y = 11,\ z = 13\]
Let \(y = 0\):
\[\begin{aligned} x - z &= 9 \\ x + 3z &= 6 \end{aligned}\]\[z = -\frac{3}{4},\ x = \frac{33}{4}\]
(a) The matrices \(\mathbf{A}\) and \(\mathbf{B}\) are given by\[\mathbf{A} = \begin{bmatrix} 4 & -3 \\ -1 & 1 \end{bmatrix} \qquad \text{and} \qquad \mathbf{B} = \begin{bmatrix} 5 & 4 \\ -3 & -2 \end{bmatrix}\]
(i) Find the matrices \(\mathbf{A}^{-1}\) and \(\mathbf{B}^{-1}\) [2 marks]
(ii) Hence verify that \((\mathbf{AB})^{-1} = \mathbf{B}^{-1}\mathbf{A}^{-1}\) [2 marks]
(b) Given that \((\mathbf{CD})^{-1} = \mathbf{D}^{-1}\mathbf{C}^{-1}\) is true for all non-singular square matrices \(\mathbf{C}\) and \(\mathbf{D}\), prove by induction that\[(\mathbf{M}^{-1})^n = (\mathbf{M}^n)^{-1}\]
is true for all \(n \in \mathbb{N}\), where \(\mathbf{M}\) is a non-singular square matrix. [4 marks]
so \((\mathbf{AB})^{-1} = \mathbf{B}^{-1}\mathbf{A}^{-1}\)
Mark scheme (b)
Scheme
Marks
AO
Writes \((\mathbf{M}^{-1})^1 = \mathbf{M}^{-1}\) and \((\mathbf{M}^1)^{-1} = \mathbf{M}^{-1}\)
B1
2.2a
Assumes \((\mathbf{M}^{-1})^k = (\mathbf{M}^k)^{-1}\) and considers \((\mathbf{M}^{-1})^k\,\mathbf{M}^{-1}\) or \(\mathbf{M}^{-1}(\mathbf{M}^{-1})^k\)
M1
2.4
Completes working to show \((\mathbf{M}^k)^{-1}\mathbf{M}^{-1}\) or \(\mathbf{M}^{-1}(\mathbf{M}^{-1})^k\) is equivalent to \((\mathbf{M}^{k+1})^{-1}\)
A1
2.2a
Completes a reasoned argument by stating that the rule is true for \(n = 1\) and if the rule is true for \(n = k\) then it is also true for \(n = k + 1\) and concludes that (by induction) \((\mathbf{M}^{-1})^n = (\mathbf{M}^n)^{-1}\) is true for all \(n \in \mathbf{N}\) This mark is dependent on all previous marks. The algebra must use an alternative letter to \(n\)
Condone reference to ‘rule’/‘statement’/‘it’ in the concluding statement.
R1
2.1
(4)
(8 marks)
Typical solution
When \(n = 1\):
\[(\mathbf{M}^{-1})^1 = \mathbf{M}^{-1} \text{ and } (\mathbf{M}^1)^{-1} = \mathbf{M}^{-1}\]
13 The matrix \(\mathbf{M}\) is defined by \(\mathbf{M} = \begin{bmatrix} 1 & -\sqrt{3} \\ \sqrt{3} & 1 \end{bmatrix}\)
(a) The matrix \(\mathbf{M}\) represents an anticlockwise rotation about the origin through an angle \(\theta\), where \(0 \leqslant \theta \leqslant 2\pi\), followed by an enlargement, scale factor \(r\), with centre at the origin where \(r\) is a positive integer.
Find the value of \(r\) and the value of \(\theta\) [3 marks]
(b) It is given that \(\begin{bmatrix} u \\ v \end{bmatrix} = \mathbf{M}\begin{bmatrix} x \\ y \end{bmatrix}\)
Using the value of \(r\) and the value of \(\theta\) which you obtained in part (a), verify that
\[r\mathrm{e}^{\mathrm{i}\theta}(x + \mathrm{i}y) = u + \mathrm{i}v\] [3 marks]
(c) Hence, find the value of \(x\) and the value of \(y\) such that\[\mathbf{M}^8\begin{bmatrix} x \\ y \end{bmatrix} = \begin{bmatrix} 0 \\ 2 \end{bmatrix}\]
Give your answers in an exact form. [4 marks]
Mark scheme (a)
Scheme
Marks
AO
Forms a matrix equation Or Forms equations in \(r\) and \(\theta\) PI by \(r = 2\) or \(\theta = \dfrac{\pi}{3}\)
Uses matrix multiplication to deduce \(u = x - \sqrt{3}y\) and \(v = \sqrt{3}x + y\)
B1
2.2a
Uses their values of \(r\) and \(\theta\) to obtain an expression for \(r\mathrm{e}^{\mathrm{i}\theta}(x + \mathrm{i}y)\) with no trigonometric or exponential terms.
M1
1.1a
Uses correct reasoning to obtain \(x - \sqrt{3}y + \mathrm{i}(\sqrt{3}x + y)\) and to conclude that \(r\mathrm{e}^{\mathrm{i}\theta}(x + \mathrm{i}y) = u + \mathrm{i}v\) or \(2\mathrm{e}^{\frac{\mathrm{i}\pi}{3}}(x + \mathrm{i}y) = u + \mathrm{i}v\)
R1
2.1
(3)
Typical solution
\[\begin{bmatrix} u \\ v \end{bmatrix} = \begin{bmatrix} 1 & -\sqrt{3} \\ \sqrt{3} & 1 \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix} = \begin{bmatrix} x - \sqrt{3}y \\ \sqrt{3}x + y \end{bmatrix}\]\[u = x - \sqrt{3}y,\ v = \sqrt{3}x + y\]\[\begin{aligned} r\mathrm{e}^{\mathrm{i}\theta}(x + \mathrm{i}y) &= 2\mathrm{e}^{\frac{\mathrm{i}\pi}{3}}(x + \mathrm{i}y) \\ &= 2\left(\cos\frac{\pi}{3} + \mathrm{i}\sin\frac{\pi}{3}\right)(x + \mathrm{i}y) \\ &= (1 + \mathrm{i}\sqrt{3})(x + \mathrm{i}y) \\ &= x - \sqrt{3}y + \mathrm{i}(\sqrt{3}x + y) \\ &= u + \mathrm{i}v \end{aligned}\]
Forms an equation including \(2^8\) or \(2^{-8}\), and \(\mathrm{e}^{\pm\frac{8\pi\mathrm{i}}{3}}\) or \(\mathrm{e}^{\pm\frac{2\pi\mathrm{i}}{3}}\) OE Or Obtains the modulus and argument of \(x + \mathrm{i}y\)
M1
3.1a
Obtains values of \(x\) and \(y\), including no trigonometric or exponential terms, from an equation including \(\mathrm{e}^{\pm\frac{8\pi\mathrm{i}}{3}}\) or \(\mathrm{e}^{\pm\frac{2\pi\mathrm{i}}{3}}\)
(a) Find the eigenvalues and corresponding eigenvectors of the matrix\[\mathbf{M} = \frac{1}{20}\begin{bmatrix} 19 & 3 \\ 3 & 11 \end{bmatrix}\] [5 marks]
(b) State, with a reason, the Cartesian equation of the line of invariant points of the matrix \(\mathbf{M}\) [2 marks]
(c) Find matrices \(\mathbf{U}\), \(\mathbf{D}\) and \(\mathbf{U}^{-1}\), such that \(\mathbf{D}\) is diagonal and \(\mathbf{M} = \mathbf{U}\mathbf{D}\mathbf{U}^{-1}\) [3 marks]
(d) Hence, find the matrix \(\mathbf{L}\) such that \(\mathbf{M}^n \to \mathbf{L}\) as \(n \to \infty\) [3 marks]
Mark scheme (a)
Scheme
Marks
AO
Forms correct characteristic equation and solves. PI by \(\lambda = 1\) & \(\lambda = 0.5\) Condone \(\lambda = 20\) & \(\lambda = 10\) from \(0 = (19 - \lambda)(11 - \lambda) - 9\)
M1
1.1a
Obtains \(\lambda = 1\) & \(\lambda = 0.5\)
A1
1.1b
Uses correct equation to find eigenvector for one of their two eigenvalues. PI by a correct eigenvector.
M1
1.1a
Obtains a correct eigenvector for one of their two eigenvalues. Allow any scalar multiple.
A1
1.1b
Obtains both correct eigenvectors paired with the corresponding correct eigenvalue. Allow any scalar multiple.
Attempts a correct calculation for the rotation angle eg \(150 \times 5\) oe PI by 750 or 30 or \(\begin{bmatrix} \dfrac{\sqrt{3}}{2} & -\dfrac{1}{2} \\[4pt] \dfrac{1}{2} & \dfrac{\sqrt{3}}{2} \end{bmatrix}\)
M1
3.1a
Obtains the correct transformation. Accept anticlockwise rotation of \(750^\circ\) about the origin oe Accept omission of ‘anticlockwise’.
A1
1.1b
(2)
Typical solution
\[750^\circ - 720^\circ = 30^\circ\]
Anticlockwise rotation of \(30^\circ\) about the origin
Mark scheme (d)
Scheme
Marks
AO
Considers multiples of 150 and/or 360 eg list of three multiples eg \(150n\) eg \(360m\)
M1
3.1a
Finds a common multiple of 150 and 360 eg 3600 or Writes an expression for \(n\) in terms of another integer, eg \(n = \dfrac{360m}{150}\) where \(m \in \mathbf{N}\) PI by an \(n\)-value which is a multiple of 12
Finds a correct direction vector between \(A\) and their \(A^{\prime}\) Do not award this mark if their ‘direction’ vector is used as a position vector.
M1
2.2a
Writes a correct vector equation using accurate notation.
(a) Given that \(\mathbf{M}\) is a non-singular matrix, find \(\mathbf{M}^{-1}\) in terms of \(k\) [5 marks]
(b) State any restrictions on the value of \(k\) [1 mark]
(c) Using your answer to part (a), show that the solution to the set of simultaneous equations below is independent of the value of \(k\)\[\begin{array}{rcrcrcl} 5x & + & 2y & + & z & = & 1 \\ 6x & + & 3y & + & (2k + 3)z & = & 4k + 3 \\ 2x & + & y & + & 5z & = & 9 \end{array}\] [4 marks]
Mark scheme (a)
Scheme
Marks
AO
Obtains \(12 - 2k\)
B1
1.1b
Obtains matrix of minors/cofactors with at least four correct elements. PI by transposed form. Condone overall sign error on each element.
M1
1.1a
Obtains matrix of minors/cofactors with at least seven correct elements. PI transposed form. Condone overall sign error on each element.
M1
1.1a
Obtains correct matrix of minors/cofactors. PI transposed form. Condone overall sign error on one element.
Obtains \(k \neq 6\) Follow through their determinant.
B1F
1.1b
(1)
Typical solution
\[k \neq 6\]
Mark scheme (c)
Scheme
Marks
AO
Uses their \(\mathbf{M}^{-1}\) to form a product to find the solution set. Must include \(\begin{bmatrix} 1 \\ 4k + 3 \\ 9 \end{bmatrix}\) or Obtains \(\mathbf{M}^{-1}\begin{bmatrix} 1 \\ 4k + 3 \\ 9 \end{bmatrix}\) for a particular value of \(k\)
M1
3.1a
Obtains at least one correct component from their \(\mathbf{M}^{-1}\), can be unsimplified. or Obtains correct \(\mathbf{M}^{-1}\begin{bmatrix} 1 \\ 4k + 3 \\ 9 \end{bmatrix}\) for their \(k\)
A1F
1.1b
Obtains at least two correct components from their \(\mathbf{M}^{-1}\) (can be unsimplified). or Correctly substitutes their \(\mathbf{M}^{-1}\begin{bmatrix} 1 \\ 4k + 3 \\ 9 \end{bmatrix}\) Into equation.
A1F
1.1b
Uses correct reasoning to obtain the required result.
Considers a general point \((x, y)\) Multiplies \(\mathbf{M}\begin{bmatrix} x \\ y \end{bmatrix}\) to form at least one correct equation. May be unsimplified. Or Shows that the origin is invariant, eg writes \(\mathbf{M}\begin{bmatrix} 0 \\ 0 \end{bmatrix} = \begin{bmatrix} 0 \\ 0 \end{bmatrix}\) eg states that the origin is always invariant under a linear transformation.
M1
3.1a
Forms two different correct equations in \(x\) and \(y\)
M1
1.1a
Completes a reasoned argument and concludes that the origin is the only invariant point.
R1
2.1
(3)
Typical solution
\[\begin{bmatrix} 3 & -1 \\ -2 & 6 \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix} = \begin{bmatrix} x \\ y \end{bmatrix}\]\[3x - y = x \quad \text{and} \quad -2x + 6y = y\]\[y = 2x \quad \text{and} \quad 2x = 5y\]\[x = 0 \quad \text{and} \quad y = 0\]
So \((0, 0)\) is the only invariant point
Mark scheme (c)
Scheme
Marks
AO
Writes the product \(\mathbf{M}\begin{bmatrix} x \\ x + 1 \end{bmatrix}\) and equates to \(\begin{bmatrix} X \\ mX + c \end{bmatrix}\) or equivalent. PI by one correct equation. Or Multiplies \(\mathbf{M}\) by a specific point on the line \(y = x + 1\)
M1
3.1a
Obtains two correct equations from \(\mathbf{M}\begin{bmatrix} x \\ x + 1 \end{bmatrix} = \begin{bmatrix} X \\ mX + c \end{bmatrix}\) or equivalent. PI Or Obtains a correct specific point on the line \(y = 2x + 8\)
A1
1.1b
Forms a correct equation in either \(m\) or \(c\) FT their two equations Or Multiplies \(\mathbf{M}\) by a second specific point on the line \(y = x + 1\)
M1
1.1a
Solves two equations in \(m\) and \(c\) Accept one incorrect equation if it has clearly come from \(\mathbf{M}\begin{bmatrix} x \\ x + 1 \end{bmatrix} = \begin{bmatrix} X \\ mX + c \end{bmatrix}\) or equivalent. Or Forms an unsimplified Cartesian equation for a straight line connecting their two points. Accept one incorrect point if it has clearly come from an attempt to find a point on the new line.
Operates first \(\mathbf{M}\), then their \(\mathbf{N}\), on column vector \(\begin{bmatrix} x \\ y \end{bmatrix}\) or Operates their \(\mathbf{N}\) or their \(\mathbf{N}^{-1}\) on \(\begin{bmatrix} 3 \\ 8 \end{bmatrix}\) or Calculates matrix product \(\mathbf{NM}\)
M1
3.1a
Obtains a correct system of simultaneous equations in \(x\) and \(y\) or Obtains correct value of \(\mathbf{M}^{-1}\) (Accept decimal approximation.) or Obtains correct value of \(\mathbf{NM}\) PI
A1
1.1b
Solves their simultaneous equations in \(x\) and \(y\) from \(\mathbf{NM}\begin{bmatrix} x \\ y \end{bmatrix} = \begin{bmatrix} 3 \\ 8 \end{bmatrix}\) or \(\mathbf{MN}\begin{bmatrix} x \\ y \end{bmatrix} = \begin{bmatrix} 3 \\ 8 \end{bmatrix}\) or Operates \(\mathbf{M}^{-1}\) on \(\mathbf{N}Q\) or Uses inverse of \(\mathbf{NM}\), where \((\mathbf{NM})^{-1} = \begin{bmatrix} 0.08927 & 0.47696 \\ 0.09821 & -0.06484 \end{bmatrix}\) to obtain coordinates of \(P\) Condone applying transformations in the wrong order.
M1
1.1a
Obtains AWRT 4.083 and AWRT \(-0.224\). Condone column vector form if \(x\) and \(y\) seen. Accept exact values. \(x = \dfrac{27 + 74\sqrt{3}}{38}\), \(y = \dfrac{14 - 13\sqrt{3}}{38}\)
A1
1.1b
(5 marks)
Typical solution
T is a reflection in the line \(y = x\tan\dfrac{\pi}{3}\)
The transformation T transforms the line \(L_1\) to the line \(L_2\)
(a) Show that the angle between \(L_1\) and \(L_2\) is 0.701 radians, correct to three decimal places. [4 marks]
(b) Find the shortest distance between \(L_1\) and \(L_2\)
Give your answer in an exact form. [6 marks]
Mark scheme (a)
Scheme
Marks
AO
Forms the product of the matrix and the direction/position vector of \(L_1\)
M1
2.2a
Obtains the correct direction vector of \(L_2\) possibly embedded
A1
1.1b
Use the scalar product of the direction vectors of \(L_1\) and their \(L_2\) to obtain their correct 28.
M1
1.1a
Completes a reasoned argument to obtain 0.701 Must see \(\cos\theta = \dfrac{28}{\sqrt{11}\sqrt{122}}\) or \(\cos\theta = 0.7643\ldots\) or \(\theta = 0.7007\ldots\)
Forms the product of the matrix and a point on \(L_1\)
M1
2.2a
Obtains a correct point on \(\begin{bmatrix}10 \\ 26 \\ -19\end{bmatrix} + \mu\begin{bmatrix}5 \\ 9 \\ 4\end{bmatrix}\)
A1
1.1b
Obtains a vector connecting a point on each line. or Obtains the equations of two correct parallel planes PI
B1
1.1b
Obtains a vector perpendicular to both lines. or Calculates the scalar product of the general vector between the lines with both direction vectors to obtain a pair of simultaneous equations.
M1
3.1a
Uses a correct method to obtain the shortest distance between the lines. Condone a negative distance or Obtains solutions to their pair of simultaneous equations and obtains the vector between the two closest points
Prove that the transformation represented by \(\mathbf{C}\) has no invariant lines of the form \(y = kx\) [4 marks]
Mark scheme
Scheme
Marks
AO
Obtains \(3x + 2kx\) and \(-4x + 5kx\) Accept any letter for \(k\) Condone use of \(y = kx + c\) Or Uses \(\det(\mathbf{C} - \lambda\mathbf{I})\)
M1
1.1a
Substitutes their \(x^{\prime}\) and \(y^{\prime}\) in \(y^{\prime} = kx^{\prime}\) Accept any letter for \(k\) Condone use of \(y = kx + c\) Or Expands \(\det(\mathbf{C} - \lambda\mathbf{I})\)
Completes a reasoned argument justifying that the quadratic equation has no real roots to prove that the transformation represented by \(\mathbf{C}\) has no invariant lines of the form \(y = kx\) If \(y = kx + c\) is used then must state and use \(c = 0\)
Find the values of \(p\) such that \(\mathbf{A}\) and \(\mathbf{B}\) are commutative under matrix multiplication.
Fully justify your answer. [4 marks]
Mark scheme
Scheme
Marks
AO
Calculates \(\mathbf{AB}\) or \(\mathbf{BA}\) with at least three correct elements.
M1
1.1a
Calculates \(\mathbf{AB}\) and \(\mathbf{BA}\) with at least seven correct elements.
M1
1.2
Uses \(\mathbf{AB} = \mathbf{BA}\) to form a quadratic equation in \(p\) and obtains at least one solution
M1
1.1a
Completes a reasoned argument to obtain \(p = 0, 3\) Must have stated that since \(\mathbf{A}\) and \(\mathbf{B}\) are commutative (under matrix multiplication,) \(\mathbf{AB} = \mathbf{BA}\)
R1
2.1
(4 marks)
Typical solution
\[\begin{aligned} \mathbf{AB} &= \begin{bmatrix} p - 2 & p - 1 \\ 0 & 1 \end{bmatrix}\begin{bmatrix} 1 & 2p - 1 \\ 0 & 4 - p \end{bmatrix} \\ &= \begin{bmatrix} p - 2 & (p - 2)(2p - 1) + (p - 1)(4 - p) \\ 0 & 4 - p \end{bmatrix} \\ &= \begin{bmatrix} p - 2 & p^2 - 2 \\ 0 & 4 - p \end{bmatrix} \end{aligned}\]\[\begin{aligned} \mathbf{BA} &= \begin{bmatrix} 1 & 2p - 1 \\ 0 & 4 - p \end{bmatrix}\begin{bmatrix} p - 2 & p - 1 \\ 0 & 1 \end{bmatrix} \\ &= \begin{bmatrix} p - 2 & p - 1 + 2p - 1 \\ 0 & 4 - p \end{bmatrix} \\ &= \begin{bmatrix} p - 2 & 3p - 2 \\ 0 & 4 - p \end{bmatrix} \end{aligned}\]
\(\mathbf{A}\) and \(\mathbf{B}\) are commutative, hence \(\mathbf{AB} = \mathbf{BA}\)
So every image point lies in the plane \(x + 5y + 3z = 0\) when \(c = 3\)
Mark scheme (b)
Scheme
Marks
AO
(i) Obtains an expression for \(|\mathbf{M}|\) Can be seen in (a)
M1
1.1a
(i) Deduces correct restriction on \(c\)
A1
2.2a
(2)
(ii) Obtains matrix of minors/cofactors with at least four correct elements PI by transposed form. Condone overall sign error on each element.
M1
1.1a
(ii) Obtains matrix of minors/cofactors with at least seven correct elements PI by transposed form. Condone overall sign error on each element.
M1
1.1a
(ii) Obtains correct matrix of minors/cofactors PI by transposed form. Condone overall sign error on each element.
A1
1.1b
(ii) Deduces fully correct, simplified answer
A1
2.2a
(4)
(iii) Obtains their correct \(\mathbf{M}^{-1}\) using \(c = 4\). Need not be simplified.
B1F
3.1a
(iii) Forms their product \(\mathbf{M}^{-1}\begin{bmatrix} -3 \\ -6 \\ 13 \end{bmatrix}\) Condone \(\mathbf{M}^{-1}\) in terms of \(c\)
M1
1.1a
(iii) Completes a reasoned argument to obtain the correct solution. Do not accept \(\mathbf{r} = \begin{bmatrix} -1 \\ 3 \\ 2 \end{bmatrix}\) But do accept \(\begin{bmatrix} x \\ y \\ z \end{bmatrix} = \begin{bmatrix} -1 \\ 3 \\ 2 \end{bmatrix}\) NMS or any method NOT using \(\mathbf{M}^{-1}\mathbf{v}\) scores 0 marks
(a) In the case when \(p = 0\) show that the image of the point \((4, 5)\) under T is the point \((64, -7)\) [2 marks]
(b) In the case when \(p = -2\) find the gradient of the line of invariant points under T [3 marks]
(c) Show that \(p = 3\) is the only real value of \(p\) for which \(\mathbf{M}\) is singular. [6 marks]
Mark scheme (a)
Scheme
Marks
AO
Forms the product \(\mathbf{M}\begin{bmatrix} 4 \\ 5 \end{bmatrix}\) or \(\mathbf{M}^{-1}\begin{bmatrix} 64 \\ -7 \end{bmatrix}\) May use the letter \(\mathbf{M}\), or \(\mathbf{M}\) in terms of \(p\), or with \(p = 0\)
M1
1.1a
Completes a reasoned argument to prove the required result. Condone no conclusion.
\(\therefore\) the image of \((4, 5)\) is \((64, -7)\)
Mark scheme (b)
Scheme
Marks
AO
Multiplies \(\mathbf{M}\) (or \(\mathbf{M}^{-1}\)) by \(\begin{bmatrix} x \\ y \end{bmatrix}\) and equates to \(\begin{bmatrix} x \\ y \end{bmatrix}\) PI Accept \(y\) replaced with \(mx\) or \(mx + c\)
M1
1.1a
Multiplying the top row of \(\mathbf{M}\) by their \(\begin{bmatrix} x \\ y \end{bmatrix}\)
M1
1.1a
Obtains correct gradient
A1
1.1b
(3)
Typical solution
\[\begin{bmatrix} -5 & 12 \\ 0 & 1 \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix} = \begin{bmatrix} x \\ y \end{bmatrix}\]\[\therefore \ -5x + 12y = x \quad \text{and} \quad 0x + y = y\]\[12y = 6x\]\[y = \frac{1}{2}x\]
The gradient is \(\dfrac{1}{2}\)
Mark scheme (c)
Scheme
Marks
AO
Uses or states \(\det\mathbf{M} = 0\)
B1
3.1a
Forms an expression for \(\det\mathbf{M}\) in \(p\) or Substitutes \(p = 3\) and evaluates \(\det\mathbf{M}\) Condone \(ad + bc\)
M1
1.1a
Obtains a correct expression for \(\det\mathbf{M}\) in terms of \(p\)
A1
1.1b
Obtains a correct simplified equation for \(\det\mathbf{M} = 0\) in terms of \(p\)
A1
1.1b
Uses a correct method to deduce that \(\det\mathbf{M} = 0\) has exactly one real root
M1
2.2a
Completes a reasoned argument that \(p = 3\) is the only real value of \(p\) for which \(\mathbf{M}\) is singular.
(b) It is given that \(\mathbf{A} = \begin{bmatrix} 4 & 5 \\ -1 & k \end{bmatrix}\), where \(k\) is a real constant.
(i) Find \(\left(\mathbf{A}^{-1}\right)^{\mathrm{T}}\), giving your answer in terms of \(k\) [2 marks]
(ii) State the restriction on the possible values of \(k\) [1 mark]
Mark scheme (a)
Scheme
Marks
AO
Uses the result \((\mathbf{AB})^{\mathrm{T}} = \mathbf{B}^{\mathrm{T}}\mathbf{A}^{\mathrm{T}}\) in a statement involving \(\mathbf{A}^{-1}\) Use of the notation \(\mathbf{A}^{-\mathrm{T}}\) is not acceptable here.
M1
3.1a
Uses the fact that the identity matrix is its own transpose. PI
M1
1.1a
Completes a reasoned argument to show the required result.
The vectors \(\mathbf{v}_1\), \(\mathbf{v}_2\), and \(\mathbf{v}_3\) are eigenvectors of \(\mathbf{M}\)
The corresponding eigenvalues are \(\lambda_1\), \(\lambda_2\), and \(\lambda_3\) respectively.
It is given that \(\lambda_2 = 1\) and \(\mathbf{v}_1 = \begin{bmatrix} 1 \\ 0 \\ 3 \end{bmatrix}\), \(\mathbf{v}_2 = \begin{bmatrix} 1 \\ 1 \\ 1 \end{bmatrix}\) and \(\mathbf{v}_3 = \begin{bmatrix} c \\ 0 \\ 1 \end{bmatrix}\),
where \(c\) is an integer.
(a)
(i) Find the value of \(\lambda_1\) [2 marks]
(ii) Find the value of \(a\) [2 marks]
(b) Find the integer \(c\) and the value of \(\lambda_3\) [4 marks]
(c) Find matrices \(\mathbf{U}\), \(\mathbf{D}\) and \(\mathbf{U}^{-1}\), such that \(\mathbf{D}\) is diagonal and \(\mathbf{M} = \mathbf{UDU}^{-1}\) [3 marks]
Mark scheme (a)
Scheme
Marks
AO
(i) Uses an appropriate method to obtain the value of \(\lambda_1\)
M1
1.1a
(i) Obtains the correct value of \(\lambda_1\)
A1
1.1b
(2)
(ii) Uses eigenvector definition to set up a linear equation in \(a\)
Deduces a correct \(\mathbf{U}\), ft their \(c\) only. Condone “\(c\)”
B1F
2.2a
Deduces the value of \(\mathbf{D}\), ft their \(\lambda_1\) and \(\lambda_3\). Must be compatible with their \(\mathbf{U}\). Condone “\(\lambda_1\)” and “\(\lambda_3\)”
B1F
2.2a
Obtains \(\mathbf{U}^{-1}\), ft their \(\mathbf{U}\)
Josh says that to solve this problem you must first carry out the transformation on \(C_1\) to find \(C_2\), and then find the asymptotes of \(C_2\)
Zoe says that you will get the same answer if you first find the asymptotes of \(C_1\), and then carry out the transformation on these asymptotes to obtain the asymptotes of \(C_2\)
Show that Zoe is correct. [5 marks]
Mark scheme
Scheme
Marks
AO
States the correct asymptotes of \(C_1\)
B1
1.1b
States the correct equation of \(C_2\)
B1
3.1a
States the correct asymptotes of \(C_2\)
B1
1.1b
Obtains the asymptotes of \(C_2\) by both methods.
M1
3.1a
Shows that both methods lead to the same answer and concludes that Zoe is correct.
R1
2.3
(5 marks)
Typical solution
Josh’s method
Reflection in \(y = x\)
\[C_2 \text{ is } \frac{y^2}{16} - \frac{x^2}{9} = 1\]
The asymptotes of \(C_2\) are \(y = \pm\dfrac{4}{3}x\)
Zoe’s method
The asymptotes of \(C_1\) are \(y = \pm\dfrac{3}{4}x\)
The transformation is a reflection in \(y = x\)
The asymptotes of \(C_2\) are \(y = \pm\dfrac{4}{3}x\)
(a) The matrix \(\mathbf{A}\) represents a reflection in the line \(y = mx\), where \(m\) is a constant.
Show that \(\mathbf{A} = \left(\dfrac{1}{m^2 + 1}\right)\begin{bmatrix} 1 - m^2 & 2m \\ 2m & m^2 - 1 \end{bmatrix}\)
You may use the result in the formulae booklet. [5 marks]
(b) The matrix \(\mathbf{B}\) is defined as \(\mathbf{B} = \begin{bmatrix} 3 & 0 \\ 0 & 3 \end{bmatrix}\)
Show that \((\mathbf{BA})^2 = k\mathbf{I}\)
where \(\mathbf{I}\) is the \(2 \times 2\) identity matrix and \(k\) is an integer. [3 marks]
(c)
(i) The diagram below shows a point \(P\) and the line \(y = mx\)
Draw four lines on the diagram to demonstrate the result proved in part (b).
Label as \(P^{\prime}\) the image of \(P\) under the transformation represented by \((\mathbf{BA})^2\) [2 marks]
(ii) Explain how your completed diagram shows the result proved in part (b). [2 marks]
(d) The matrix \(\mathbf{C}\) is defined as \(\mathbf{C} = \begin{bmatrix} \dfrac{12}{5} & \dfrac{9}{5} \\[6pt] \dfrac{9}{5} & -\dfrac{12}{5} \end{bmatrix}\)
Find the value of \(m\) such that \(\mathbf{C} = \mathbf{BA}\)
Fully justify your answer. [4 marks]
Mark scheme (a)
Scheme
Marks
AO
States that \(m = \tan\theta\) and \(\mathbf{A} = \begin{bmatrix} \cos 2\theta & \sin 2\theta \\ \sin 2\theta & -\cos 2\theta \end{bmatrix}\) Condone omission of A=
B1
1.2
Replaces \(\sin 2\theta\) and \(\cos 2\theta\) in the matrix with expressions in terms of trigonometric ratios of \(\theta\) or in terms of \(m\)
M1
3.1a
Deduces that one element of the matrix can be expressed as \(\cos^2\theta(1 - \tan^2\theta)\) or \(\cos^2\theta(1 - m^2)\) or \(2\tan\theta(\cos^2\theta)\) or \(2m\cos^2\theta\) or uses \(\cos 2\theta = \dfrac{1 - m^2}{1 + m^2}\) or \(\sin 2\theta = \dfrac{2m}{1 + m^2}\)
M1
2.2a
Uses \(\cos^2\theta = \dfrac{1}{m^2 + 1}\)
M1
1.1a
Completes a reasoned argument to obtain the required result Must include A=…
Obtains BA (condone AB) or Uses the fact that B = 3I
M1
1.1a
Squares their BA or AB or 3IA and simplifies
M1
1.1a
Completes a reasoned argument to show the required result, using BA not AB or Uses and states the fact that \(\mathbf{A}^2 = \mathbf{I}\) because it is a reflection Condone missing \((\mathbf{BA})^2 =\)
where \(\mathbf{A}\) and \(\mathbf{B}\) are square matrices of equal dimensions, and \(\mathbf{A}\) is non-singular. [4 marks]
Mark scheme
Scheme
Marks
AO
Shows that \((\mathbf{ABA}^{-1})^{n} = \mathbf{AB}^{n}\mathbf{A}^{-1}\) is true for \(n = 1\)
B1
2.1
Assumes \((\mathbf{ABA}^{-1})^{k} = \mathbf{AB}^{k}\mathbf{A}^{-1}\) and multiplies by \(\mathbf{ABA}^{-1}\)
M1
2.4
Completes rigorous working to show \((\mathbf{ABA}^{-1})^{k+1} = \mathbf{AB}^{k+1}\mathbf{A}^{-1}\)
Condone \(\mathbf{A}^{-1}\mathbf{A}\) removed without reference to \(\mathbf{I}\)
A1
2.2a
Concludes a reasoned argument by stating that \((\mathbf{ABA}^{-1})^{n} = \mathbf{AB}^{n}\mathbf{A}^{-1}\) is true for \(n = 1\), and that \((\mathbf{ABA}^{-1})^{k} = \mathbf{AB}^{k}\mathbf{A}^{-1}\) implies \((\mathbf{ABA}^{-1})^{k+1} = \mathbf{AB}^{k+1}\mathbf{A}^{-1}\) and hence, by induction, that \((\mathbf{ABA}^{-1})^{n} = \mathbf{AB}^{n}\mathbf{A}^{-1}\) is true for all integers \(n \geqslant 1\)
Condone \(\mathbf{A}^{-1}\mathbf{A}\) removed without reference to \(\mathbf{I}\)
R1
2.1
(4 marks)
Typical solution
Let \(n = 1\): \((\mathbf{ABA}^{-1})^1 = \mathbf{ABA}^{-1} = \mathbf{AB}^1\mathbf{A}^{-1}\)
\(\therefore\) it is true for \(n = 1\)
If it is true for \(n = k\), then
\[(\mathbf{ABA}^{-1})^{k} = \mathbf{AB}^{k}\mathbf{A}^{-1}\]\[\begin{aligned} &\Rightarrow (\mathbf{ABA}^{-1})^k\mathbf{ABA}^{-1} = \mathbf{AB}^k\mathbf{A}^{-1}\mathbf{ABA}^{-1} \\ &\Rightarrow (\mathbf{ABA}^{-1})^{k+1} = \mathbf{AB}^k\mathbf{IBA}^{-1} \\ &\Rightarrow (\mathbf{ABA}^{-1})^{k+1} = \mathbf{AB}^k\mathbf{BA}^{-1} \\ &\Rightarrow (\mathbf{ABA}^{-1})^{k+1} = \mathbf{AB}^{k+1}\mathbf{A}^{-1} \\ &\Rightarrow \text{it is also true for } n = k + 1\end{aligned}\]
Selects a method to find either matrix \(\mathbf{B}\) or matrix \(\mathbf{AM}\)
e.g. calculates \(\mathbf{A}^{-1}\mathbf{AB}\) with their \(\mathbf{A}^{-1}\) or calculates \(2\mathbf{A}^2 + \mathbf{AB}\) or writes four simultaneous equations in \(w, x, y, z\) where \(\begin{bmatrix} 9 & 6 \\ 5 & 12 \end{bmatrix} = \begin{bmatrix} 5 & 2 \\ -3 & 4 \end{bmatrix}\begin{bmatrix} w & x \\ y & z \end{bmatrix}\)
M1
3.1a
Obtains a correct matrix for \(\mathbf{B}\) or \(\mathbf{AM}\) i.e. \(\begin{bmatrix} 1 & 0 \\ 2 & 3 \end{bmatrix}\) or \(\begin{bmatrix} 47 & 42 \\ -49 & 32 \end{bmatrix}\)
PI by a correct matrix \(\mathbf{M}\)
FT their \(\mathbf{A}^{-1}\)
A1F
1.1b
Obtains matrix \(\mathbf{M}\) FT their \(\mathbf{A}^{-1}\)
13 The transformation S is represented by the matrix \(\begin{bmatrix} 3 & 0 \\ 0 & 1 \end{bmatrix}\)
The transformation T is a translation by the vector \(\begin{bmatrix} 0 \\ -5 \end{bmatrix}\)
Kamla transforms the graphs of various functions by applying first S, then T.
Leo says that, for some graphs, Kamla would get a different result if she applied first T, then S.
Kamla disagrees.
State who is correct.
Fully justify your answer. [3 marks]
Mark scheme
Scheme
Marks
AO
Finds the image of the general point for one order of application of S and T or Recalls that the matrix for S represents a stretch parallel to the \(x\)-axis
B1
1.2
Finds the image of the general point for the alternative order of application of S and T or Explains that S only affects \(x\) or T only affects \(y\)
B1
2.4
Completes a rigorous argument to show that Kamla is correct
R1
2.1
(3 marks)
Typical solution
S then T
\[\begin{bmatrix} 3 & 0 \\ 0 & 1 \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix} = \begin{bmatrix} 3x \\ y \end{bmatrix}\]\[\begin{bmatrix} 3x \\ y \end{bmatrix} + \begin{bmatrix} 0 \\ -5 \end{bmatrix} = \begin{bmatrix} 3x \\ y - 5 \end{bmatrix}\]
T then S
\[\begin{bmatrix} x \\ y \end{bmatrix} + \begin{bmatrix} 0 \\ -5 \end{bmatrix} = \begin{bmatrix} x \\ y - 5 \end{bmatrix}\]\[\begin{bmatrix} 3 & 0 \\ 0 & 1 \end{bmatrix}\begin{bmatrix} x \\ y - 5 \end{bmatrix} = \begin{bmatrix} 3x \\ y - 5 \end{bmatrix}\]
(i) Uses their \(\mathbf{A}^{-1}\) to form a product to find the coordinates of the point of intersection. Must include \(\begin{bmatrix}5 \\ 24 \\ -30\end{bmatrix}\) or Eliminates one variable to form two simultaneous equations in two variables
M1
3.1a
One component correct from their \(\mathbf{A}^{-1}\), can be unsimplified or Obtains one correct value for \(x\), \(y\) or \(z\), can be unsimplified
A1F
1.1b
Two components correct from their \(\mathbf{A}^{-1}\), can be unsimplified or Obtains a second correct value for \(x\), \(y\) or \(z\), can be unsimplified
A1F
1.1b
All three correct, like terms collected, but can be unsimplified Condone any form of the answer
R1
2.1
(4)
(ii) Obtains the scalar product of normal vectors of two planes
M1
3.1a
Calculates that the scalar product is 0 and interprets this as meaning the two planes are perpendicular.
A1
3.2a
Obtains vector product of the same two normal vectors or Obtains the scalar products of the other two pairs of normal vector combinations
M1
3.1a
Clearly shows the vector product is a multiple of third plane’s normal vector and interprets this as meaning that the three planes are mutually perpendicular or States that all three scalar products are zero and interprets this as meaning that the three planes are mutually perpendicular
The non-singular matrix \(\mathbf{N} = \begin{bmatrix} -0.5 & 1 & 2 \\ 1 & b & 4 \\ -3 & -2 & c \end{bmatrix}\) maps the line \(L_1\) onto the line \(L_2\)
Calculate the values of the constants \(b\), \(c\), \(m\) and \(p\)
Fully justify your answers. [9 marks]
Mark scheme
Scheme
Marks
AO
Obtains a position vector of a point on \(L_1\) or \(L_2\)
B1
2.5
Obtains a direction vector for \(L_1\) or \(L_2\), ISW
B1
1.1b
Obtains vector equations for both \(L_1\) and \(L_2\)
B1
2.5
Forms a matrix equation equating the image of a general point on \(L_1\) with a general point on \(L_2\) Condone same parameter used twice
M1
3.1a
Collects and simplifies terms
M1
1.1b
Compares their constant terms to obtain a value for at least one of \(b\) or \(c\) Must have used different parameters for their general points
M1
3.1a
Obtains correct values of both \(b\) and \(c\)
A1
1.1b
Uses their \(b\) and \(c\) to obtain a value for at least one of \(m\) or \(p\)
(a) Show that \(\det \mathbf{A} = a + \mathrm{i}\) where \(a\) is an integer to be determined. [2 marks]
(b) Matrix \(\mathbf{B}\) is given by\[\mathbf{B} = \begin{bmatrix} 14 - 2\mathrm{i} & b \\ c & d \end{bmatrix} \quad \text{and} \quad \mathbf{AB} = p\mathbf{I}\]
where \(b, c, d \in \mathbb{C}\) and \(p \in \mathbb{N}\)
Find \(b\), \(c\), \(d\) and \(p\) [6 marks]
Mark scheme (a)
Scheme
Marks
AO
Writes a correct unsimplified expression for \(\det \mathbf{A}\)
M1
1.1a
Completes a fully correct proof to reach the required result. Must have \(a = 7\)
Recognises that \(\mathbf{B}\) is equal to a multiple of \(\mathbf{A}^{-1}\) Or multiplies \(\mathbf{A}\) and \(\mathbf{B}\) to find at least one correct unsimplified element of \(\mathbf{AB}\)
M1
3.1a
Sets up at least one correct non-matrix equation in one or two unknowns by equating a pair of corresponding elements.
M1
1.1a
Sets up another correct non-matrix equation in one unknown only.
M1
1.1a
Obtains at least one correct value of \(p\), \(b\), \(c\) or \(d\). Could be seen as an element of a matrix, e.g. \(\tfrac{1}{50}\begin{bmatrix} 14 - 2\mathrm{i} & * \\ * & * \end{bmatrix}\) or \(k\begin{bmatrix} 14 - 2\mathrm{i} & 6 - 8\mathrm{i} \\ * & * \end{bmatrix}\) or \(k\begin{bmatrix} 14 - 2\mathrm{i} & * \\ -1 - 7\mathrm{i} & * \end{bmatrix}\) or \(k\begin{bmatrix} 14 - 2\mathrm{i} & * \\ * & 21 - 3\mathrm{i} \end{bmatrix}\)
A1
1.1b
Obtains at least two correct values of \(p\), \(b\), \(c\) or \(d\). Could be seen as an element of a matrix, e.g. \(\tfrac{1}{50}\begin{bmatrix} 14 - 2\mathrm{i} & * \\ * & * \end{bmatrix}\) or \(k\begin{bmatrix} 14 - 2\mathrm{i} & 6 - 8\mathrm{i} \\ * & * \end{bmatrix}\) or \(k\begin{bmatrix} 14 - 2\mathrm{i} & * \\ -1 - 7\mathrm{i} & * \end{bmatrix}\) or \(k\begin{bmatrix} 14 - 2\mathrm{i} & * \\ * & 21 - 3\mathrm{i} \end{bmatrix}\)
A1
1.1b
Obtains all four correct values of \(p\), \(b\), \(c\) and \(d\). Accept \(p = 50\) and \(\mathbf{B} = \begin{bmatrix} 14 - 2\mathrm{i} & 6 - 8\mathrm{i} \\ -1 - 7\mathrm{i} & 21 - 3\mathrm{i} \end{bmatrix}\)
5 The matrix \(\mathbf{M}\) is defined by \(\mathbf{M} = \begin{bmatrix} 3 & 2 & -2 \\ 0 & 1 & 0 \\ 0 & 0 & 1 \end{bmatrix}\)
Prove by induction that \(\mathbf{M}^n = \begin{bmatrix} 3^{n} & 3^{n} - 1 & -3^{n} + 1 \\ 0 & 1 & 0 \\ 0 & 0 & 1 \end{bmatrix}\) for all integers \(n \geqslant 1\) [5 marks]
Mark scheme
Scheme
Marks
AO
Demonstrates the result for \(n = 1\) and states that it is true for \(n = 1\)
B1
1.1b
States the assumption that the result true for \(n = k\) Condone use of \(n\) instead of \(k\)
B1
2.4
Writes \(\mathbf{M}^{k+1}\) as \(\mathbf{M}\mathbf{M}^k\) or \(\mathbf{M}^k\mathbf{M}\) Condone use of \(n\) instead of \(k\)
M1
3.1a
Calculates \(\mathbf{M}^{k+1}\) correctly (fully simplified) Condone use of \(n\) instead of \(k\)
A1
1.1b
Completes a rigorous argument by stating that It is true for \(n = 1\); that if it is true for \(n = k\) then it is true for \(n = k + 1\) And hence (by induction) true for all integers \(n \geqslant 1\) Do not condone use of \(n\) instead of \(k\) in the inductive step
R1
2.1
(5 marks)
Typical solution
Let \(n = 1\) then \(\mathbf{M}^1 = \begin{bmatrix} 3 & 2 & -2 \\ 0 & 1 & 0 \\ 0 & 0 & 1 \end{bmatrix} = \mathbf{M}\) so the result is true for \(n = 1\)
Correctly uses pre- or post - multiplication by either \(\mathbf{A}^{-1}\), \(\mathbf{B}^{-1}\) or \(\mathbf{M}^{-1}\) in a way which gives a product equal to \(\mathbf{I}\), starting from \(\mathbf{M} = \mathbf{AB}\) or \(\mathbf{ABM}^{-1} = \mathbf{I}\) or \(\mathbf{M}^{-1}\mathbf{AB} = \mathbf{I}\)
M1
1.1a
Correctly simplifies \(\mathbf{AA}^{-1} = \mathbf{I}\) OE or \(\mathbf{BB}^{-1} = \mathbf{I}\) OE in a correct equation.
M1
1.1a
Completes a rigorous argument to prove that \(\mathbf{M}^{-1} = \mathbf{B}^{-1}\mathbf{A}^{-1}\).
Use \(\mathbf{C}\) to show that \(\cos\dfrac{\pi}{12}\) can be written in the form \(\dfrac{\sqrt{\sqrt{m} + n}}{2}\), where \(m\) and \(n\) are integers. [7 marks]
Mark scheme
Scheme
Marks
AO
Explains that \(\mathbf{C}^2\) represents a rotation of \(\dfrac{\pi}{6}\) or that \(\mathbf{C}\) represents a rotation of \(\dfrac{\pi}{12}\)
E1
2.4
Squares matrix \(\mathbf{C}\) with at least two correct elements.
M1
3.1a
Forms two simultaneous equations in \(a\) and \(b\) using their squared \(\mathbf{C}\) and the given \(\mathbf{C}^2\)
M1
1.1a
Forms two correct simultaneous equations.
A1
1.1b
Eliminates \(a\) or \(b\) and forms a quadratic equation in \(b^2\) or \(a^2\)
M1
1.1a
Finds the correct value of \(a^2 = \dfrac{\sqrt{3} + 2}{4}\)
A1
1.1b
Completes a rigorous argument to show that \(\cos\dfrac{\pi}{12} = \dfrac{\sqrt{\sqrt{3} + 2}}{2}\) by explaining that \(\mathbf{C}\) represents a rotation of \(\dfrac{\pi}{12}\)
R1
2.1
(7 marks)
Typical solution
\[\begin{bmatrix} a & -b \\ b & a \end{bmatrix}\begin{bmatrix} a & -b \\ b & a \end{bmatrix} = \begin{bmatrix} a^2 - b^2 & -2ab \\ 2ab & a^2 - b^2 \end{bmatrix}\]\[2ab = \frac{1}{2}\]\[a^2 - b^2 = \frac{\sqrt{3}}{2}\]\[b = \frac{1}{4a}\]\[a^2 - \frac{1}{16a^2} = \frac{\sqrt{3}}{2}\]\[16a^4 - 8\sqrt{3}a^2 - 1 = 0\]\[a^2 = \frac{\sqrt{3} + 2}{4}\]\[a = \frac{\sqrt{\sqrt{3} + 2}}{2} \quad \text{since } a \gt 0\]
\(\mathbf{C}^2\) represents a rotation of \(\dfrac{\pi}{6}\), therefore \(\mathbf{C}\) represents a rotation of \(\dfrac{1}{2}\left(\dfrac{\pi}{6}\right) = \dfrac{\pi}{12}\)
So \(a = \cos\dfrac{\pi}{12}\) and \(\cos\dfrac{\pi}{12} = \dfrac{\sqrt{\sqrt{3} + 2}}{2}\)
When \(k = 4.5\), clearly shows or explains that the system of equations is consistent, using equations of planes or augmented matrix form. Must state the system is consistent.
B1
3.1a
States that two planes are the same and intersect the third plane.
B1
3.2a
When \(k = -1\), completes appropriate working to find the consistency of the system using their \(k\).
M1
3.1a
States that the system is inconsistent and that the three planes form a prism. CSO
4 The matrices \(\mathbf{A}\) and \(\mathbf{B}\) are defined as follows:
\[\mathbf{A} = \begin{bmatrix} x + 1 & 2 \\ x + 2 & -3 \end{bmatrix} \qquad \mathbf{B} = \begin{bmatrix} x - 4 & x - 2 \\ 0 & -2 \end{bmatrix}\]
Show that there is a value of \(x\) for which \(\mathbf{AB} = k\mathbf{I}\), where \(\mathbf{I}\) is the \(2 \times 2\) identity matrix and \(k\) is an integer to be found. [3 marks]
Mark scheme
Scheme
Marks
AO
Multiplies matrices \(\mathbf{A}\) and \(\mathbf{B}\) to form the product \(\mathbf{AB}\) with at least one element of the product correct. Condone \(\mathbf{BA}\)
M1
1.1a
Forms the correct product \(\mathbf{AB}\) (may be unsimplified)
A1
1.1b
Deduces from correct product that \(\mathbf{AB} = 6\mathbf{I}\), when \(x = -2\)
Selects a method to show that AB is singular. e.g. equates their expression for the determinant to zero or substitutes \(a = -1\) into their expression for the determinant.
M1
1.1a
Completes a fully correct reasoned argument to show that AB is singular, clearly referring to singular \(\Leftrightarrow\) determinant = 0.
(a) Prove by induction that, for all integers \(n \geqslant 1\),\[\mathbf{A}^n = \begin{bmatrix} 1 & 3^n - 1 \\ 0 & 3^n \end{bmatrix}\]
[4 marks]
(b) Find all invariant lines under the transformation matrix \(\mathbf{A}\). Fully justify your answer. [6 marks]
(c) Find a line of invariant points under the transformation matrix \(\mathbf{A}\). [2 marks]
Mark scheme (a)
Scheme
Marks
AO
Demonstrates the rule is correct for \(n = 1\) and states that it is true for \(n = 1\) (may appear at any stage).
B1
1.1b
Multiplies \(\begin{bmatrix} 1 & 3^k - 1 \\ 0 & 3^k \end{bmatrix}\) and \(\begin{bmatrix} 1 & 2 \\ 0 & 3 \end{bmatrix}\) Accept any letter in place of \(k\) (condone \(n\)).
M1
2.4
Obtains \(\begin{bmatrix} 1 & 3^{k+1} - 1 \\ 0 & 3^{k+1} \end{bmatrix}\) from multiplying \(\begin{bmatrix} 1 & 3^k - 1 \\ 0 & 3^k \end{bmatrix}\) and \(\begin{bmatrix} 1 & 2 \\ 0 & 3 \end{bmatrix}\) Must include an intermediate step for the top right element.
A1
2.2a
Completes a rigorous argument and explains how their argument proves the required result. e.g. states “assume that the rule is true for \(n = k\)” (or equivalent) and “also true for \(n = k + 1\)” (or equivalent) and “for all \(n\)” and includes the base case with a conclusion. Do not accept the use of \(n\) in place of \(k\). NMS scores 0/4
(a) Solve the equation \(z^3 = \sqrt{2} - \sqrt{6}\mathrm{i}\), giving your answers in the form \(r\mathrm{e}^{\mathrm{i}\theta}\) where \(r \gt 0\) and \(0 \leqslant \theta \lt 2\pi\) [5 marks]
(b) The transformation represented by the matrix \(\mathbf{M} = \begin{bmatrix} 5 & 1 \\ 1 & 3 \end{bmatrix}\) acts on the points on an Argand Diagram which represent the roots of the equation in part (a).
Find the exact area of the shape formed by joining the transformed points. [4 marks]
Mark scheme (a)
Scheme
Marks
AO
Writes complex number in Eulerian form or equivalent. PI correct \(r\) & \(\theta\)
B1
1.1b
Obtains \(r\) by taking cube root of their modulus of \(z^3\), accept AWRT 1.41 or \(\left(2\sqrt{2}\right)^{\frac{1}{3}}\) OE
(a) Show that \(\mathbf{A}\) is independent of the value of \(\theta\). [3 marks]
(b) Give a full description of the single transformation represented by the matrix \(\mathbf{A}\). [1 mark]
Mark scheme (a)
Scheme
Marks
AO
Finds the correct matrix for \(\mathbf{R}^{-1}\) PI by correct \(\mathbf{A}\)
B1
2.2a
Appropriate method to find \(\mathbf{A}\), such as post multiplying \(\mathbf{B}\) by \(\mathbf{R}^{-1}\) PI by correct \(\mathbf{A}\)
M1
1.1a
Completes a rigorous argument to show the required result, including finding the correct matrix for \(\mathbf{A}\). Must include conclusion that \(\mathbf{A}\) is independent of \(\theta\)
16 Two matrices \(\mathbf{A}\) and \(\mathbf{B}\) satisfy the equation
\[\mathbf{AB} = \boldsymbol{I} + 2\mathbf{A}\]
where \(\boldsymbol{I}\) is the identity matrix and \(\mathbf{B} = \begin{bmatrix} 3 & -2 \\ -4 & 8 \end{bmatrix}\)
Find \(\mathbf{A}\). [3 marks]
Mark scheme
Scheme
Marks
AO
Uses factorisation or pre-multiplication to isolate \(\boldsymbol{A}\)
M1
3.1a
Deduces \(\boldsymbol{A}\) in terms of \(\boldsymbol{B}\) and \(\boldsymbol{I}\). Could be implied by sight of \(\begin{bmatrix} 1 & -2 \\ -4 & 6 \end{bmatrix}\) with attempt to invert.
(a) Show that the matrix \(\begin{bmatrix} 5 - k & 2 \\ k^3 + 1 & k \end{bmatrix}\) is singular when \(k = 1\). [1 mark]
(b) Find the values of \(k\) for which the matrix \(\begin{bmatrix} 5 - k & 2 \\ k^3 + 1 & k \end{bmatrix}\) has a negative determinant. Fully justify your answer. [5 marks]
Mark scheme (a)
Scheme
Marks
AO
Substitutes \(k = 1\) and correctly calculates the determinant, and concludes that the matrix is singular.
Finds determinant in terms of \(k\). Allow one error.
M1
1.1a
Obtains a correct inequality in \(k\).
A1
1.1b
Obtains three correct critical values.
A1
1.1b
Deduces one correct region. FT their three real distinct critical values if given as \(a \lt k \lt b\), \(k \gt c\) (o.e.) where \(a \lt b \lt c\)
A1F
2.2a
Deduces the other correct region. FT their three real distinct critical values if given as \(a \lt k \lt b\), \(k \gt c\) (o.e.) where \(a \lt b \lt c\) Condone the use of ‘and’.
7 Find two invariant points under the transformation given by \(\begin{bmatrix} 2 & 3 \\ 1 & 4 \end{bmatrix}\) [2 marks]
Mark scheme
Scheme
Marks
AO
Obtains two equations in \(x\) and \(y\). May be seen as a single vector equation. At least one equation must be correct. Accept a pair of letters other than \(x\) and \(y\). Ignore any subsequent incorrect working.
M1
1.1a
Obtains any two correct invariant points, with no incorrect points. Condone correct points given as position vectors. NMS: Correct answer scores 2/2. NMS: One correct invariant point and only one incorrect point scores SC1.
A1
1.1b
(2 marks)
Typical solution
\[\begin{bmatrix} 2 & 3 \\ 1 & 4 \end{bmatrix}\begin{bmatrix} x \\ y \end{bmatrix} = \begin{bmatrix} x \\ y \end{bmatrix}\]\[\begin{bmatrix} 2x + 3y \\ x + 4y \end{bmatrix} = \begin{bmatrix} x \\ y \end{bmatrix}\]\[2x + 3y = x \quad \text{and} \quad x + 4y = y\]\[x = -3y\]
\(\therefore\) two invariant points are \((0, 0)\) and \((-3, 1)\)
Selects correct angle. Accept \(\frac{2\pi}{3}\) or \(-240^\circ\) or \(-\frac{4\pi}{3}\)
A1
1.1b
Deduces the transformation giving a full description. FT their angle. Accept \(\frac{2\pi}{3}\) or \(-240^\circ\) or \(-\frac{4\pi}{3}\) Condone missing degree sign. Condone missing ‘anticlockwise’. NMS scores 3/3
8 Matrix \(\mathbf{A}\) is given by \(\mathbf{A} = \begin{pmatrix} 5 + a & 5 & 1 \\ 3 & 13 + a & 6 \\ a - 4 & -20 & -9 \end{pmatrix}\) where \(a\) is a constant and all entries of \(\mathbf{A}\) are integers.
The transformation represented by \(\mathbf{A}\) is applied to a shape of volume 8 units. The image shape has volume 40 units and the orientation of the image is reversed.
Determine the image under \(\mathbf{A}\) of the point \((1, 2, 3)\). [7]
Mark scheme
Scheme
Marks
AO
Vol SF \(= 40/8 = 5\) & reverse of orientation \(\Rightarrow \det\mathbf{A} = -5\)
\(= \begin{pmatrix} 15 \\ 41 \\ -74 \end{pmatrix}\) so image is \((15, 41, -74)\)
A1
1.1
[7]
Notes
B1: Could see embedded in equation below Can allow recovery in equation
M1: Expanding the determinant Allow sign errors Allow if two of the three minor determinants are correct
M1: Reduction of determinant to three term quadratic form (could be done in conjunction with “\(= -5\)” or “\(= 5\)”). Allow sign errors Must have used correct form of determinant (apart from sign errors)
A1: Arriving at correct 3 term quadratic equation in \(a\). BOD omission of “\(= 0\)” if correct \(a\) values appears
A1: Must see both correct roots and correct reason for rejection
M1: Multiplying their \(\mathbf{A}\) by the position vector of the given point. Must be correct order of multiplication Must have used a numerical value of \(a\)
A1: Condone position vector as answer. Must have come from correct equation found correctly. Allow if reason for rejection of \(a = 9/10\) is incorrect or omitted. (Corrected from the printed mark scheme: the printed guidance says \(a = -9/10\); the rejected root is \(a = 9/10\).)
5 A vector equation of the plane \(\Pi_1\) is \(\mathbf{r} = \begin{pmatrix} 1 \\ 4 \\ 3 \end{pmatrix} + \lambda\begin{pmatrix} 3 \\ 1 \\ -1 \end{pmatrix} + \mu\begin{pmatrix} 1 \\ 1 \\ 0 \end{pmatrix}\).
(a)Verify that a cartesian equation of \(\Pi_1\) is \(x - y + 2z = 3\). [1]
For some real constant \(a\), cartesian equations of planes \(\Pi_2\) and \(\Pi_3\) are
\(\begin{aligned} \Pi_2&: \quad x \phantom{{}-y} - 3z = 1 \\ \Pi_3&: \quad ax - y - z = 4 \end{aligned}\)
(b) By considering a suitable matrix, show that \(\Pi_1\), \(\Pi_2\) and \(\Pi_3\) intersect at a single point for all values of \(a\) except \(a = 2\). [3]
(c) Use the matrix from part (b) to find the coordinates of the point of intersection of \(\Pi_1\), \(\Pi_2\) and \(\Pi_3\) in the case where \(a = 3\). [2]
(d) In the case where \(a = 2\), determine the geometrical arrangement of \(\Pi_1\), \(\Pi_2\) and \(\Pi_3\). [2]
B1:AG substitutes into cartesian equation and obtains 3 or showing that 3 = 3 – must be at least one line of intermediate working from substitution to given answer – as a minimum allow correct expression without any brackets followed by 3. Alternative method would be to find at least three points from the vector equation and show that all three satisfy the cartesian equation
Planes intersect at a single point if and only if \(\det\mathbf{M} \neq 0\). Therefore \(3a - 6 \neq 0 \Rightarrow a \neq 2\).
A1
2.2a
[3]
Notes
M1*: For determinant of a relevant matrix (e.g. rows interchanged but not columns) – no MR of values in this part but allow a slip in no more than 2 (of the 9) values
M1dep*: Finds determinant of their matrix as far as calculating \(2 \times 2\) determinants. May expand by any row or column. Ignore sign errors in \(2 \times 2\) determinant calculations if shown, but cofactors must have correct signs.
A1: AG - correct determinant followed by 2 and either mention of that for a single point of intersection determinant \(\neq 0\)or for no single point of intersection determinant \(= 0\) - allow substitution of 2 into correct determinant to obtain 0
B1: This mark is for a clear intention to consider \(\begin{pmatrix} 1 & -1 & 2 \\ 1 & 0 & -3 \\ 3 & -1 & -1 \end{pmatrix}^{-1} \begin{pmatrix} 3 \\ 1 \\ 4 \end{pmatrix}\) so \(\begin{pmatrix} 1 & -1 & 2 \\ 1 & 0 & -3 \\ 3 & -1 & -1 \end{pmatrix} \begin{pmatrix} x \\ y \\ z \end{pmatrix} = \begin{pmatrix} 3 \\ 1 \\ 4 \end{pmatrix}\) only is B0. For reference the correct inverse is \(\dfrac{1}{3}\begin{pmatrix} -3 & -3 & 3 \\ -8 & -7 & 5 \\ -1 & -2 & 1 \end{pmatrix}\). Allow \(\begin{pmatrix} x \\ y \\ z \end{pmatrix} = \mathbf{M}^{-1}\begin{pmatrix} 3 \\ 1 \\ 4 \end{pmatrix}\) providing \(\mathbf{M}\) defined (in this part or in part (b))
B1: BC - values must be exact but allow \(x = 0, y = -\frac{11}{3}, z = -\frac{1}{3}\) and condone position vector – this mark is independent of the previous B1 mark
Mark scheme (d)
Scheme
Marks
AO
\([1]: x - y + 2z = 3\) \([2]: x - 3z = 1\) \([3]: 2x - y - z = 4\) So [1] + [2] = [3] or [3] – [2] = [1]
B1*
1.1
So, equations are consistent (and as none of the planes are coincident so) geometrically, the planes meet in a straight line/they form a sheaf.
B1dep*
3.2a
[2]
Notes
B1*: For showing consistency (must explicitly link all three equations together). Note that eliminating \(x\) gives \(5z - y = 2\) or eliminating \(z\) gives \(5x - 3y = 11\), but these must be derived twice for B1. No MR in this part (so must be using the correct equations). Stating the equation of the line where the three planes meet with no working scores zero marks in this part
B1dep*: For “consistent/infinite solutions” and either “line” or “sheaf” If B0 B0 then SC B1 for implicitly showing consistency (e.g. [1] + [2] = \(2x - y - z = 4\) but not explicitly linking this to [3]) together with ‘consistent/ infinite solutions’ and either ‘line’ or ‘sheaf’
4 Two transformations, \(\mathrm{T_A}\) and \(\mathrm{T_B}\), are represented by matrices \(\mathbf{A}\) and \(\mathbf{B}\) respectively.
The matrix \(\mathbf{A}\) is given by \(\mathbf{A} = \begin{pmatrix} 0 & 1 \\ 1 & 0 \end{pmatrix}\).
(a)
(i) Describe the transformation \(\mathrm{T_A}\). [1]
(ii) Explain geometrically why \(\mathbf{A}^{-1} = \mathbf{A}\). [1]
The matrix \(\mathbf{B}\) is given by \(\mathbf{B} = \dfrac{1}{2}\begin{pmatrix} 1 & -\sqrt{3} \\ \sqrt{3} & 1 \end{pmatrix}\).
(b) Describe the transformation \(\mathrm{T_B}\). [2]
The transformation \(\mathrm{T_C}\) is equivalent to \(\mathrm{T_A}\) followed by \(\mathrm{T_B}\).
(c) Determine the single matrix which represents \(\mathrm{T_C}\). [2]
Mark scheme (a)
Scheme
Marks
AO
(i) Reflection in the line \(y = x\).
B1
1.2
[1]
(ii) If you carry out the same reflection twice you get back to where you started.
B1
2.4
[1]
Notes
(a)(i)
B1: Not “mirrored”
(a)(ii)
B1: The idea that the second identical reflection undoes the first. BOD reference to mirror here Must be a geometrical argument B0 if only argument is det(M) = -1
Mark scheme (b)
Scheme
Marks
AO
Rotation
M1
2.2a
By \((+)\dfrac{1}{3}\pi\) (radians) anticlockwise about \(O\).
A1
1.1
[2]
Notes
M1: Recognising the matrix as a rotation.
A1: Angle and sense given. Allow \(60^\circ\) for angle Allow omissions of \(O\) A0 if includes another transformation as well
Mark scheme (c)
Scheme
Marks
AO
\(\mathrm{T_C}\) is represented by \(\mathbf{BA}\)
M1: Recalling the connection between inverse transformation and inverse matrix. Could be stated in words or implied by an attempt at the inverse e.g. \(A^{-1} = \cdots\) or \(\frac{1}{n}\begin{pmatrix} d & -b \\ -c & a \end{pmatrix}\) etc.
A1FT: FT their det A from (b) if not recalculated. ISW. \(\begin{pmatrix} \frac{2}{5} & \frac{3}{20} \\ -\frac{1}{5} & \frac{1}{20} \end{pmatrix}\) or \(\begin{pmatrix} 0.4 & 0.15 \\ -0.2 & 0.05 \end{pmatrix}\)
(a) A matrix \(\mathbf{M}\) is given by \(\mathbf{M} = \begin{pmatrix} 5 & 0 \\ 0 & 5 \end{pmatrix}\). Describe the transformation represented by \(\mathbf{M}\). [2]
(b) Write down the \(2 \times 2\) matrix that represents a rotation of \(90^\circ\) anticlockwise about the origin. [1]
(c) Write down the \(3 \times 3\) matrix that represents a reflection in the \(x\)–\(z\) plane. [1]
Mark scheme (a)
Scheme
Marks
AO
Enlargement, scale factor 5, centre at the origin
B2
1.2 1.1
[2]
Notes
B2: for all three correct components, B1 for any two Accept “enlarge” and accept “stretch” but only if specified in both \(x\) and \(y\) directions For ‘scale factor’ accept just ‘factor’ or ‘SF’ but not just ‘5’ For ‘origin’ accept \(O\) or \((0, 0)\) allow omission of ‘centre’ provided intention is clear (e.g. ‘about \(O\)’) If more than two transformations given, then B0 (unless this is two stretches in both \(x\) and \(y\) directions)
8 Three transformations, \(\mathrm{T_A}\), \(\mathrm{T_B}\) and \(\mathrm{T_C}\), are represented by the matrices \(\mathbf{A}\), \(\mathbf{B}\) and \(\mathbf{C}\) respectively.
You are given that \(\mathbf{A} = \begin{pmatrix} 1 & 0 \\ 2 & 3 \end{pmatrix}\) and \(\mathbf{B} = \begin{pmatrix} 1 & 0 \\ 0 & -1 \end{pmatrix}\).
(a) Find the matrix which represents the inverse transformation of \(\mathrm{T_A}\). [1]
(b) By considering matrix multiplication, determine whether \(\mathrm{T_A}\) followed by \(\mathrm{T_B}\) is the same transformation as \(\mathrm{T_B}\) followed by \(\mathrm{T_A}\). [2]
Transformations R and S are each defined as being the result of successive transformations, as specified in the table.
Transformation
First transformation
followed by
R
\(\mathrm{T_A}\) followed by \(\mathrm{T_B}\)
\(\mathrm{T_C}\)
S
\(\mathrm{T_A}\)
\(\mathrm{T_B}\) followed by \(\mathrm{T_C}\)
(c) Explain, using a property of matrix multiplication, why R and S are the same transformations. [2]
A quadrilateral, \(Q\), has vertices \(D\), \(E\), \(F\) and \(G\) in anticlockwise order from \(D\). Under transformation R, \(Q\)’s image, \(Q'\), has vertices \(D'\), \(E'\), \(F'\) and \(G'\) (where \(D'\) is the image of \(D\), etc). The area of \(Q\), in suitable units, is 5.
You are given that \(\det\mathbf{C} = a^2 + 1\) where \(a\) is a real constant.
(d)
(i) Determine the order of the vertices of \(Q'\), starting anticlockwise from \(D'\). [2]
(ii) Find, in terms of \(a\), the area of \(Q'\). [1]
(iii) Explain whether the inverse transformation for R exists. Justify your answer. [2]
\([\mathbf{BA} =]\begin{pmatrix} 1 & 0 \\ 0 & -1 \end{pmatrix}\begin{pmatrix} 1 & 0 \\ 2 & 3 \end{pmatrix} = \begin{pmatrix} 1 & 0 \\ -2 & -3 \end{pmatrix}\) so they are not the same
A1
2.2a
[2]
Notes
M1: Correctly finding either \(\mathbf{AB}\) or \(\mathbf{BA}\).
A1: Must give correct calculation and correct conclusion. \(\mathbf{AB} \ne \mathbf{BA}\) is fine for conclusion. General statement “matrices not commutable not OK unless linked to particular case.
Mark scheme (c)
Scheme
Marks
AO
The matrix representing R is \(\mathbf{C}(\mathbf{BA})\)...
M1
3.1a
...and the matrix representing S is \((\mathbf{CB})\mathbf{A}\) and by associativity (of matrix multiplication), \(\mathbf{C}(\mathbf{BA}) = (\mathbf{CB})\mathbf{A}\) (so R and S are the same)
A1
3.2a
[2]
Notes
M1: Or the matrix representing S is \((\mathbf{CB})\mathbf{A}\) Must have \(\mathbf{R} = \mathbf{C}(\mathbf{BA})\) or \(\mathbf{S} = (\mathbf{CB})\mathbf{A}\) with brackets or equivalent correct Need to see the brackets or equivalent BOD sight of \(\mathrm{T_A}\)
A1: Correct form for S and either explicit equality or associativity property explicitly mentioned. M1 A0 only if state that matrices are commutative If M0 then SC B1 for observation that \((\mathbf{AB})\mathbf{C} = \mathbf{A}(\mathbf{BC})\) or any other correct statement of associativity of matrix multiplication.
Mark scheme (d)
Scheme
Marks
AO
(i) \(\det\mathbf{A} = 3\) or \(\det\mathbf{B} = -1\)
M1
1.1
\(\det(\mathbf{CBA}) = -3(a^2 + 1) \lt 0\) (since \(a\) is real) [so the orientation is reversed]. Order is \(D'\), \(G'\), \(F'\), \(E'\)
A1
2.2a
[2]
(ii) \(15(a^2 + 1)\)
B1FT
1.1
[1]
(iii) The determinant is not zero...
M1
1.1
...so the inverse transformation exists.
A1FT
2.2a
[2]
Notes
(d)(i)
M1: Correctly calculating the determinant of A or B Question says “Determine” so answer only is 0
A1: Some justification must be given but condone incorrect order of matrices. Orientation reversed is fine, but must see correct det \((\mathbf{CBA})\) Can consider \(\det(\mathbf{C})\det(\mathbf{B})\det(\mathbf{A})\) instead, i.e. the effect on orientation of each of the three transformations Allow “the order is clockwise”.
SC1 If neither det \(\mathbf{A}\) or det \(\mathbf{B}\) explicitly calculated then allow B1 for det \(\mathbf{A}\), det \(\mathbf{C}\) positive and det \(\mathbf{B}\) negative so orientation reversed. SC2 If only det (C) considered (i.e. candidate thinks transformation R is represented by \(\mathbf{C}\)) then allow B1 for \(a^2 + 1 \gt 0\) so orientation is the same
(d)(ii)
B1FT: FT \(5 \times |\)their determinant from (i)\(|\) (if found) FT only if their determinant is negative
(d)(iii)
M1: Understanding that the matrix associated with the transformation is non-singular. Allow M1 for “the determinant is negative”. Or equating det to 0 and solving even if conclusion wrong Can be considering det \(\mathbf{C}\) or det \(\mathbf{R}\) here Allow M1 for “determinant is positive” ONLY if it is clear where the determinant has come from (e.g. from det \(\mathbf{C}\)).
A1FT: Condone use of “matrix” rather than “transformation” (and vice versa as applicable). Allow follow through if they are using det C. If have found matrix singular when \(a = \mathrm{i}\) then need to discount this as not real. If their determinant is 0 then SC1 only can be awarded for showing understanding that the transformation associated with a singular matrix does not have an inverse. Need the be showing non-zero determinant.
So true for \(n = k \Rightarrow\) true for \(n = k + 1\). But true for \(n = 1\). Therefore true for all [integer] \(n \geqslant 1\).
A1
2.4
[5]
Notes
B1: \(\mathbf{A}^1\) and \(a \times 1\) must both be seen explicitly. Accept “\(= \mathbf{A}\)” instead of “therefore true when \(n = 1\)”
M1: Setting up the inductive hypothesis properly.
M1: Considering \(\mathbf{A}^{k+1}\) and using their inductive hypothesis. Could also consider \(\mathbf{AA}^k\) Jumping to \(\mathbf{A}^{k+1} = \begin{pmatrix} 1 & a(k + 1) \\ 0 & 1 \end{pmatrix}\) without seeing the two matrices multiplied together first scores M0.
A1: Must see \(a + ak\) appear before being factorised.
A1: Clear conclusion for induction process. Must mention both basis case and that statement true for \(k\) implies true for \(k + 1\). BOD missing the word integer If B0 not awarded as \(\mathbf{A}^1\) or \(a \times 1\) (or both) not seen allow A1 here (but must have attempt at base case)
3 A transformation T is represented by the matrix \(\mathbf{N} = \begin{pmatrix} a & 4 & 2 \\ 5 & 1 & 0 \\ 3 & 6 & 3 \end{pmatrix}\), where \(a\) is a constant.
(a) Find \(\mathbf{N}^2\) in terms of \(a\). [3]
(b) Find \(\det \mathbf{N}\) in terms of \(a\). [2]
The value of \(a\) is 13 to the nearest integer.
A shape \(S_1\) has volume 11.6 to 1 decimal place. Shape \(S_1\) is mapped to shape \(S_2\) by the transformation T.
A student claims that the volume of \(S_2\) is less than 400.
M1: Correct method. May see \(a(3 - 0) - 4(15 - 0) + 2(30 - 3)\). Ignore sign errors in \(2 \times 2\) determinant calculations, but cofactors must have correct signs. Do look out for expanding by other rows and columns. If using Sarrus’ method, must see correct 66 and \(3a + 60\). Or for \(\begin{pmatrix} a \\ 5 \\ 3 \end{pmatrix} \bullet \left(\begin{pmatrix} 4 \\ 1 \\ 6 \end{pmatrix} \times \begin{pmatrix} 2 \\ 0 \\ 3 \end{pmatrix}\right) = \begin{pmatrix} a \\ 5 \\ 3 \end{pmatrix} \bullet \begin{pmatrix} k_1 \\ k_2 \\ k_3 \end{pmatrix}\) (oe) with at least one of \(k_1 = 3, k_2 = 0, k_3 = -2\) correct.
A1: cao
Mark scheme (c)
Scheme
Marks
AO
\(11.6 \times \det\mathbf{N}\)
M1
1.1
For example, Upper bound is \(11.65 \times (3 \times 13.5 - 6) = 401.925\) Lower bound is \(11.55 \times (3 \times 12.5 - 6) = 363.825\)
A1
3.1a
So, the student’s claim (that the volume is less than 400) is not necessarily true.
A1
2.2b
[3]
Notes
M1: Or \(k \times \det\mathbf{N}\) where \(11.55 \leqslant k \leqslant 11.65\) and \(12.5 \leqslant a \leqslant 13.5\) in their \(\det\mathbf{N}\) from part (b). If not calculating the correct UB and LB (from a correct determinant) then we must see either a correct calculation (for their determinant from part (b)) or they must state, the values they’ve used in their calculation for both \(a\) and the volume of \(S_1\) to award any marks.
A1: For either correct upper or lower bound, or any correct \(V_2\) for any value of \(a\) between 12.5 and 13.5, and \(11.55 \lt V_1 \lt 11.65\). Allow answers rounded or truncated to the nearest integer or greater degree of accuracy.
A1: Demonstrates that there are values of \(12.5 \leqslant a \lt 13.5\) and \(11.55 \leqslant k \lt 11.65\) such that both \(V \gt 400\), and \(V \lt 400\) and concludes that the volume may be greater or less than 400 (depending on a more accurately determined value of \(a\) and the volume of \(S_1\)). Conclusion must indicate that the claim could be correct but not necessarily so (oe).
If M0 then SC1 for LB = 144.375 and UB = 157.275 (using 13 for \(\det\mathbf{N}\)).
M1: Sufficient working to demonstrate knowledge of scalar multiplication of a matrix and subtraction of matrices. Can be implied by 3 out of 4 entries correct.
\(\begin{pmatrix} 4 & -3 \\ -2 & 2 \end{pmatrix}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} 7 \\ 9 \end{pmatrix}\)
M1
1.1
\(\dfrac{1}{2}\begin{pmatrix} 2 & 3 \\ 2 & 4 \end{pmatrix}\begin{pmatrix} 7 \\ 9 \end{pmatrix}\) or \(\mathbf{A}^{-1}\begin{pmatrix} 7 \\ 9 \end{pmatrix}\) if \(\mathbf{A}^{-1}\) defined
M1
1.1
so \(x = \dfrac{41}{2},\ y = 25\)
A1
1.1
[3]
Notes
M1:DR Expressing the system in matrix form. Can be implied by the next line. Matrix method must be used. Any other method 0/3.
M1: Forming correct solution as matrix/vector product with inverse matrix. FT their \(\det\mathbf{A}\) from (c). Except for this, inverse must be correct.
A1: \(20\frac{1}{2}\) or 20.5 Condone \(\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} \frac{41}{2} \\ 25 \end{pmatrix}\) but not \(\begin{pmatrix} x \\ y \end{pmatrix} = \frac{1}{2}\begin{pmatrix} 41 \\ 50 \end{pmatrix}\)
M1: Correctly using the inverse matrix: \((\mathbf{r} =)\ \mathbf{A}^{-1}\mathbf{b}\). It must be clear that a matrix method is being used. Can be incorrect inverse for M1 Allow M1 for expressions of the form \(\mathbf{A}^{-1}\mathbf{b}\)
A1*dep: Could be seen in vector form but \(x\), \(y\) and \(z\) must be appropriately seen. Correct answer with no matrix forms shown (with or without other working) is 0/4. Need to have earned the B1
9 Matrix \(\mathbf{R}\) is given by \(\mathbf{R} = \begin{pmatrix} a & 0 & -b \\ 0 & 1 & 0 \\ b & 0 & a \end{pmatrix}\) where \(a\) and \(b\) are constants.
(a) Find \(\mathbf{R}^2\) in terms of \(a\) and \(b\). [2]
The constants \(a\) and \(b\) are given by \(a = \dfrac{\sqrt{2}}{4}(\sqrt{3} + 1)\) and \(b = \dfrac{\sqrt{2}}{4}(\sqrt{3} - 1)\).
(b) By determining exact expressions for \(ab\) and \(a^2 - b^2\) and using the result from part (a), show that \[\mathbf{R}^2 = k\begin{pmatrix} \sqrt{3} & 0 & -1 \\ 0 & 2 & 0 \\ 1 & 0 & \sqrt{3} \end{pmatrix}\] where \(k\) is a real number whose value is to be determined. [2]
(c) Find \(\mathbf{R}^6\), \(\mathbf{R}^{12}\) and \(\mathbf{R}^{24}\). [3]
(d) Describe fully the transformation represented by \(\mathbf{R}\). [3]
Mark scheme (a)
Scheme
Marks
AO
\(\begin{pmatrix} a & 0 & -b \\ 0 & 1 & 0 \\ b & 0 & a \end{pmatrix}\begin{pmatrix} a & 0 & -b \\ 0 & 1 & 0 \\ b & 0 & a \end{pmatrix}\) \(= \begin{pmatrix} a \times a + -b \times b & 0 & -ab - ab \\ 0 & 0 + 1 \times 1 + 0 & 0 \\ ab + ab & 0 & -b \times b + a \times a \end{pmatrix}\)
B1: (1st) Explicitly finding an expression for either \(ab\) (or \(2ab\)) or \(a^2 - b^2\)
B1: (2nd) AG. Explicitly finding the expression for the other substituting into expression for \(\mathbf{R}^2\) (or carrying out the matrix multiplication again). \(k\) can be embedded. If \(k\) embedded need to see \(\frac{1}{2} \times 2\) or \(\frac{2}{2}\).
\(\mathbf{R}^4\): For reference – does not need to be seen in working.
SC – if answers left in terms of k then award B1 if one or two correct and B2 if all three correct
B1: (1st) For correct \(\mathbf{R}^6\) By calculator expected, so intermediate steps might not be shown.
B1: (2nd) For correct \(\mathbf{R}^{12}\)
B1: (3rd) For correct \(\mathbf{R}^{24}\)
Mark scheme (d)
Scheme
Marks
AO
Rotation
B1
3.1a
\((360^\circ/24 =)\ 15^\circ\)
B1
2.2a
Clockwise about the \(y\)-axis.
B1
3.2a
[3]
Notes
B1: (2nd) Also allow \(345^\circ\) (Rotation in opposite sense) Also allow in radians \(\frac{\pi}{12}\)
B1: (3rd) Both sense and axis must be correct. Could be a rotation of \(345^\circ\) anticlockwise about \(y\)-axis If correct transformation is combined with an incorrect one (such as correct rotation combined with a reflection) then maximum mark is B2.
8 The points \(P\), \(Q\) and \(R\) have coordinates \((0, 2, 3)\), \((2, 0, 1)\) and \((1, 3, 0)\) respectively.
The acute angle between the line segments \(PQ\) and \(PR\) is \(\theta\).
(a) Show that \(\sin\theta = \dfrac{2}{11}\sqrt{22}\). [3]
The triangle \(PQR\) lies in the plane \(\Pi\).
(b) Determine an equation for \(\Pi\), giving your answer in the form \(ax + by + cz = d\), where \(a\), \(b\), \(c\) and \(d\) are integers. [3]
The point \(S\) has coordinates \((5, 3, -1)\).
(c) By finding the shortest distance between \(S\) and the plane \(\Pi\), show that the volume of the tetrahedron \(PQRS\) is \(\dfrac{14}{3}\). [The volume of a tetrahedron is \(\dfrac{1}{3} \times \text{area of base} \times \text{perpendicular height}\)] [4]
The tetrahedron \(PQRS\) is transformed to the tetrahedron \(P^{\prime}Q^{\prime}R^{\prime}S^{\prime}\) by a rotation about the \(y\)-axis.
The \(x\)-coordinate of \(S^{\prime}\) is \(2\sqrt{2}\).
(d) By using the matrix for a rotation by angle \(\theta\) about the \(y\)-axis, as given in the Formulae Booklet, determine in exact form the possible coordinates of \(R^{\prime}\). [5]
M1: Correct use of vector product to find \(|\sin\theta|\) including correct method for magnitudes, and correct method for \(\begin{pmatrix} 2 \\ -2 \\ -2 \end{pmatrix} \times \begin{pmatrix} 1 \\ 1 \\ -3 \end{pmatrix}\) soi. Condone \(\sin\theta\) instead of \(|\sin\theta|\)
M1: Uses the formula given in formula book, or any other complete method for the shortest distance, fttheir \(\overrightarrow{PQ} \times \overrightarrow{PR}\).
A1: Correct shortest distance.
M1: Uses \(\frac{1}{2}\left|\overrightarrow{PQ}\right|\left|\overrightarrow{PR}\right|\sin\theta\) oe, multiplied by their D/3, or \(\frac{1}{2}\left|\begin{pmatrix} 2 \\ -2 \\ -2 \end{pmatrix} \times \begin{pmatrix} 1 \\ 1 \\ -3 \end{pmatrix}\right|\) multiplied by their D/3, but must indicate that \(\frac{1}{2}\left|\begin{pmatrix} 2 \\ -2 \\ -2 \end{pmatrix} \times \begin{pmatrix} 1 \\ 1 \\ -3 \end{pmatrix}\right|\) is the area of the base.
M1: For rotation matrix multiplied by \(\overrightarrow{OR}\) or \(\overrightarrow{OS}\).
M1: For a correct step to form quadratic equation in \(\sin\phi\) or \(\cos\phi\) only. For reference: \(26\sin^2\phi + 4\sqrt{2}\sin\phi - 17 = 0\)
A1: Solves quadratic equation in \(\sin\phi\) or \(\cos\phi\). (Exact answers required)
M1: Uses their \(\sin\phi\) or \(\cos\phi\) with \(5\cos\phi - \sin\phi = 2\sqrt{2}\) to find \(\cos\phi\) or \(\sin\phi\) respectively, (even if only one root) or from \(\sin\phi = \sqrt{1 - \cos^2\phi}\) or \(\cos\phi = \sqrt{1 - \sin^2\phi}\) (condone inclusion of \(\pm\)), or repeats previous method and multiplies out the matrices.
A1: For both, and no others. Accept given as \(\overrightarrow{OR^{\prime}}\). If M0M0A0M0A0, SCB1 for any \(R^{\prime}\) with \(y\)-coordinate \(= 3\), and no other \(y\)-coordinates.
M1: For rotation matrix multiplied by \(\overrightarrow{OR}\) or \(\overrightarrow{OS}\).
M1: Expressing in the form \(R\cos(\phi + \alpha)\) or \(R\sin(\phi + \alpha)\) oe. Note that \(5\cos\phi - \sin\phi = \sqrt{26}\sin\left(\phi + \arctan\left(-\frac{1}{5}\right) + \pi\right)\)
A1: Solves for \(\sin\phi\) or \(\cos\phi\). For reference, \(\frac{\sqrt{2}}{2} \approx 0.707\), \(-\frac{17\sqrt{2}}{26} \approx -0.925\) and \(\frac{7\sqrt{2}}{26} \approx 0.381\).
7In this question you must show detailed reasoning.
Matrix \(\mathbf{A}\) is given by \(\mathbf{A} = \begin{pmatrix} a & -6 & a - 3 \\ a + 9 & a & 4 \\ 0 & -13 & a - 1 \end{pmatrix}\) where \(a\) is a constant.
Find all possible values of \(a\) for which \(\det\mathbf{A}\) has the same value as it has when \(a = 2\). [6]
M1: Attempt to expand the determinant. If using standard method must see at least two terms, at least one of which comprises \(\pm\) a number multiplied by the residual determinant. eg \(a(a(a - 1) - 4 \times (-13)) - (a + 9)((-6)(a - 1) - (a - 3)(-13))\) This mark can be awarded with \(a = 2\) substituted (ie attempt to find \(\begin{vmatrix} 2 & -6 & -1 \\ 11 & 2 & 4 \\ 0 & -13 & 1 \end{vmatrix}\)) but working must be shown. eg \(2(2 + 52) - 11(-6 - 13)\) \((= 317)\) Allow other correct methods.
M1: Setting up equation equating their determinant to their specific determinant value for \(a = 2\)
M1: Rearranging to = 0 and use of factor theorem to derive a quadratic equation in \(a\) by dividing by \((a - 2)\) Need some evidence of how to solve cubic (Not just cubic written and then roots BC). Need to see =0 on one side of cubic (but it might disappear after this, e.g. when dividing by \((a - 2)\))
A1: Both. No need to mention \(a = 2\) Don’t need to see “\(a =\)” explicitly SC – if third and/or fourth method mark not awarded then allow SC B1 for sight of \(3 \pm \mathrm{i}\).
M1: For \(\mathbf{A}^4 = \mathbf{I}\) or \(\mathrm{T_A}\) repeated four times is a 360 degree rotation. Condone clockwise instead of anticlockwise for \(\mathrm{T_A}\) so notes that 423 is divisible by 4 with remainder 3 so \(\mathbf{A}^{423} = \mathbf{A}^3\)
A1: As \(\mathbf{A}^3\) represents a 270 degrees rotation anti-clockwise (or 90 degrees clockwise) or by direct calculation of \(\mathbf{A}^3\).
(a) The matrix \(\mathbf{P}\) is given by \(\mathbf{P} = \begin{pmatrix} 1 & 0 & -2 & 2 \\ 4 & 2 & -2 & 3 \end{pmatrix}\).
(i) Write down the dimensions of \(\mathbf{P}\). [1]
(ii) Write down the transpose of \(\mathbf{P}\). [1]
(b) The matrices \(\mathbf{Q}\), \(\mathbf{R}\) and \(\mathbf{S}\) are given by \(\mathbf{Q} = \begin{pmatrix} 1 & 2 \end{pmatrix}\), \(\mathbf{R} = \begin{pmatrix} 3 & -4 \\ 2 & 3 \end{pmatrix}\) and \(\mathbf{S} = \begin{pmatrix} 3 & -2 \end{pmatrix}\).
Write down the sum of the two of these matrices which are conformable for addition. [1]
(c) The dimensions of matrix \(\mathbf{A}\) are 4 by 5. The matrices \(\mathbf{A}\) and \(\mathbf{B}\) are conformable for multiplication so that the matrix \(\mathbf{C} = \mathbf{BA}\) can be formed. The matrix \(\mathbf{C}\) has 6 rows.
(i) Write down the number of columns that \(\mathbf{C}\) has. [1]
(ii) Write down the dimensions of \(\mathbf{B}\). [1]
(iii) Explain whether the matrix \(\mathbf{AB}\) can be formed. [1]
(d) Find the value of \(c\) for which \(\begin{pmatrix} -2 & 3 \\ 6 & 10 \end{pmatrix}\begin{pmatrix} c & 5 \\ 10 & 13 \end{pmatrix} = \begin{pmatrix} c & 5 \\ 10 & 13 \end{pmatrix}\begin{pmatrix} -2 & 3 \\ 6 & 10 \end{pmatrix}\). [2]
(iii) No because the number of columns in \(\mathbf{A}\) (is 5 which) is not equal to the number of rows in matrix \(\mathbf{B}\) (which is 6) (and for the matrices to be conformable these have to be the same.)
B1
2.4
[1]
Notes
(c)(iii)
B1: Must include “number of” oe. If numbers used, must have a word to imply comparison (eg “while”, “but” rather than “and”) Accept \((4 \times 5) \times (6 \times 4)\) and “\(5 \neq 6\)”; numbers given must be correct
\(6c + 100 = 58\) or \(3c + 50 = 29 \Rightarrow c = -7\)
A1
1.1
[2]
Notes
M1: Attempt at multiplication in both directions sufficient to obtain one pair of equivalent entries in trailing diagonal. Can be implied by correct linear equation
*M1: Correctly finding at least 5 cofactors or minors (need not be in matrix)
dep*M1: Transposing and changing signs in correct way
A1FT: FT their determinant
M1: Forming correct product and attempting multiplication, resulting in a vector
A1: Simplification to correct numerical solution (can be left as an unmultiplied vector) i.e. A1 can be awarded for \(\begin{pmatrix} \frac{9}{5} \\ 0 \\ -\frac{2}{5} \end{pmatrix}\)
Scheme
Marks
AO
(ii) Singular when \(\det\mathbf{A} = 0 \Rightarrow a = 4\) so the second equation is \(-3x - 6y + 9z = -9\)…
M1
2.1
…which has the same normal (direction) as the first equation and is consistent with it… oe
M1
1.1
…so the first two planes are identical and the third intersects them in a line.
A1
2.4
[3]
Notes
M1: Finding \(a\) from \(\det\mathbf{A} = 0\) and subbing in to 2nd equation. Could just find the appropriate normal
M1: eg The second equation is a multiple of the first.
Mark scheme (c)
Scheme
Marks
AO
(i) Orientation reversed if \(\det\mathbf{A} \lt 0\) so \(200(4 - a) \lt 0\) so \(a \gt 4\)
B1FT
3.1a
[1]
Notes
B1FT: Must be strict inequality FT their expression for determinant if linear function of \(a\).
Scheme
Marks
AO
(ii) Image volume smaller than object volume \(\Rightarrow -1 \lt \det\mathbf{A} \lt 1\)…
M1
3.1a
… but \(a \neq 4\) so \(\dfrac{799}{200} \lt a \lt 4\) or \(4 \lt a \lt \dfrac{801}{200}\) oe
A1
3.2a
[2]
Notes
M1: Understanding that \(|\det\mathbf{A}|\) represents the volume scale factor and so \(|\det\mathbf{A}| \lt 1\)…
A1: …and that \(a \neq 4\). Must be strict inequalities \(\dfrac{799}{200} \lt a \lt \dfrac{801}{200}\) and \(a \neq 4\)
6 The matrix \(\mathbf{A}\) is given by \(\mathbf{A} = \dfrac{1}{13}\begin{pmatrix} 5 & 12 \\ 12 & -5 \end{pmatrix}\).
You are given that \(\mathbf{A}\) represents the transformation T which is a reflection in a certain straight line. You are also given that this straight line, the mirror line, passes through the origin, \(O\).
(a) Explain why there must be a line of invariant points for T. State the geometric significance of this line. [2]
(b) By considering the line of invariant points for T, determine the equation of the mirror line. Give your answer in the form \(y = mx + c\). [4]
The coordinates of the point \(P\) are \((1, 5)\).
(c) By considering the image of \(P\) under the transformation T, or otherwise, determine the coordinates of the point on the mirror line which is closest to \(P\). [3]
(d) The line with equation \(y = ax + 2\) is an invariant line for T. Determine the value of \(a\). [2]
Mark scheme (a)
Scheme
Marks
AO
T is a reflection (in 2-D) and in any reflection any point on the mirror line remains invariant...
B1
2.4
...and so the mirror line must itself be a line of invariant points.
B1
2.2a
[2]
Notes
B1: (1st) Any point on the mirror line stays where it is...
B1: (2nd) ...so the mirror line is a line of invariant points. Accept “so the line of invariant points is the mirror line” If B0B0 then SC1 for any answer which is, in effect, a statement that the mirror line is an invariant line.
Mark scheme (b)
Scheme
Marks
AO
For line of invariant points \(\mathbf{Ar} = \mathbf{r}\)
Either we have \(m = \frac{-3}{2}\), and \(c\) can be anything or \(m = \frac{2}{3}\) and we have \(c = 0\).
A1
This gives a single line and infinitely many which are perpendicular to it. Therefore the reflection line is the single line (and the perpendicular ones are invariant lines). Hence we have \(m = \frac{2}{3}\) and so \(y = \frac{2}{3}x\)
A1
M1: (1st) Considering the matrix acting on a general point on the line \(y = mx + c\)
M1: (2nd) Multiplying and substituting into \(y = mx + c\)
A1: (1st) Finding two correct values of \(m\) and no others (linking to \(c\) not necessary here)
A1: (2nd) Convincing reason why \(m = -3/2\) is rejected as a possibility.
2 The matrix \(\mathbf{A}\) is given by \(\mathbf{A} = \begin{pmatrix} 2 & -2 \\ 1 & 3 \end{pmatrix}\).
(a) Calculate \(\det\mathbf{A}\). [1]
(b) Write down \(\mathbf{A}^{-1}\). [1]
(c) Hence solve the equation \(\mathbf{A}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} -1 \\ 2 \end{pmatrix}\). [2]
(d) Write down the matrix \(\mathbf{B}\) such that \(\mathbf{AB} = 4\mathbf{I}\). [1]
Matrices \(\mathbf{C}\) and \(\mathbf{D}\) are given by \(\mathbf{C} = \begin{pmatrix} 2 \\ 0 \\ 1 \end{pmatrix}\) and \(\mathbf{D} = \begin{pmatrix} 0 & 2 & p \end{pmatrix}\) where \(p\) is a constant.
(e) Find, in terms of \(p\),
the matrix \(\mathbf{CD}\)
the matrix \(\mathbf{DC}\).
[3]
It is observed that \(\mathbf{CD} \neq \mathbf{DC}\).
(f) The result that \(\mathbf{CD} \neq \mathbf{DC}\) is a counter example to the claim that matrix multiplication has a particular property. Name this property. [1]
2 Matrices \(\mathbf{A}\) and \(\mathbf{B}\) are given by \(\mathbf{A} = \begin{pmatrix} a & 1 \\ -1 & 3 \end{pmatrix}\) and \(\mathbf{B} = \begin{pmatrix} -2 & 5 \\ -1 & 0 \end{pmatrix}\) where \(a\) is a constant.
(a) Find the following matrices.
\(\mathbf{A} + \mathbf{B}\)
\(\mathbf{AB}\)
\(\mathbf{A}^2\) [3]
(b)
(i) Given that the determinant of \(\mathbf{A}\) is 25 find the value of \(a\). [2]
(ii) You are given instead that the following system of equations does not have a unique solution.\[\begin{aligned} ax + y &= -2 \\ -x + 3y &= -6 \end{aligned}\]Determine the value of \(a\). [2]
\(\mathbf{A}^2 = \begin{pmatrix} a^2 - 1 & a + 3 \\ -a - 3 & 8 \end{pmatrix}\)
B1
1.1
[3]
Notes
Any double signs must be simplified correctly
Mark scheme (b)
Scheme
Marks
AO
(i) \((\det\mathbf{A}) = a \times 3 - 1 \times -1\)
M1
1.1
\(3a + 1 = 25 \Rightarrow a = 8\)
A1
1.1
[2]
(ii) (System reduces to \(\mathbf{A}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} -2 \\ -6 \end{pmatrix}\) so no unique solution \(\Rightarrow\)) \((\det\mathbf{A}) = 3a + 1 = 0\)
M1
3.1a
\(\therefore a = -\tfrac{1}{3}\)
A1
1.1
[2]
Notes
(b)(i)
M1: Correct expansion of determinant of \(\mathbf{A}\)
(b)(ii)
M1: Setting their determinant to 0 if it is a linear function of \(a\). Answer only is ok here
(b)(ii) Alternate solution
Scheme
Marks
Multiplying the first equation by 3 gives: \(3ax + 3y = -6\) \(-x + 3y = -6\)
M1
These two equations are the same if \(3a = -1 \to a = \dfrac{-1}{3}\)
A1
A1: Or subtracting gives \((3a + 1)x = 0 \to a = \frac{-1}{3}\)
A1: Value of \(k\) can be implied by the correct equation
Mark scheme (b)
Scheme
Marks
AO
\(\begin{pmatrix} 2 & 1 \\ -1 & 0 \end{pmatrix}\begin{pmatrix} x \\ -x \end{pmatrix} = \begin{pmatrix} 2x - x \\ -x \end{pmatrix} = \begin{pmatrix} x \\ -x \end{pmatrix}\) so each point maps to itself and it is a line of invariant points
B1
2.4
[1]
Notes
B1: Must have a reason e.g. it is sufficient to test one point other than \((0, 0)\)
9 The matrix \(\mathbf{A}\) is given by \(\mathbf{A} = \begin{pmatrix} 2 & 3 \\ 0 & 2 \end{pmatrix}\).
(a) By considering \(\mathbf{A}\), \(\mathbf{A}^2\), \(\mathbf{A}^3\) and \(\mathbf{A}^4\) make a conjecture about the form of the matrix \(\mathbf{A}^n\) in terms of \(n\) for \(n \geqslant 1\). [2]
(b) Use induction to prove the conjecture made in part (a). [4]
\(= \begin{pmatrix} 2^{k+1} & 3(k + 1) \times 2^k \\ 0 & 2^{k+1} \end{pmatrix}\) So true for \(n = k \Rightarrow\) true for \(n = k + 1\). But true for \(n = 1\). So true for all positive integer \(n\)
A1
2.4
[4]
Notes
B1: Allow this mark even if the conjecture is wrong, provided that it works for \(n = 1\)
M1: (first) Must have statement in terms of some other variable than \(n\). Conjecture need not be correct.
A1: AG. Manipulating terms correctly and convincingly to obtain required form. Some intermediate working must be seen and a clear conclusion must be given for the induction process. A formal proof by induction is required for full marks.
M1: (1st) Correct process for expanding determinant. Fully expanded form: \(2t^3 + 7t^2 - 14t + 5\)
M1: (2nd) Bringing \((t - 1)\) or \((t + 5)\) or \((2t - 1)\) oe out as factor of the entire expression Factors may appear BC from no working
Mark scheme (b)
Scheme
Marks
AO
\(-5,\ \tfrac{1}{2},\ 1\)
B1
1.1
[1]
Notes
B1: FT their complete factorisation of determinant into 3 linear factors.
Mark scheme (c)
Scheme
Marks
AO
\(t = b^2 + 2\)
M1
2.1
and so \(t \geqslant 2\) so cannot be \(-5\), \(\tfrac{1}{2}\) or 1 therefore \(\mathbf{A}^{-1}\) will exist (for all values of \(b\)) and so there will be a unique solution to the system for all values of \(b\).
A1
2.4
[2]
Notes
M1: So that the system is \(\mathbf{Ar} = \mathbf{c}\)
A1: Complete reasoning must be seen for A1. Could test \(t = 1, \tfrac{1}{2}, -5\) in \(b^2 = t - 2\), and show that these do not give real values of \(b\)
6In this question you must show detailed reasoning.
The matrix \(\mathbf{A}\) is given by \(\mathbf{A} = \begin{pmatrix} 1 & 2 \\ 0 & 1 \end{pmatrix}\).
(a) Define the transformation represented by \(\mathbf{A}\). [1]
(b) Show that the area of any object shape is invariant under the transformation represented by \(\mathbf{A}\). [1]
The matrix \(\mathbf{B}\) is given by \(\mathbf{B} = \begin{pmatrix} 7 & 2 \\ 21 & 7 \end{pmatrix}\). You are given that \(\mathbf{B}\) represents the transformation which is the result of applying the following three transformations in the given order.
A shear which leaves the \(y\)-axis invariant and which transforms the point \((1, 1)\) to the point \((1, 4)\).
The transformation represented by \(\mathbf{A}\).
A stretch of scale factor \(p\) which leaves the \(x\)-axis invariant.
(c) Determine the value of \(p\). [4]
Mark scheme (a)
Scheme
Marks
AO
DR A shear which leaves the \(x\)-axis invariant and which transforms the point \((0, 1)\) to the point \((2, 1)\).
B1
2.2a
[1]
Notes
B1: Or any useful point transformed to its image not “scale factor” or sf
Mark scheme (b)
Scheme
Marks
AO
DR \(\det\mathbf{A} = 1 \times 1 - 0 \times 2 = 1\) and this is the area scale factor
B1
2.4
[1]
Notes
B1: Both Detailed calculation must be shown
Mark scheme (c)
Scheme
Marks
AO
DR \(\begin{pmatrix} 1 & 0 \\ 3 & 1 \end{pmatrix}\) seen
M1: Correct inverse of their rotation \(\mathrm{T_B}\). Could also be rotation of \(292.6^\circ\) anticlockwise
A1: or \(\mathbf{B}^{-1} = \begin{pmatrix} 0.385 & 0.923 \\ -0.923 & 0.385 \end{pmatrix}\) (allow 0.384 for 0.385) NB: Question states “by considering the inverse transformation”. SC1 For correct inverse by other method.
Mark scheme (d)
Scheme
Marks
AO
\(\det\mathbf{B} = 1\) and \(\det\mathbf{C} = -3\)
M1
3.1a
So area of \(N = |1 \times -3| \times 5 = 15\)
A1
3.2a
[2]
Notes
M1: Could find \(\mathbf{BC}\) and then find \(\det(\mathbf{BC}) = -3\)
A1: Area must be 15, do not allow \(-15\) or \(\pm 15\)
\(-12 = -4a\) or \(-1 = 11 - 4a\) or \(7 - 6a = -8 - a\) or \(3a - 2 = 7\) or \(-4a - 5 = -17\)
M1
1.1
\(a = 3\)
A1
2.2a
[3]
Notes
M1: Either product AB or BA calculated (but not if assigned incorrectly). Alternatively: equivalent correct useful entries calculated for both Condone 3 errors or omissions This mark can be implied by sight of a correct equation
M1: Finding matrix products both ways and equating entries usefully This mark can be implied by sight of a correct equation even if other entries or equations are wrong.
A1: Cannot be awarded if either AB or BA has more than 3 errors
Since \(a^2b^2 = (ab)^2 \geqslant 0\) then \(a^2b^2 + 2 \gt 0\) for all values of \(a\) and \(b\) the determinant of the matrix cannot be 0 (so the matrix is never singular)
B1
2.4
so the inverse always exists and the method always works.
B1
2.4
[2]
Notes
B1: (1st) Argument must be complete and correct. eg \(a^2b^2 + 2 \geqslant 0\) is B0.
P is a reflection in the \(x\)-axis. \(\mathbf{A}\) is the matrix that represents P.
(a) Write down the matrix \(\mathbf{A}\). [1]
Q is a shear in which the \(y\)-axis is invariant and the point \(\begin{pmatrix} 1 \\ 0 \end{pmatrix}\) is transformed to the point \(\begin{pmatrix} 1 \\ 2 \end{pmatrix}\). \(\mathbf{B}\) is the matrix that represents Q.
(b) Find the matrix \(\mathbf{B}\). [2]
T is P followed by Q. \(\mathbf{C}\) is the matrix that represents T.
(c) Determine the matrix \(\mathbf{C}\). [2]
\(L\) is the line whose equation is \(y = x\).
(d) Explain whether or not \(L\) is a line of invariant points under T. [2]
An object parallelogram, \(M\), is transformed under T to an image parallelogram, \(N\).
(e) Explain what the value of the determinant of \(\mathbf{C}\) means about
the area of \(N\) compared to the area of \(M\),
the orientation of \(N\) compared to the orientation of \(M\). [3]
M1: Their \(\mathbf{A}\) and \(\mathbf{B}\) but must be the correct way round (ie \(\mathbf{BA}\), not \(\mathbf{AB}\)).
Mark scheme (d)
Scheme
Marks
AO
\(\begin{pmatrix} 1 & 0 \\ 2 & -1 \end{pmatrix}\begin{pmatrix} x \\ x \end{pmatrix} = \begin{pmatrix} x \\ x \end{pmatrix}\)
M1
3.1a
Since each point gets mapped to itself it is a line of invariant points
A1
2.2a
[2]
Notes
M1: Multiplying a correct vector (\(\begin{pmatrix} x \\ x \end{pmatrix}\) or \(\begin{pmatrix} y \\ y \end{pmatrix}\)) correctly into C. If a particular point (eg \((1, 1)\)) is used then supporting statement required for M1 that eg this must therefore apply on the line through \((0, 0)\) and \((1, 1)\).
A1: If M0 then SC1 for use of a particular point leading to correct conclusion (This can follow from an incorrect matrix, possibly to show that \(y = x\) is not a line of invariant points) Can use \(\begin{pmatrix} 1 & 0 \\ 2 & -1 \end{pmatrix}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} x \\ y \end{pmatrix}\) to deduce that \(x = y\).
A1: Simplification with sufficient working to establish truth for \(k + 1\) Must see at least one stage of working between expression for \(\mathbf{M}^k\mathbf{M}\) (or \(\mathbf{MM}^k\)) and required expression for \(\mathbf{M}^{k+1}\) (e.g.: \(\begin{pmatrix} 1 & 3(2 + 2 \times 2^{k+1} - 4) \\ 0 & 2^k \times 2 \end{pmatrix}\) \(= \begin{pmatrix} 1 & 3(2^{(k+2)} - 2) \\ 0 & 2^{(k+1)} \end{pmatrix}\)
E1: Clear conclusion for induction process. Needs a fully correct proof which usually means all other marks awarded. Cannot be awarded if there are mistakes in the proof. A formal proof by induction is required for full marks. SC If B1M1M1M1 gained, but A0 because of lack of intermediate step of working then allow SC B1 for fully correct ending statement
7 A transformation A is represented by the matrix \(\mathbf{A}\) where \(\mathbf{A} = \begin{pmatrix} -1 & x & 2 \\ 7 - x & -6 & 1 \\ 5 & -5x & 2x \end{pmatrix}\).
The tetrahedron \(H\) has vertices at \(O\), \(P\), \(Q\) and \(R\). The volume of \(H\) is 6 units.
\(P'\), \(Q'\), \(R'\) and \(H'\) are the images of \(P\), \(Q\), \(R\) and \(H\) under A.
(a) In the case where \(x = 5\)
find the volume of \(H'\),
determine whether A preserves the orientation of \(H\). [3]
(b) Find the values of \(x\) for which \(O\), \(P'\), \(Q'\) and \(R'\) are coplanar (i.e. the four points lie in the same plane). [4]
6 A transformation T is represented by the matrix \(\mathbf{T}\) where \(\mathbf{T} = \begin{pmatrix} x^2 + 1 & -4 \\ 3 - 2x^2 & x^2 + 5 \end{pmatrix}\).
A quadrilateral \(Q\), whose area is 12 units, is transformed by T to \(Q'\).
Find the smallest possible value of the area of \(Q'\). [5]
4 A 2-D transformation T is a shear which leaves the \(y\)-axis invariant and which transforms the object point \((2, 1)\) to the image point \((2, 9)\). \(\mathbf{A}\) is the matrix which represents the transformation T.
(a) Find \(\mathbf{A}\). [3]
(b) By considering the determinant of \(\mathbf{A}\), explain why the area of a shape is invariant under T. [2]
M1: Correctly multiplying object vector into their \(\mathbf{A}\) to find image and equating to given image. Their \(\mathbf{A}\) must have at least 1 unknown element
Mark scheme (b)
Scheme
Marks
AO
\(\det\mathbf{A} = 1 - 0 = 1\)
B1
1.1
The determinant is the area scale factor so a determinant of 1 leaves the area unchanged
B1
2.4
[2]
Notes
B1: Correctly finding determinant
B1: Convincing explanation. Must include both ideas.
2 Matrices \(\mathbf{P}\) and \(\mathbf{Q}\) are given by \(\mathbf{P} = \begin{pmatrix} 1 & k & 0 \\ -2 & 1 & 3 \end{pmatrix}\) and \(\mathbf{Q} = \begin{pmatrix} (1 + k) & -1 \end{pmatrix}\) where \(k\) is a constant.
Exactly one of statements A and B is true.
Statement A: \(\mathbf{P}\) and \(\mathbf{Q}\) (in that order) are conformable for multiplication. Statement B: \(\mathbf{Q}\) and \(\mathbf{P}\) (in that order) are conformable for multiplication.
(a) State, with a reason, which one of A and B is true. [2]
(b) Find either \(\mathbf{PQ}\) or \(\mathbf{QP}\) in terms of \(k\). [2]
Mark scheme (a)
Scheme
Marks
AO
B
B1
2.2a
(For matrices to be conformable for multiplication) the number of columns of the first must equal the number of rows in the second oe “the number of rows of P is equal to the number of columns of Q”
E1
1.2
[2]
Notes
B1: Note “B” is that QP is conformable
E1: Statement can be general or specific. Allow eg \((1 \times 2) \times (2 \times 3) = (1 \times 3)\) provided that it is clear which two numbers must be the same Since told exactly one is true it is sufficient to give a reason why one is true or why one is false
B1: (2nd) \(4a - 3c = 5\) Or det \(= -5\) and follow through
B1: (3rd) Understanding of invariant point seen or implied
M1: (1st) May have \(b = 3\) and/or \(d = 4\) already substituted \((1 - a)x = 3y\) or \(-3y = cx\)
M1: (2nd) Eliminating \(x\) and \(y\)
M1: (3rd) Attempting to solve their simultaneous equations If no working and incorrect then M0A0.
A1: (2nd) Condone \(a = 2\), etc as long as Matrix seen as \(\mathbf{A} = \begin{pmatrix} a & b \\ c & d \end{pmatrix}\)
Mark scheme (ii)
Scheme
Marks
AO
Need \(\begin{pmatrix} 3 & 1 \\ 2 & 2 \end{pmatrix}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} 3x + y \\ 2x + 2y \end{pmatrix} = \begin{pmatrix} x \\ y \end{pmatrix}\)
M1
1.1
\(2x + y = 0\)
A1
2.2a
[2]
Notes
M1: Substituting a general point into their matrix, calculating an image point and equating it to the object point.
A1: Final form must be \(y = -2x\) or \(x = -\tfrac{1}{2}y\) or a numerical multiple of \(2x + y = 0\). Need to have considered both \(x\) and \(y\) coordinates.
Mark scheme (iii)
Scheme
Marks
AO
\(\begin{pmatrix} 3 & 1 \\ 2 & 2 \end{pmatrix}\begin{pmatrix} x \\ x + c \end{pmatrix} = \begin{pmatrix} 3x + x + c \\ 2x + 2x + 2c \end{pmatrix}\)
M1*
3.1a
So \(\begin{pmatrix} X \\ Y \end{pmatrix} = \begin{pmatrix} 4x + c \\ 4x + 2c \end{pmatrix} \ldots\)
M1dep*
2.2a
\(\ldots\)and \(Y = X + c\)
A1
1.1
[3]
Notes
A1: Could see the \(y\) component of the vector written as \(4x + c + c\).
Alternative
Scheme
Marks
\(\begin{pmatrix} 3 & 1 \\ 2 & 2 \end{pmatrix}\begin{pmatrix} x \\ mx + c \end{pmatrix} = \begin{pmatrix} X \\ mX + c \end{pmatrix}\) \(3x + mx + c = X\) \(2x + 2mx + 2c = mX + c\) \(2x + 2mx + 2c = m(3x + mx + c) + c\)
6 The matrices \(\mathbf{A}\) and \(\mathbf{B}\) are given by \(\mathbf{A} = \begin{pmatrix} t & 6 \\ t & -2 \end{pmatrix}\) and \(\mathbf{B} = \begin{pmatrix} 2t & 4 \\ t & -2 \end{pmatrix}\) where \(t\) is a constant.
(i) Show that \(|\mathbf{A}| = |\mathbf{B}|\). [2]
(ii) Verify that \(|\mathbf{AB}| = |\mathbf{A}||\mathbf{B}|\). [3]
(iii) Given that \(|\mathbf{AB}| = -1\) explain what this means about the constant \(t\). [2]
A1: Both correct and statement of equality Need to have an indication that candidate understands that they have shown that these are equal. Could be done by re-writing \(|\mathbf{A}| = -8t\) immediately next to \(|\mathbf{B}| = -8t\). \(|\mathbf{A}| = |\mathbf{B}|\) is fine after having shown both are equal to \(-8t\), but \(-8t = -8t\) is not ok for the A mark.
M1: (1st) Must be attempt at proper matrix multiplication (i.e. columns into rows). Condone one error
M1: (2nd) Correct expression of determinant of their matrix. Condone one error
A1: Convincing expansion, correct answer and conclusion Similar to question above. Need candidate to conclude that \(|\mathbf{AB}| = |\mathbf{A}|\,|\mathbf{B}|\) Condone not seeing \((-8t)(-8t)\) explicitly
Mark scheme (iii)
Scheme
Marks
AO
Set their \(|\mathbf{AB}| = -1\) or \(|\mathbf{A}||\mathbf{A}| = |\mathbf{A}|^2 = -1\)
M1
3.1a
\(\Rightarrow 64t^2 = -1\) so \(t\) must be complex/imaginary/not real
A1ft
3.2a
[2]
Notes
M1: Seen or implied \(64t^2 = -1\) or \((-8t)^2 = -1\)
A1ft: Accept \(t = -\mathrm{i}/8\) or \(t = \mathrm{i}/8\) Allow follow through if their \(|\mathbf{AB}|\) is of the form \(kt^2\).
M1*: At least 4 co-factors correct, or correct apart from sign. Could be seen in separate calculations or in \(\mathbf{A}^{-1}\). Could be transposed, even if stated as matrix of cofactors. If ambiguity use \(\mathbf{A}^{-1}\). If \(\mathbf{A}^{-1}\) not given then make whichever assumption, transposed or not, which results in most marks. If not anywhere in matrix form only award M1 if it is clear where the cofactors come from. Cofactor must not be multiplied by anything Alternative method using cross product also ok. Matrix of cofactors is given by \((C_2 \times C_3, C_3 \times C_1\ C_1 \times C_2)\)
A1: (1st) 6 cofactors correct Must include correct sign.
M1dep*: Transposing matrix of cofactors and dividing by determinant
(a) By using the definition of \(\cosh x\) and \(\sinh x\) in terms of \(\mathrm{e}^x\) and \(\mathrm{e}^{-x}\), show that \(\cosh^2 x + \sinh^2 x \equiv \cosh 2x\). [2]
(b) The transformation T of the plane has associated matrix \(\mathbf{M}\), where \(\mathbf{M} = \begin{pmatrix} \cosh x & \sinh x \\ \sinh x & \cosh x \end{pmatrix}\) and \(x \gt 0\). Show that T transforms the unit square with coordinates \((0, 0)\), \((1, 0)\), \((0, 1)\) and \((1, 1)\) to a rhombus of unit area. [6]
(c) You are given that the length of each side of the rhombus is 2 units. Determine the exact value of \(x\). Give your answer in logarithmic form. [2]
Mark scheme (a)
Scheme
Marks
AO
\(\cosh^2 x + \sinh^2 x = \frac{1}{4}(\mathrm{e}^x + \mathrm{e}^{-x})^2 + \frac{1}{4}(\mathrm{e}^x - \mathrm{e}^{-x})^2\)
M1: LHS correctly written in exponential form. Must be seen.
A1:AG expanded and simplified to \(\frac{1}{2}(\mathrm{e}^{2x} + \mathrm{e}^{-2x})\) must be seen before final answer. Complete argument required, www.
Mark scheme (b)
Scheme
Marks
AO
\(\begin{pmatrix} \cosh x & \sinh x \\ \sinh x & \cosh x \end{pmatrix}\begin{pmatrix} 0 & 1 & 0 & 1 \\ 0 & 0 & 1 & 1 \end{pmatrix}\)
M1
2.1
\(= \begin{pmatrix} 0 & \cosh x & \sinh x & \cosh x + \sinh x \\ 0 & \sinh x & \cosh x & \cosh x + \sinh x \end{pmatrix}\)
A1
1.1
Suppose vertices are O, P, Q, R respectively \(\mathrm{OP}^2 = \mathrm{OQ}^2 = \cosh^2 x + \sinh^2 x\) \(\mathrm{PR}^2 = (\cosh x + \sinh x - \sinh x)^2 + (\cosh x + \sinh x - \cosh x)^2 = \cosh^2 x + \sinh^2 x\) \(\mathrm{QR}^2 = (\cosh x + \sinh x - \sinh x)^2 + (\cosh x + \sinh x - \cosh x)^2 = \cosh^2 x + \sinh^2 x\)
M1
3.1a
So \(\mathrm{OP} = \mathrm{OQ} = \mathrm{PR} = \mathrm{QR}\) so rhombus
A1
2.2a
\(\det\mathbf{M} = \cosh^2 x - \sinh^2 x\)
M1
2.1
\(= 1 \Rightarrow\) transformation preserves area, so area of rhombus is 1
A1
3.2a
[6]
Notes
M1: finding images by matrix multiplication or at least two correct images
A1: or all correct images found
M1: explicitly giving two side lengths of image or showing that there are two pairs of parallel sides. Lengths or their squares could be used.
A1: Complete method to show image is rhombus and concluding, e.g. showing all four sides are equal (working must be seen for PR and QR). Could also show there are two pairs of parallel sides and two adjacent sides are equal length; that P and Q are reflections in \(y = x\), R lies on \(y = x\) and OP = PR; that two diagonals are perpendicular bisectors of each other. Results must be shown not just stated.
M1: must be seen; or for a complete method to find area of image
A1: \(= 1\), and some comment about the effect of the transformation if det M used. Accept “[area scale] factor = 1”, “area stays same”, “area = \(1 \times 1 = 1\)” etc., but not just “so area = 1”.
Mark scheme (c)
Scheme
Marks
AO
\(2 = \sqrt{\cosh^2 x + \sinh^2 x}\) or \(2 = \sqrt{\cosh 2x}\)
M1
3.1a
\(x = \dfrac{1}{2}\ln\left(4 + \sqrt{15}\right)\)
A1
1.1
[2]
Notes
M1: or \(4 = \cosh^2 x + \sinh^2 x\) or \(4 = \cosh 2x\) oe
A1: oe e.g. \(x = \ln\left(\frac{\sqrt{5} + \sqrt{3}}{\sqrt{2}}\right)\). Do not condone missing brackets. Answer must be supported by some working. ISW if error manipulating logs only.
(a) You are given that \(\mathbf{M}\) and \(\mathbf{N}\) are non-singular \(2 \times 2\) matrices. Write down the product rule for the inverse matrices of \(\mathbf{M}\), \(\mathbf{N}\) and \(\mathbf{MN}\). [1]
(b) Verify this rule for the matrices \(\mathbf{M}\) and \(\mathbf{N}\), where \(\mathbf{M} = \begin{pmatrix} a & 1 \\ 0 & 1 \end{pmatrix}\) and \(\mathbf{N} = \begin{pmatrix} 0 & -1 \\ 1 & b \end{pmatrix}\) and \(a\) and \(b\) are non-zero constants. [6]
\(\mathbf{MN} = \begin{pmatrix} 1 & b - a \\ 1 & b \end{pmatrix}\)
B1
1.1
\((\mathbf{MN})^{-1} = \frac{1}{a}\begin{pmatrix} b & a - b \\ -1 & 1 \end{pmatrix}\)
B1
1.1
\(\mathbf{N}^{-1}\mathbf{M}^{-1} = \frac{1}{a}\begin{pmatrix} b & 1 \\ -1 & 0 \end{pmatrix}\begin{pmatrix} 1 & -1 \\ 0 & a \end{pmatrix} = \frac{1}{a}\begin{pmatrix} b & a - b \\ -1 & 1 \end{pmatrix}\)
B1
2.2a
[6]
Notes
B1: it must be unambiguous which matrix is which for each mark to be awarded
B1 (\(\mathbf{MN}\)): Allow \(\mathbf{NM} = \begin{pmatrix} 0 & -1 \\ a & b + 1 \end{pmatrix}\) if \((\mathbf{NM})^{-1} = \mathbf{M}^{-1}\mathbf{N}^{-1}\) given in part (a)
B1 (\((\mathbf{MN})^{-1}\)): may be unsimplified. Allow \((\mathbf{NM})^{-1} = \frac{1}{a}\begin{pmatrix} b + 1 & 1 \\ -a & 0 \end{pmatrix}\) if \((\mathbf{NM})^{-1} = \mathbf{M}^{-1}\mathbf{N}^{-1}\) given in part (a)
B1 (\(\mathbf{N}^{-1}\mathbf{M}^{-1}\)): product of two matrices must be seen. Allow \(\mathbf{M}^{-1}\mathbf{N}^{-1} = \frac{1}{a}\begin{pmatrix} 1 & -1 \\ 0 & a \end{pmatrix}\begin{pmatrix} b & 1 \\ -1 & 0 \end{pmatrix} = \frac{1}{a}\begin{pmatrix} b + 1 & 1 \\ -a & 0 \end{pmatrix}\) if \((\mathbf{NM})^{-1} = \mathbf{M}^{-1}\mathbf{N}^{-1}\) given in part (a).
(a) The transformation T is represented by the matrix \(\mathbf{M} = \begin{pmatrix} 1 & -2 & 2 \\ 2 & 1 & 0 \\ 1 & 2 & -1 \end{pmatrix}\). A shape \(\mathrm{S_1}\) is mapped to a shape \(\mathrm{S_2}\) by the transformation T. Show that volume of \(\mathrm{S_1}\) is the same as the volume of \(\mathrm{S_2}\). [2]
(b) Three planes have equations\[\begin{aligned} x - 2y + 2z &= \lambda, \\ 2x + y \phantom{{}+2z} &= 2, \\ x + 2y - z &= 0, \end{aligned}\]where \(\lambda\) is a constant.
(i) Explain why the three planes intersect at a point for any value of \(\lambda\). [2]
(ii) Use a matrix method to determine, in terms of \(\lambda\), the coordinates of this point. [4]
Mark scheme (a)
Scheme
Marks
AO
\(\det\mathbf{M} = 1\)
M1
1.1
\(\Rightarrow\) T preserves volumes as \(\det\mathbf{M}\) is the volume scale factor
A1
1.2
[2]
Notes
M1: calculating \(\det\mathbf{M}\) (BC)
A1: \(=1\) and conclusion (must mention scale factor or equivalent) if ‘area’ instead of ‘volume’ then A0
Mark scheme (b)
Scheme
Marks
AO
(i) Matrix of coeffs is \(\mathbf{M}\)
M1
1.1
Det \(\mathbf{M} = 1 \Rightarrow \mathbf{M}\) is non-singular [so planes meet at a point]
A1
2.4
[2]
(ii) \(\mathbf{M}\begin{pmatrix} x \\ y \\ z \end{pmatrix} = \begin{pmatrix} \lambda \\ 2 \\ 0 \end{pmatrix}\ \left[\Rightarrow \begin{pmatrix} x \\ y \\ z \end{pmatrix} = \mathbf{M}^{-1}\begin{pmatrix} \lambda \\ 2 \\ 0 \end{pmatrix}\right]\)
\(\Rightarrow\) Point of intersection is \((-\lambda + 4, 2\lambda - 6, 3\lambda - 8)\)
A1
1.1
[4]
Notes
(b)(i)
M1: soi
A1: or \(\det\mathbf{M} \ne 0\), or \(\mathbf{M}^{-1}\) exists Allow SC2 for fully correct algebraic derivations of the point of intersection \((-\lambda + 4, 2\lambda - 6, 3\lambda - 8)\).
(b)(ii)
M1: translate to vector equation (soi)
B1: Correct inverse
M1: Attempt to multiply \(\mathbf{M}^{-1}\) by \(\begin{pmatrix} \lambda \\ 2 \\ 0 \end{pmatrix}\)
A1: accept in vector form matrix working may be shown in part (b)(i)
3 The matrices \(\mathbf{M}\) and \(\mathbf{N}\) are given by
\(\mathbf{M} = \begin{pmatrix} a & -b \\ b & a \end{pmatrix}\) and \(\mathbf{N} = \begin{pmatrix} b & -a \\ a & b \end{pmatrix}\) where \(a\) and \(b\) are positive constants.
(a) Given that \(\mathbf{M}^2 = \mathbf{N}\), determine the exact values of \(a\) and \(b\). [4]
(b) Hence state the transformations of the plane associated with matrices \(\mathbf{M}\) and \(\mathbf{N}\). [3]
M1: A correct method to find the determinant, allow one slip. Must contain a sum of three terms.
A1: Could be implied by \(k = -1\) if working with \(\det\mathbf{M} = 0\)
A1: Must make it clear that the planes do meet at a point for all values of \(k\) other than \(-1\). Do not accept “solution” for “point”. SC B2 if \(5k + 5\) found without working and a correct conclusion given.
Alternative method
Scheme
Marks
\(x = \dfrac{-2k^2 + 15k + 17}{5k + 5},\ y = \dfrac{-7 - 7k}{5k + 5},\ z = \dfrac{3k^2 - k - 4}{5k + 5}\)
B2*
Undefined when \(k = -1\)
B1dep
So planes meet at a point except when \(k = -1\)
B1
[4]
B2*: Correctly finding \(x\), \(y\) or \(z\) in terms of \(k\) using simultaneous equations
B1: www. Must make it clear that the planes do meet at a point for all values of \(k\) other than \(-1\). Do not accept “solution” for “point”. All three previous marks must have been awarded.
(a) Specify fully the transformation T of the plane associated with the matrix \(\mathbf{M}\), where \(\mathbf{M} = \begin{pmatrix} 1 & \lambda \\ 0 & 1 \end{pmatrix}\) and \(\lambda\) is a non-zero constant. [2]
(b)
(i) Find \(\det\mathbf{M}\). [1]
(ii) Deduce two properties of the transformation T from the value of \(\det\mathbf{M}\). [2]
(c) Prove that \(\mathbf{M}^n = \begin{pmatrix} 1 & n\lambda \\ 0 & 1 \end{pmatrix}\), where \(n\) is a positive integer. [4]
(d) Hence specify fully a single transformation which is equivalent to \(n\) applications of the transformation T. [1]
Mark scheme (a)
Scheme
Marks
AO
Shear
M1
1.2
with \(x\)-axis fixed, mapping (0, 1) to (\(\lambda\), 1)
A1
1.1
[2]
Notes
M1: Do not accept “sheaf”
A1: Accept \(x\)-axis is a line of invariant points (not an invariant line only). “Shear parallel to \(x\)-axis” is insufficient. Accept alternative mappings, e.g. \((1, 1)\) to \((1 + \lambda, 1)\). Do not accept shear factor.
Mark scheme (b)
Scheme
Marks
AO
(i) 1
B1
1.1
[1]
(ii) Preserves area
B1
1.2
Preserves orientation
B1
1.2
[2]
Notes
(b)(ii)
B1: FT their determinant. Condone area scale factor = 1.
B1: FT their determinant. Do not accept “orientation not reversed”.
So true for \(n = 1\) and if true for \(n = k\) then true for \(n = k + 1\), so true for all \(n\)
A1dep
2.4
[4]
Notes
B1: \(1 \times \lambda\) must be seen. “True when \(n = 1\)” could appear later.
M1: \(\mathbf{M}^{k+1} = \mathbf{M}^k\mathbf{M}\) or \(\mathbf{M}^{k+1} = \mathbf{M}\mathbf{M}^k\) could be used.
A1*: Required matrix with intermediate step seen
A1dep: \(n = 1\) must have been considered
Mark scheme (d)
Scheme
Marks
AO
A shear with \(x\)-axis fixed, mapping (0,1) to (\(n\lambda\), 1)
B1
1.1
[1]
Notes
B1: Accept \(x\)-axis is a line of invariant points (not an invariant line only). Accept alternative mappings, e.g. \((1, 1)\) to \((1 + n\lambda, 1)\). Do not accept shear factor
(a) For the case \(k = 0\), the origin lies on all three planes. Use a determinant to explain whether there are any other points that lie on all three planes in this case. [2]
(b) You are now given that \(k = 1\).
(i) Show that there are no points that lie on all three planes. [3]
(ii) Describe the geometrical arrangement of the three planes. [1]
6 You are given that \(\mathbf{M} = \begin{pmatrix} 4 & -9 \\ 1 & -2 \end{pmatrix}\).
(a) Prove that \(\mathbf{M}^n = \begin{pmatrix} 1 + 3n & -9n \\ n & 1 - 3n \end{pmatrix}\) for all positive integers \(n\). [6]
(b) A student thinks that this formula, when \(n = 0\) and \(n = -1\), gives the identity matrix and the inverse matrix \(\mathbf{M}^{-1}\) respectively. Determine whether the student is correct. [3]
2 The matrices \(\mathbf{A}\), \(\mathbf{B}\) and \(\mathbf{C}\) are given by \(\mathbf{A} = \begin{pmatrix} 1 & a \\ -1 & 2 \end{pmatrix}\), \(\mathbf{B} = \begin{pmatrix} 2 & 0 \\ 1 & -1 \end{pmatrix}\) and \(\mathbf{C} = \begin{pmatrix} -1 & 0 \\ 2 & 1 \end{pmatrix}\), where \(a\) is a constant.
(a) By multiplying out the matrices on both sides of the equation, verify that \(\mathbf{A}(\mathbf{BC}) = (\mathbf{AB})\mathbf{C}\). [4]
(b) State the property of matrix multiplication illustrated by this result. [1]
9 A transformation T of the plane is represented by the matrix \(\mathbf{M} = \begin{pmatrix} k + 1 & -1 \\ 1 & k \end{pmatrix}\), where \(k\) is a constant.
Show that, for all values of \(k\), T has no invariant lines through the origin. [6]
Mark scheme
Scheme
Marks
AO
\(\begin{pmatrix} k + 1 & -1 \\ 1 & k \end{pmatrix}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} kx + x - y \\ x + ky \end{pmatrix}\)
M1
1.1
\(y = mx \Rightarrow x + ky = m(kx + x - y)\)
M1
3.1a
\(\Rightarrow x + kmx = m(kx + x - mx)\) \(\Rightarrow 1 + km = km + m - m^2\)
A1
2.1
\(\Rightarrow m^2 - m + 1 = 0\)
A1
1.1
discriminant \(= (-1)^2 - 4 = -3 \lt 0\)
M1
3.1a
so no real roots, and no invariant lines
A1
3.2a
[6]
Notes
If a specific value for \(k\) used, allow max of 3 M marks (SC)
M1 A1: (2nd M1, 1st A1) or \(x + ky = m(kx + x - y) + c\) \(\Rightarrow x + k(mx + c) = m(kx + x - mx - c) + c\) \(\Rightarrow 1 + km = km + m - m^2\) and \(kc = c - mc\)
A1: (2nd) soi
M1: (3rd) oe or by solving to get \(m = \dfrac{1}{2} \pm \dfrac{\sqrt{3}}{2}\mathrm{i}\)
A1: (3rd) without wrong working If invariant point (instead of line) only first M1 is available
6 The matrices \(\mathbf{M}\) and \(\mathbf{N}\) are \(\begin{pmatrix} 0 & 1 \\ 1 & 0 \end{pmatrix}\) and \(\begin{pmatrix} 2 & 0 \\ 0 & 1 \end{pmatrix}\) respectively.
(a)In this question you must show detailed reasoning. Determine whether \(\mathbf{M}\) and \(\mathbf{N}\) commute under matrix multiplication. [3]
(b) Specify the transformation of the plane associated with each of the following matrices.
(i) \(\mathbf{M}\) [1]
(ii) \(\mathbf{N}\) [2]
(c) State the significance of the result in part (a) for the transformations associated with \(\mathbf{M}\) and \(\mathbf{N}\). [1]
(d) Use an algebraic method to show that all lines parallel to the \(x\)-axis are invariant lines of the transformation associated with \(\mathbf{N}\). [2]
8 A transformation T of the plane has matrix \(\mathbf{M}\), where \(\mathbf{M} = \begin{pmatrix} \cos\theta & 2\cos\theta - \sin\theta \\ \sin\theta & 2\sin\theta + \cos\theta \end{pmatrix}\).
(a) Show that T leaves areas unchanged for all values of \(\theta\). [2]
(b) Find the value of \(\theta\), where \(0 \lt \theta \lt \tfrac{1}{2}\pi\), for which the \(y\)-axis is an invariant line of T. [4]
The matrix \(\mathbf{N}\) is \(\begin{pmatrix} 1 & 2 \\ 0 & 1 \end{pmatrix}\).
(c)
(i) Find \(\mathbf{M}\mathbf{N}^{-1}\). [2]
(ii) Hence describe fully a sequence of two transformations of the plane that is equivalent to T. [4]
(a) A transformation with associated matrix \(\begin{pmatrix} m & 2 & 1 \\ 0 & 1 & -2 \\ 2 & 0 & 3 \end{pmatrix}\), where \(m\) is a constant, maps the vertices of a cube to points that all lie in a plane. Find \(m\). [3]
(b) The transformations S and T of the plane have associated matrices \(\mathbf{M}\) and \(\mathbf{N}\) respectively, where \(\mathbf{M} = \begin{pmatrix} k & 1 \\ -3 & 4 \end{pmatrix}\) and the determinant of \(\mathbf{N}\) is \(3k + 1\). The transformation U is equivalent to the combined transformation consisting of S followed by T. Given that U preserves orientation and has an area scale factor 2, find the possible values of \(k\). [4]
(i) Write the following simultaneous equations as a matrix equation.\[\begin{aligned} x + y + 2z &= 7 \\ 2x - 4y - 3z &= -5 \\ -5x + 3y + 5z &= 13 \end{aligned}\] [1]
(ii) Hence solve the equations. [2]
(b) Determine the set of values of the constant \(k\) for which the matrix equation\[\begin{pmatrix} k + 1 & 1 \\ 2 & k \end{pmatrix}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} 23 \\ -17 \end{pmatrix}\]has a unique solution. [3]
6 Given that \(y = mx\) is an invariant line of the transformation with matrix \(\begin{pmatrix} 1 & 2 \\ 2 & -2 \end{pmatrix}\), determine the possible values of \(m\). [4]
Mark scheme
Scheme
Marks
AO
\(\begin{pmatrix} 1 & 2 \\ 2 & -2 \end{pmatrix}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} x + 2y \\ 2x - 2y \end{pmatrix}\)
6 A transformation T of the plane has associated matrix \(\mathbf{M} = \begin{pmatrix} 1 & \lambda + 1 \\ \lambda - 1 & -1 \end{pmatrix}\), where \(\lambda\) is a non-zero constant.
(a)
(i) Show that T reverses orientation. [3]
(ii) State, in terms of \(\lambda\), the area scale factor of T. [1]
(b)
(i) Show that \(\mathbf{M}^2 - \lambda^2\mathbf{I} = \mathbf{0}\). [2]
(ii) Hence specify the transformation equivalent to two applications of T. [1]
(c) In the case where \(\lambda = 1\), T is equivalent to a transformation S followed by a reflection in the \(x\)-axis.
4 Anika thinks that, for two square matrices \(\mathbf{A}\) and \(\mathbf{B}\), the inverse of \(\mathbf{AB}\) is \(\mathbf{A}^{-1}\mathbf{B}^{-1}\). Her attempted proof of this is as follows.
(a) Show that the three planes with equations\[\begin{aligned} x + \lambda y + 3z &= -12 \\ 2x + y + 5z &= -11 \\ x - 2y + 2z &= -9 \end{aligned}\]where \(\lambda\) is a constant, meet at a unique point except for one value of \(\lambda\) which is to be determined. [3]
(b) In the case \(\lambda = -2\), use matrices to find the point of intersection P of the planes, showing your method clearly. [3]
The line \(l\) has equation \(\dfrac{x - 1}{2} = \dfrac{y - 1}{-1} = \dfrac{z + 2}{-2}\).
(c) Find a vector equation of \(l\). [2]
(d) Find the shortest distance between the point P and \(l\). [4]
(e)
(i) Show that \(l\) is parallel to the plane \(x - 2y + 2z = -9\). [3]
(ii) Find the distance between \(l\) and the plane \(x - 2y + 2z = -9\). [2]
9 A linear transformation of the plane is represented by the matrix \(\mathbf{M} = \begin{pmatrix} 1 & -2 \\ \lambda & 3 \end{pmatrix}\), where \(\lambda\) is a constant.
(a) Find the set of values of \(\lambda\) for which the linear transformation has no invariant lines through the origin. [5]
(b) Given that the transformation multiplies areas by 5 and reverses orientation, find the invariant lines. [3]
Mark scheme (a)
Scheme
Marks
AO
\(\begin{pmatrix} 1 & -2 \\ \lambda & 3 \end{pmatrix}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} x - 2y \\ \lambda x + 3y \end{pmatrix}\)
B1
2.1
suppose \(y = mx\) is invariant \(\lambda x + 3y = m(x - 2y)\)
Investigate the arrangement of the planes for each of the following cases. If in either case the planes meet at a unique point, find the coordinates of that point.
(a) \(k = -1\) [3]
(b) \(k = \tfrac{2}{3}\) [4]
Mark scheme (a)
Scheme
Marks
AO
when \(k = -1\), \(\det\mathbf{M} \ne 0\) [so meet at a point]
M1
1.1
\(\begin{pmatrix} x \\ y \\ z \end{pmatrix} = \mathbf{M}^{-1}\begin{pmatrix} 0 \\ -5 \\ 1 \end{pmatrix}\)
M1
1.1
by calculator, point of intersection is \((-1, 3, 2)\)
A1
1.1
[3]
Notes
M1: (1st) calculating determinant or finding \(\mathbf{M}^{-1}\)
M1: (2nd) solving (soi) or by sim equations
A1: BC, allow \(\begin{pmatrix} -1 \\ 3 \\ 2 \end{pmatrix}\) If correct ans found by solving simultaneously SCB3
(a) The matrix \(\mathbf{M}\) is \(\begin{pmatrix} 0 & -1 \\ -1 & 0 \end{pmatrix}\).
(i) Find \(\mathbf{M}^2\). [1]
(ii) Write down the transformation represented by \(\mathbf{M}\). [1]
(iii) Hence state the geometrical significance of the result of part (i). [1]
(b) The matrix \(\mathbf{N}\) is \(\begin{pmatrix} k + 1 & 0 \\ k & k + 2 \end{pmatrix}\), where \(k\) is a constant. Using determinants, investigate whether \(\mathbf{N}\) can represent a reflection. [4]
6 The matrices \(\mathbf{M}\) and \(\mathbf{N}\) are \(\begin{pmatrix} \lambda & 2 \\ 2 & \lambda \end{pmatrix}\) and \(\begin{pmatrix} \mu & 1 \\ 1 & \mu \end{pmatrix}\) respectively, where \(\lambda\) and \(\mu\) are constants.
(a) Investigate whether \(\mathbf{M}\) and \(\mathbf{N}\) are commutative under multiplication. [2]
(b) You are now given that \(\mathbf{MN} = \mathbf{I}\).
(i) Write down a relationship between \(\det\mathbf{M}\) and \(\det\mathbf{N}\). [1]
(ii) Given that \(\lambda \gt 0\), find the exact values of \(\lambda\) and \(\mu\). [3]
(a) The matrices \(\mathbf{M} = \begin{pmatrix} 0 & 1 & a \\ 1 & b & 0 \end{pmatrix}\) and \(\mathbf{N} = \begin{pmatrix} b & -5 \\ -1 & c \\ -1 & 1 \end{pmatrix}\) are such that \(\mathbf{MN} = \mathbf{I}\). Find \(a\), \(b\) and \(c\). [5]
(b) State with a reason whether or not \(\mathbf{N}\) is the inverse of \(\mathbf{M}\). [1]
Mark scheme (a)
Scheme
Marks
AO
\(\begin{pmatrix} 0 & 1 & a \\ 1 & b & 0 \end{pmatrix}\begin{pmatrix} b & -5 \\ -1 & c \\ -1 & 1 \end{pmatrix} = \begin{pmatrix} 1 & 0 \\ 0 & 1 \end{pmatrix}\)
B1
1.1a
\(-1 - a = 1 \Rightarrow a = -2\) \(c + a = 0 \Rightarrow c = 2\) \(-5 + bc = 1 \Rightarrow b = 3\)
(b) Find the equation of the mirror line of the reflection R represented by the matrix \(\mathbf{M}_3 = \mathbf{M}_1\mathbf{M}_2\). [5]
(c) It is claimed that the reflection represented by the matrix \(\mathbf{M}_4 = \mathbf{M}_2\mathbf{M}_1\) has the same mirror line as R. Explain whether or not this claim is correct. [3]
Mark scheme (a)
Scheme
Marks
AO
\(\mathbf{M}_1\) rotation
M1
3.1a
through \(\cos^{-1}(3/5)\) or \(53.1^\circ\) or 0.927 rads
A1
1.1b
anti-clockwise about O
A1
1.2
\(\mathbf{M}_2\) reflection in \(x\)-axis
B1
1.2
[4]
Notes
A1: oe e.g. \(\sin^{-1}(4/5)\), \(\tan^{-1}(4/3)\); \(53^\circ\) or 0.93 rads or better
\({\def\arraystretch{1.6}\begin{pmatrix} \frac{3}{5} & \frac{4}{5} \\ \frac{4}{5} & -\frac{3}{5} \end{pmatrix}}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} x \\ y \end{pmatrix}\)
6 A linear transformation T of the \(x\)-\(y\) plane has an associated matrix \(\mathbf{M}\), where \(\mathbf{M} = \begin{pmatrix} \lambda & k \\ 1 & \lambda - k \end{pmatrix}\), and \(\lambda\) and \(k\) are real constants.
(a) You are given that \(\det\mathbf{M} \gt 0\) for all values of \(\lambda\).
(i) Find the range of possible values of \(k\). [3]
(ii) What is the significance of the condition \(\det\mathbf{M} \gt 0\) for the transformation T? [1]
For the remainder of this question, take \(k = -2\).
(b) Determine whether there are any lines through the origin that are invariant lines for the transformation T. [4]
(c) The transformation T is applied to a triangle with area 3 units2. The area of the resulting image triangle is 15 units2. Find the possible values of \(\lambda\). [3]
Mark scheme (a)
Scheme
Marks
AO
(i) \(\det\mathbf{M} = \lambda(\lambda - k) - k\)
B1
1.1
\(\det\mathbf{M} \gt 0 \Rightarrow \lambda^2 - k\lambda - k \gt 0\) for all \(\lambda \Rightarrow k^2 + 4k \lt 0\)
M1
3.1a
\(\Rightarrow -4 \lt k \lt 0\)
A1cao
1.1
[3]
(ii) The transformation represented by \(\mathbf{M}\) always preserves the orientation of shapes
B1
1.2
[1]
Notes
(a)(i)
M1: attempt to find discriminant or \((\lambda - k/2)^2 \gt k^2/4 + k\)
(a)(ii)
B1: condone ‘doesn’t reflect’
Mark scheme (b)
Scheme
Marks
AO
\(\begin{pmatrix} \lambda & -2 \\ 1 & \lambda + 2 \end{pmatrix}\begin{pmatrix} x \\ y \end{pmatrix} = \begin{pmatrix} \lambda x - 2y \\ x + (\lambda + 2)y \end{pmatrix}\)
B1
2.1
invariant line if \(x + \lambda mx + 2mx = m(\lambda x - 2mx)\)
M1
2.1
\(\Rightarrow 2m^2 + 2m + 1 = 0\)
A1
1.1
discriminant is \(2^2 - 2 \times 4 = -4 \lt 0\) so no real roots for \(m\), i.e. there are no invariant lines
A1
2.3
[4]
Notes
B1: oe (e.g. with \(y = mx\) [\(+ c\)])
M1: subst \(y = mx[+c]\) into \(x + (\lambda + 2)y = m(\lambda x - 2y)[+c]\) \(x + (\lambda + 2)(mx + c) = m(\lambda x - 2mx - 2c) + c\)
(b) Hence find, in terms of the constant \(k\), the point of intersection of the planes\[\begin{aligned} x + 2y + 3z &= 19, \\ -x + y + 2z &= 4, \\ -2x + y + 2z &= k. \end{aligned}\][3]
(c)In this question you must show detailed reasoning. Find the acute angle between the planes \(x + 2y + 3z = 19\) and \(-x + y + 2z = 4\). [4]
3 Matrices \(\mathbf{A}\) and \(\mathbf{B}\) are defined by \(\mathbf{A} = \begin{pmatrix} 3 & 1 \\ 2 & 1 \end{pmatrix}\) and \(\mathbf{B} = \begin{pmatrix} k & 1 \\ 2 & 0 \end{pmatrix}\), where \(k\) is a constant.
(a) Verify the result \((\mathbf{AB})^{-1} = \mathbf{B}^{-1}\mathbf{A}^{-1}\) in this case. [5]
(b) Investigate whether \(\mathbf{A}\) and \(\mathbf{B}\) are commutative under matrix multiplication. [2]
\[\begin{aligned} -x + 2y + z &= 0 \\ 2x - y - z &= 0 \\ x + y \phantom{{}- z} &= a \end{aligned}\]
where \(a\) is a constant.
(i) Investigate the arrangement of the planes:
when \(a = 0\);
when \(a \neq 0\). [6]
(ii) Chris claims that the position vectors \(-\mathbf{i} + 2\mathbf{j} + \mathbf{k}\), \(2\mathbf{i} - \mathbf{j} - \mathbf{k}\) and \(\mathbf{i} + \mathbf{j}\) lie in a plane. Determine whether or not Chris is correct. [2]
Mark scheme (i)
Scheme
Marks
AO
\(\det\mathbf{M} = 0\) [so no unique solution]
B1
3.1a
no planes parallel [so prism or sheaf]
B1
1.1
when \(a = 0\), they form a sheaf
B1
2.2a
as the system has solutions
B1
2.2a
when \(a \neq 0\), they form a prismatic intersection
B1
2.2a
as there are no solutions
B1
3.1a
[6]
Notes
B1: (1st) or \(\mathbf{M}\) is singular or state no unique solution by direct solution of equations
B1: (3rd) allow ‘intersect in a line’
B1: (4th) o.e. e.g. finding solutions
B1: (5th) allow ‘prism’
Mark scheme (ii)
Scheme
Marks
AO
These are the normals to the three planes
M1
1.1a
In either of the above cases, they must lie in the same plane
6 Find the invariant line of the transformation of the \(x\)-\(y\) plane represented by the matrix \(\begin{pmatrix} 2 & 0 \\ 4 & -1 \end{pmatrix}\). [4]
5 A transformation of the \(x\)-\(y\) plane is represented by the matrix \(\begin{pmatrix} \cos\theta & 2\sin\theta \\ 2\sin\theta & -\cos\theta \end{pmatrix}\), where \(\theta\) is a positive acute angle.
(i) Write down the image of the point \((2, 3)\) under this transformation. [2]
(ii) You are given that this image is the point \((a, 0)\). Find the value of \(a\). [5]